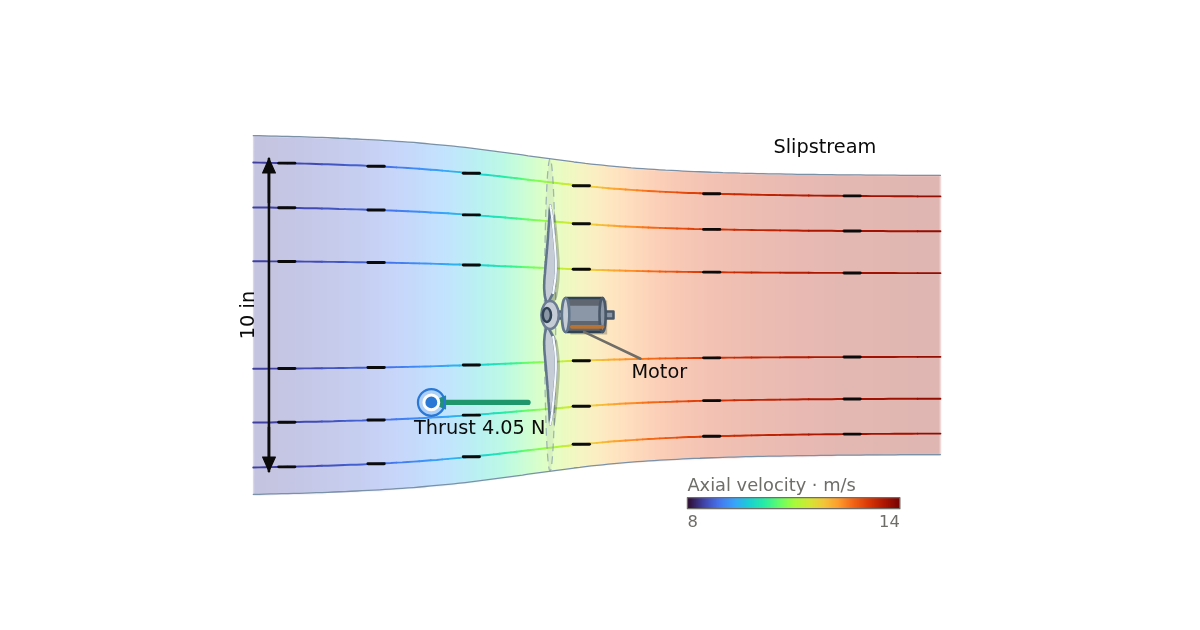
Match motor KV, propeller and battery by solving torque balance. Compare static and flight thrust, current, efficiency, winding temperature, hover throttle and capacity-based endurance.
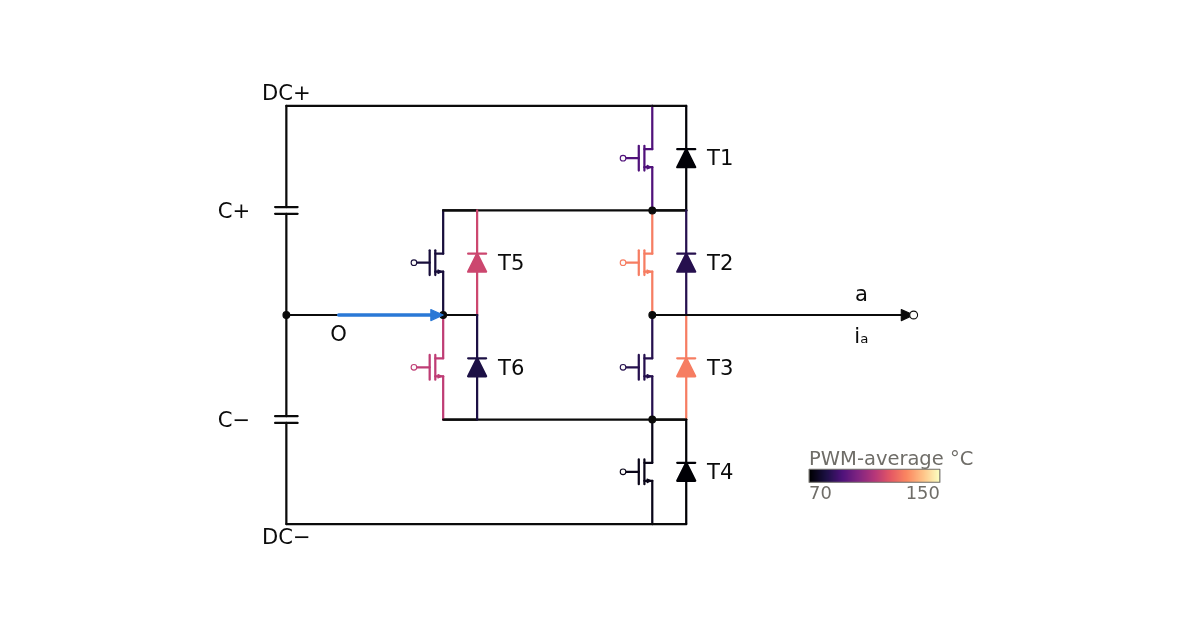
Compare ANPC zero-state commutations, balance six-switch leg losses, and track transistor and diode junction temperatures through a low-frequency heavy launch.
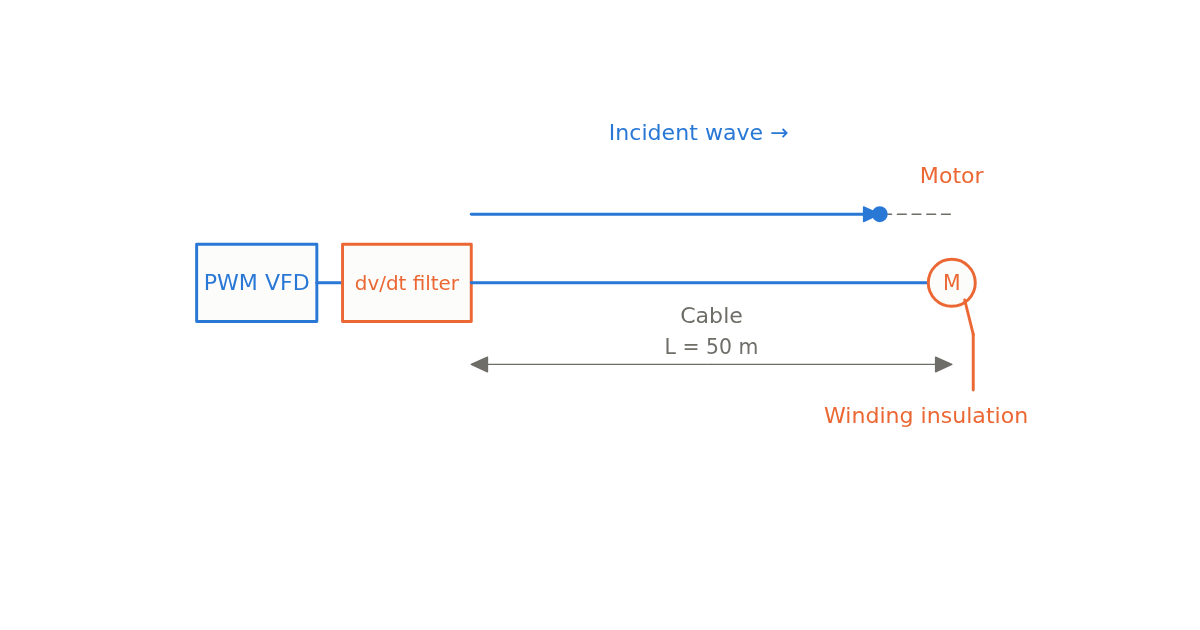
Compare VFD cable reflections and dv/dt filters with motor RPDIV and IEC insulation stress categories. Explore peak voltage, rise-time reserve and electrical life sensitivity.
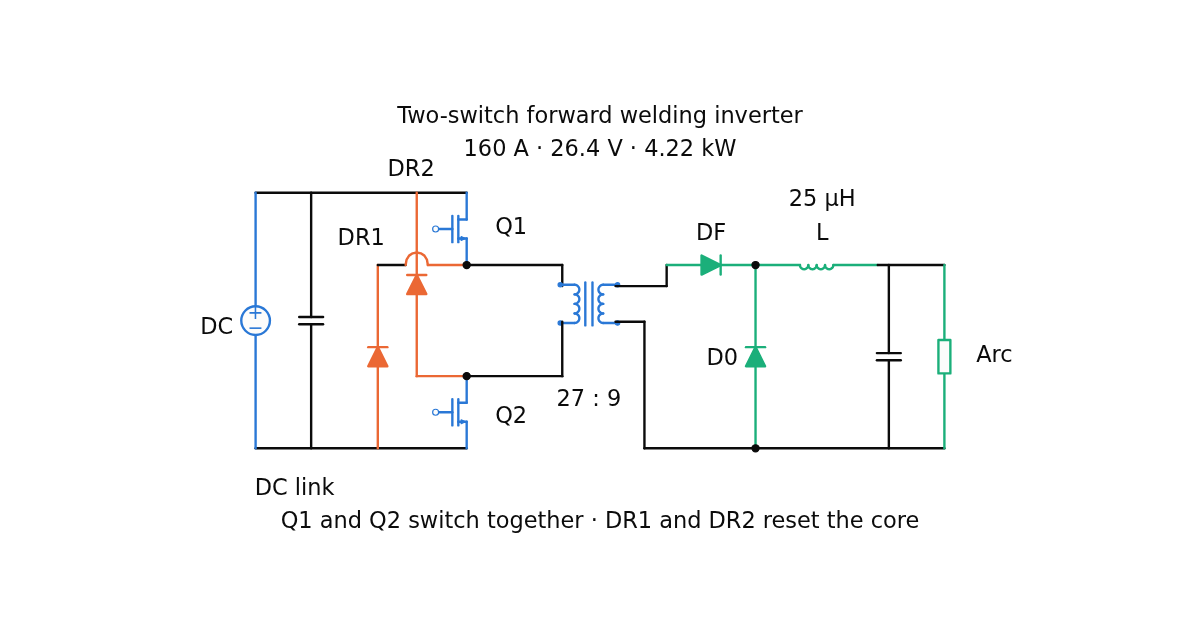
Size a two-switch forward welding inverter: transformer turns and copper, output choke, switch currents and losses, mains demand, and the arc load characteristic.
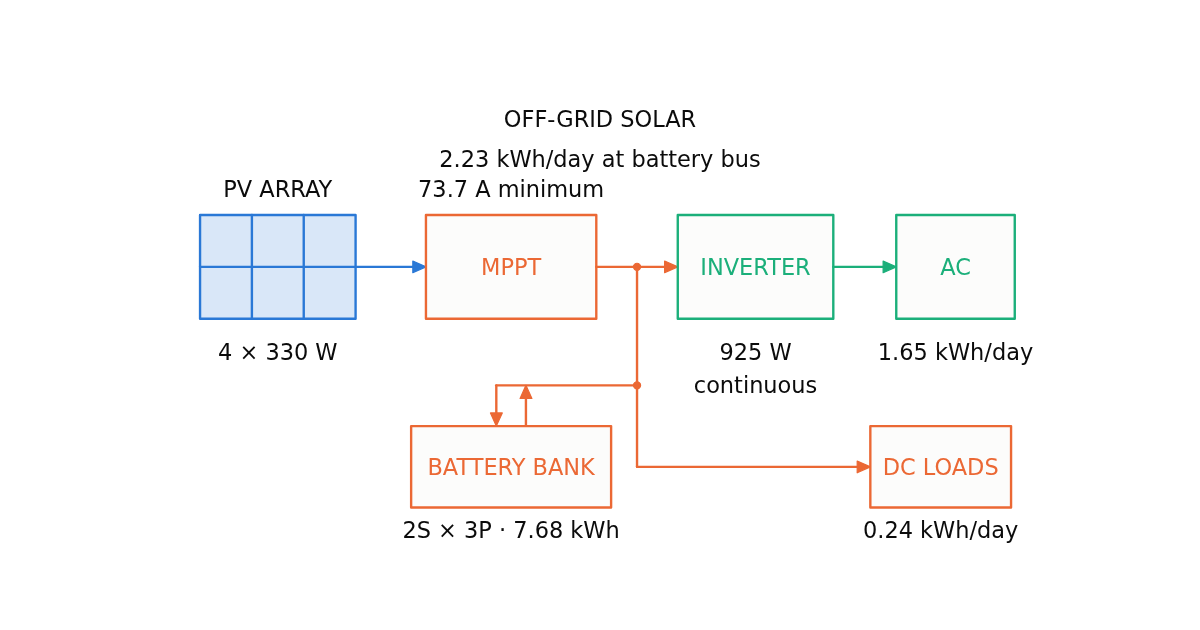
Size an off-grid solar array, battery bank, MPPT or PWM controller and inverter from daily loads, sunless days and worst-month peak sun hours.
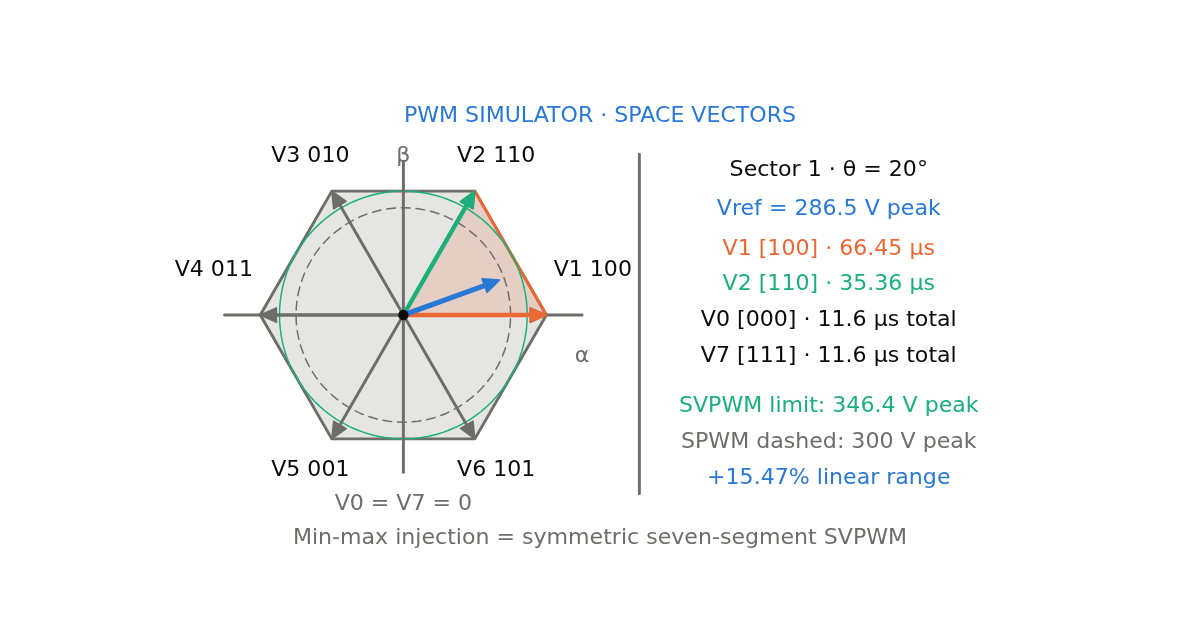
Compare SPWM, SVPWM, THIPWM and DPWM0–3. Animate the space-vector hexagon, inspect seven-segment switching and dwell times, and compare current ripple and relative switching loss.