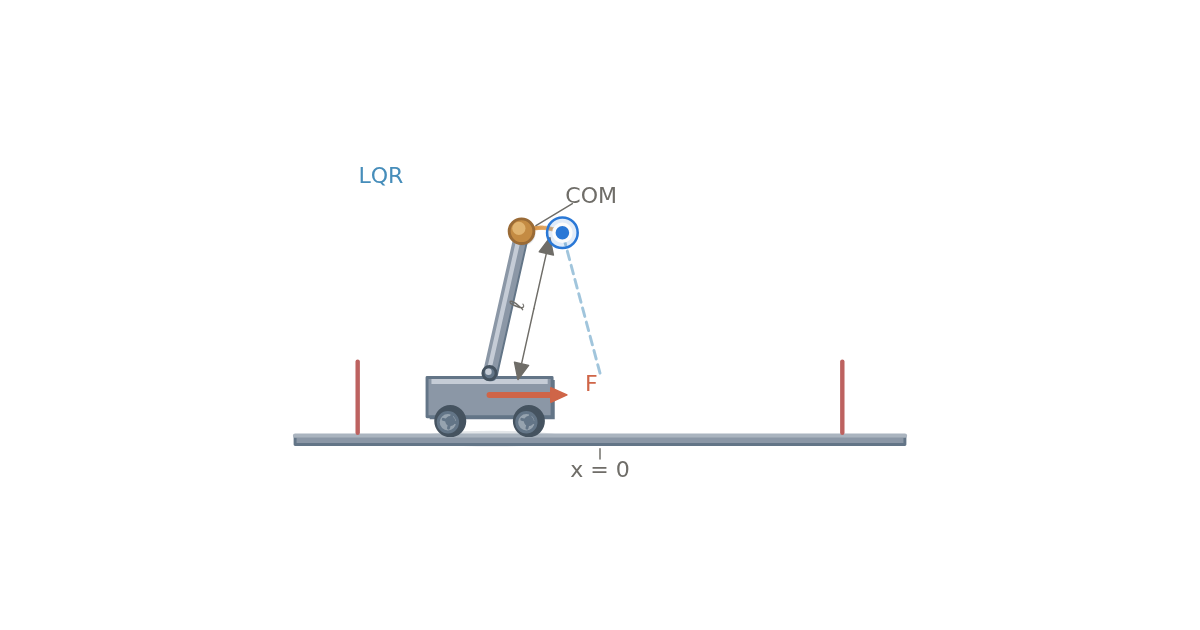
Inverted Pendulum Simulation: PID vs LQR
 Wired White v2
Compare PID and LQR on a nonlinear cart–pole with actuator saturation. Play the motion, apply timed pushes, and inspect settling, cart travel and closed-loop poles.
Control and drives: PID tuning with a simulated step response, field-oriented control of PMSM and induction motors, and the Clarke-Park transformation from abc to dq0. Watch the loops and the reference frames move as you change the inputs; each calc shows its method.
Wired White v2 Compare PID and LQR on a nonlinear cart–pole with actuator saturation. Play the motion, apply timed pushes, and inspect settling, cart travel and closed-loop poles.
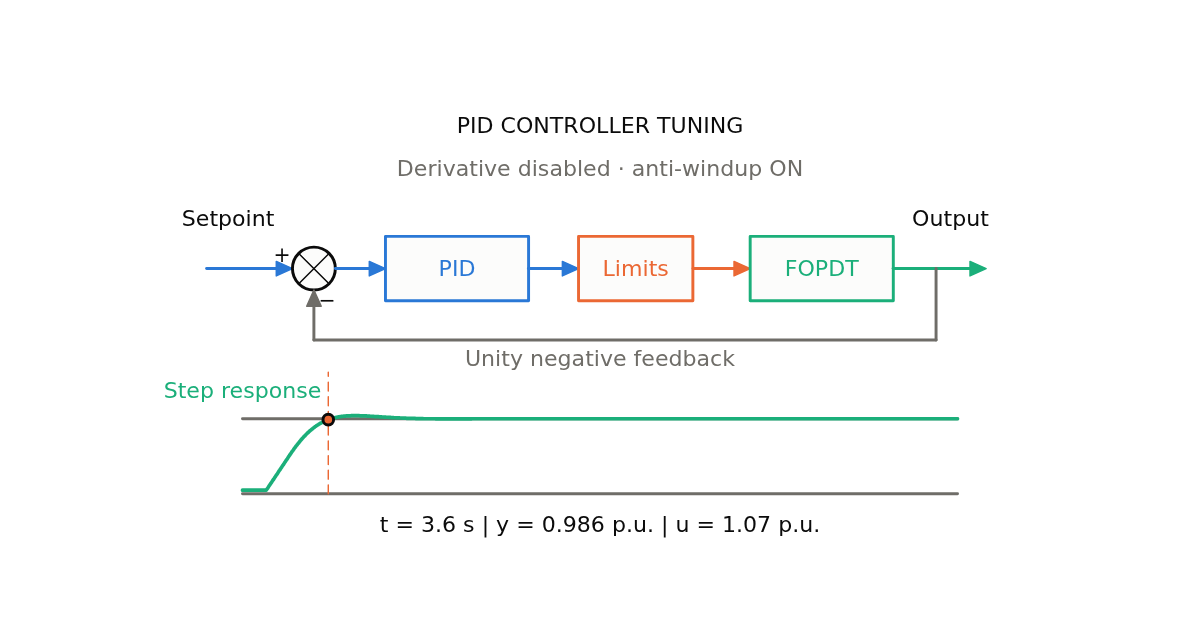
Wired White v2 Tune a filtered PID controller on process and DC motor models. Compare step response, actuator saturation, Bode margins and a root locus with SIMC or Ziegler–Nichols settings.
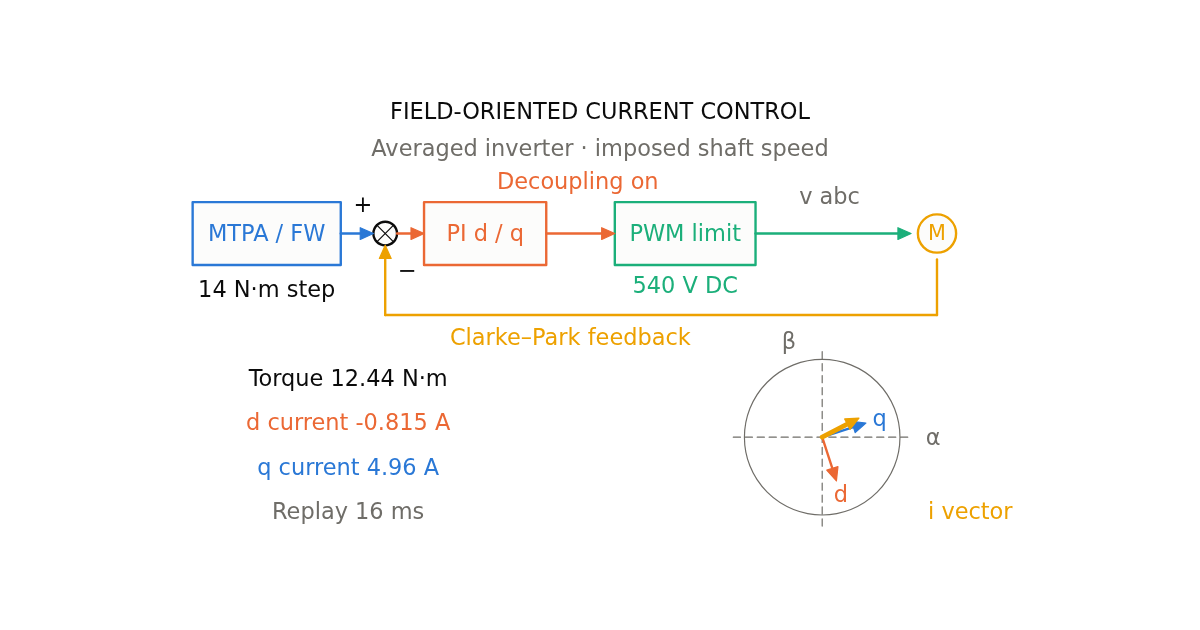
Wired White v2 Simulate field-oriented motor control with tuned PI current loops, decoupling, MTPA and field weakening. Explore dq transients, torque, inverter limits and rotating current vectors.
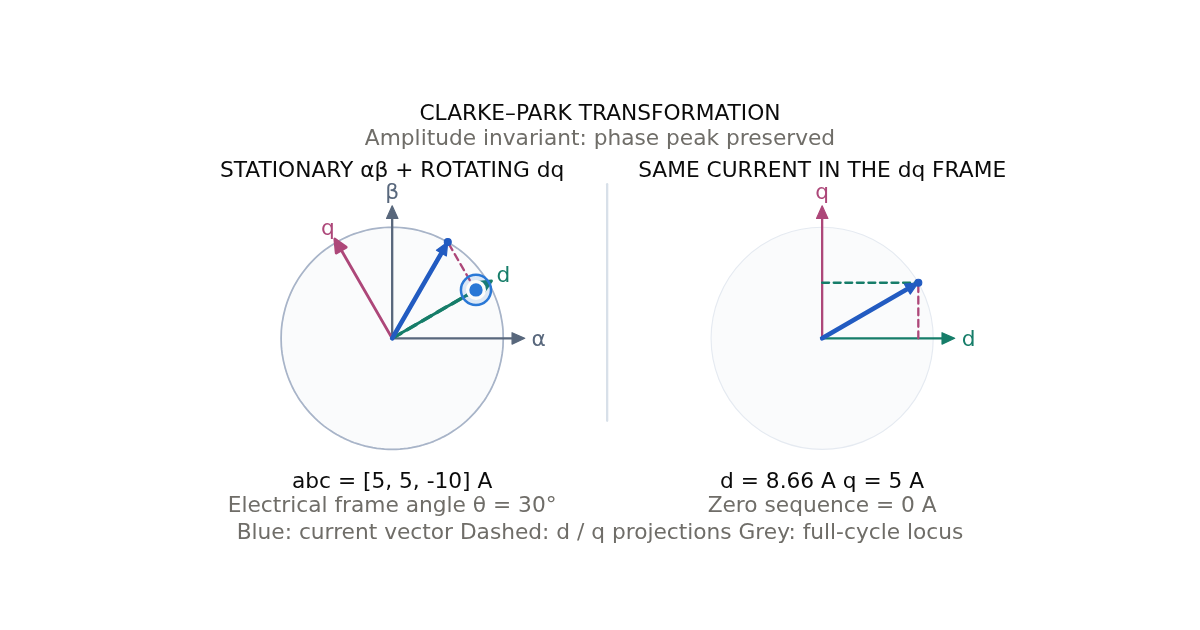
Wired White v3 Convert abc currents to αβ0 and dq0 with animated phasors, rotating frames, amplitude- or power-invariant scaling, and inverse reconstruction.
Press ▶, then Space (or tap the drawing) to flap. MeowL dodges spreadsheet errors; every frame is calculated by the same engine as a beam.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.