Claw-Pole Alternator on 3D FEM Flux Maps: Rectifier and Regulator
 Wired White v8
Simulate a 16-pole, delta-wound claw-pole alternator from 3D FEM flux maps. Explore rectifier ripple, field regulation, torque, copper losses and energy balance.
Electric motor design and use: PMSM, IPMSM, SPM, SynRM, BLDC, axial-flux, induction and DC machines, winding layouts, winding factors and MMF, efficiency maps, stepper torque-speed curves, motor starting methods and run capacitors for motors on single phase. Each calc shows its method and published sources.
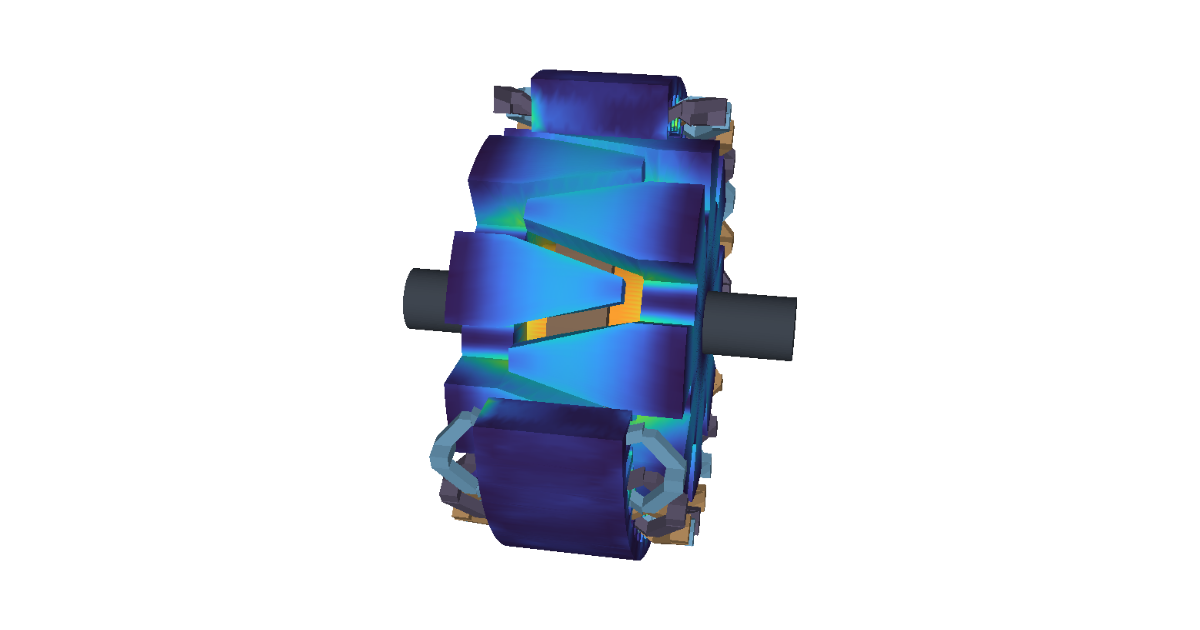
Wired White v8 Simulate a 16-pole, delta-wound claw-pole alternator from 3D FEM flux maps. Explore rectifier ripple, field regulation, torque, copper losses and energy balance.
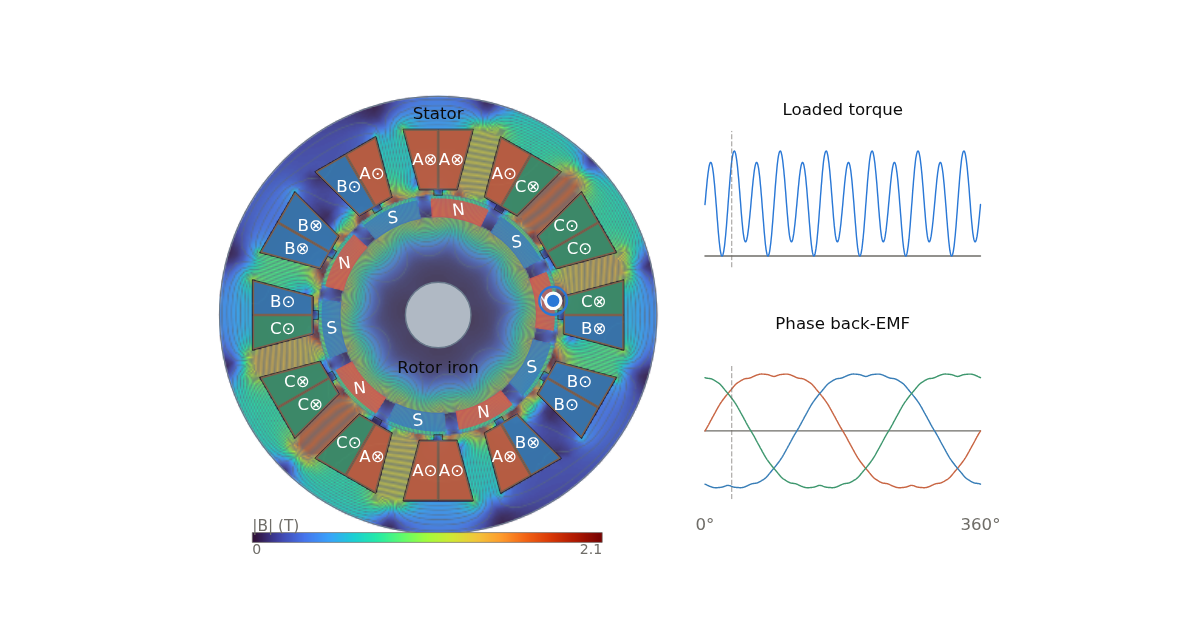
Wired White v4 Solve a nonlinear 12-slot, 10-pole motor cross-section by finite elements. Explore flux lines, phase back-EMF, cogging and loaded torque as the rotor turns.
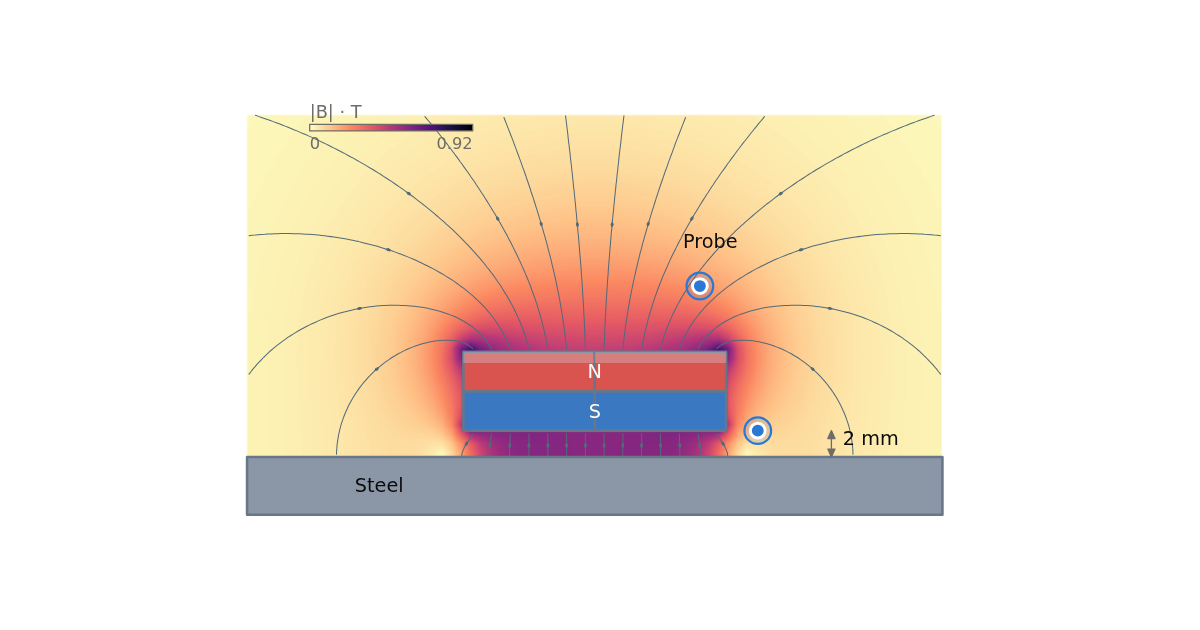
Wired White v2 Calculate fields and pull forces for disc, block and ring magnets. Compare steel pull, attraction or repulsion, air gaps, grades and temperature.
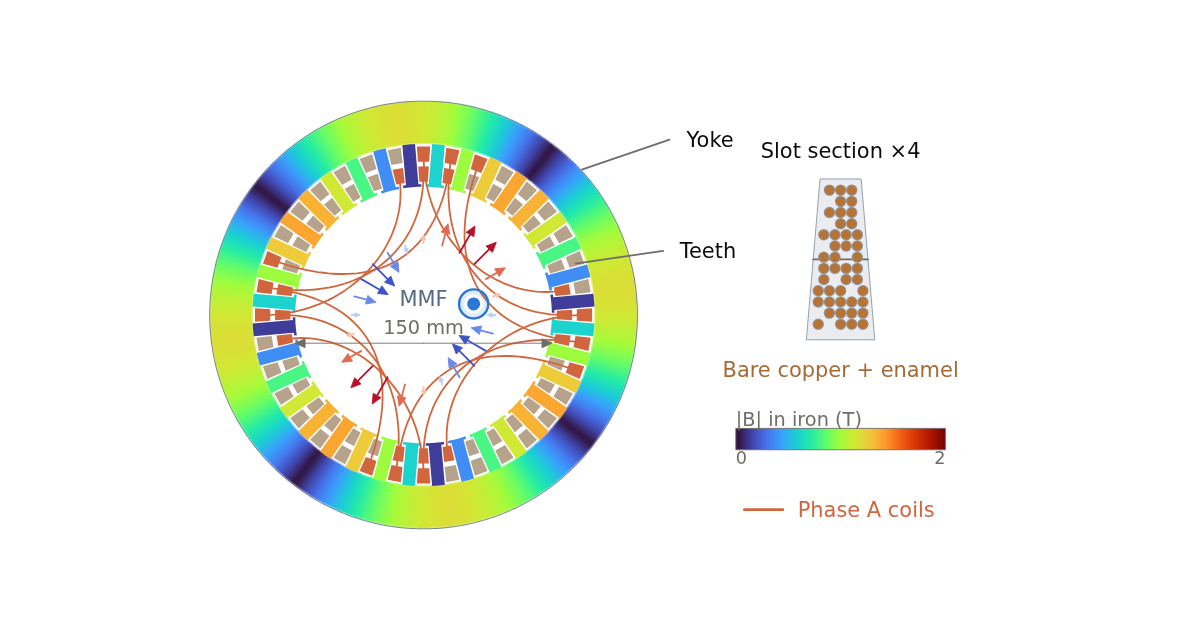
Wired White v2 Size a three-phase stator rewind from its dimensions or preserve an old winding’s flux at a new voltage or frequency. Check turns, wire size, slot fill, tooth and yoke densities.
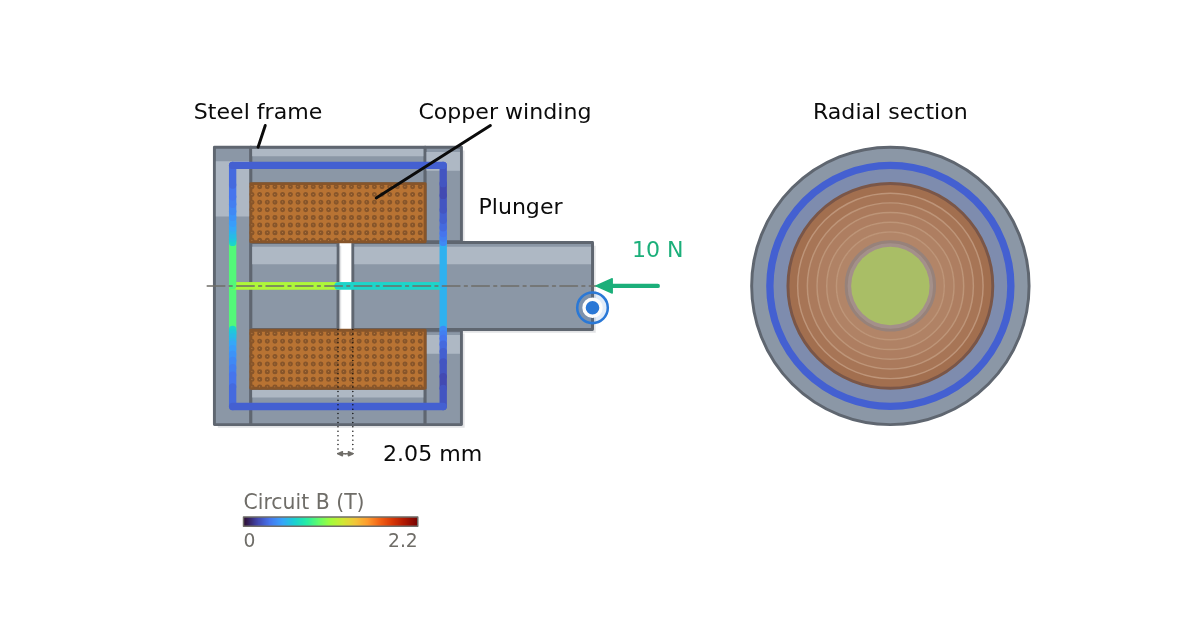
Wired White v2 Design a plunger solenoid, C-core or pot electromagnet. Compare force versus air gap with nonlinear steel, fringing, coil winding and cyclic heating.
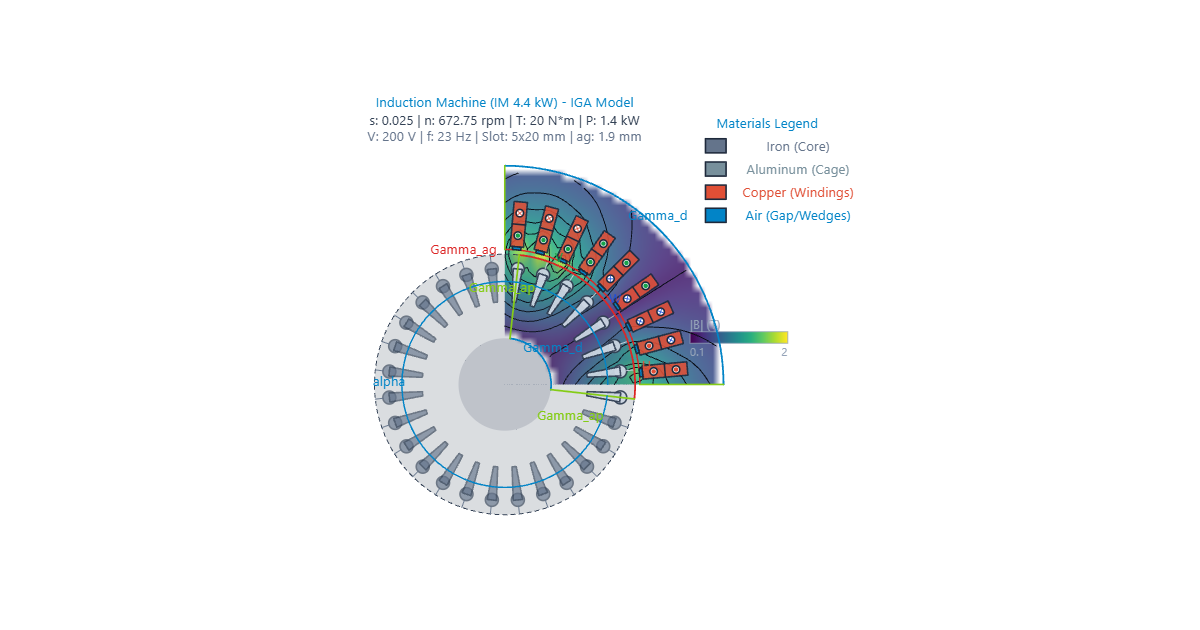
Isogeometric Analysis (IGA) simulation of electric machines: PMSM combined shape/parameter optimization & 4.4 kW Induction Machine (IM) characterization and startup (CREATOR / Weiss & Wiesheu 2024).
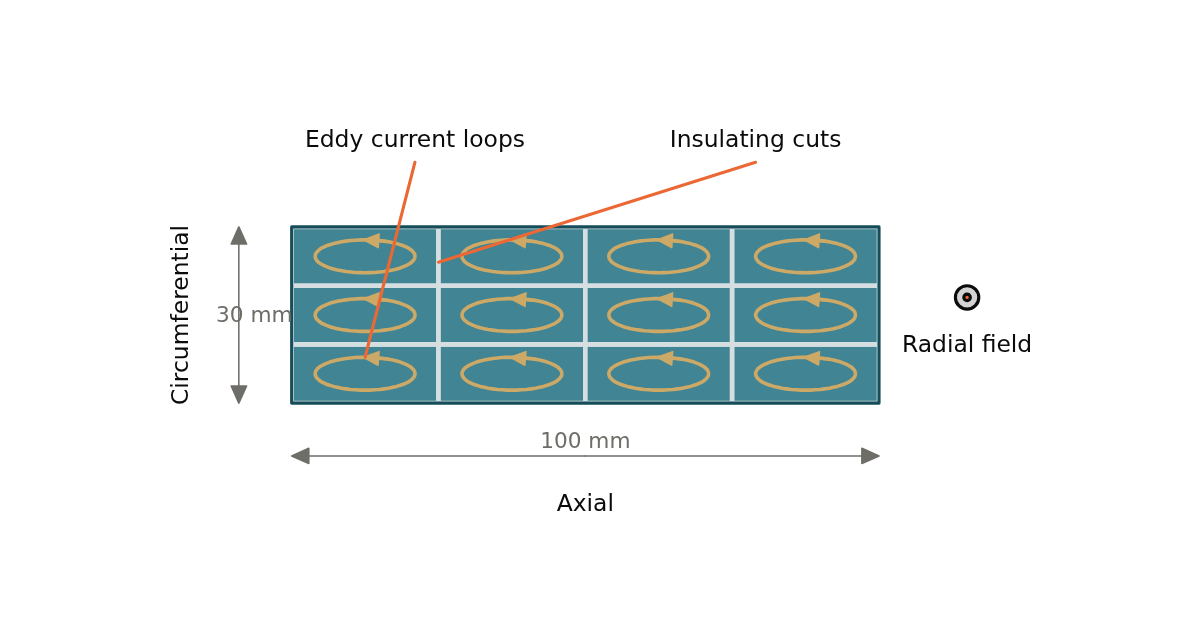
Wired White v2 Solve 2D magnetic diffusion for slot and PWM harmonics. Compare circumferential and axial magnet segmentation, find the fewest pieces meeting a loss target, and estimate magnet temperature.
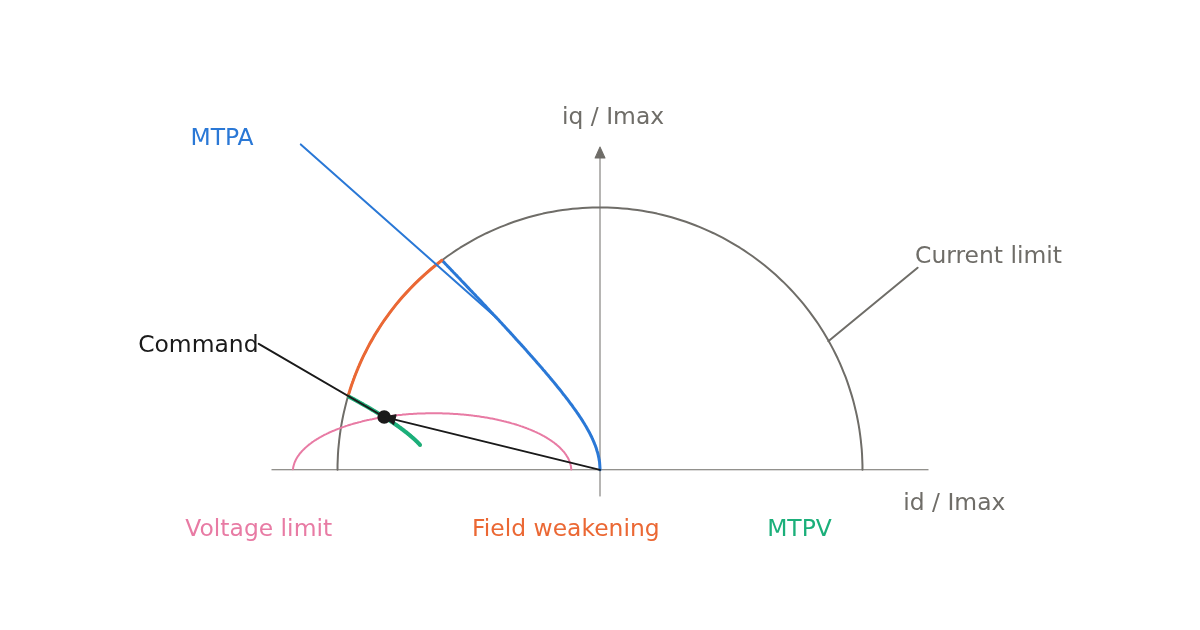
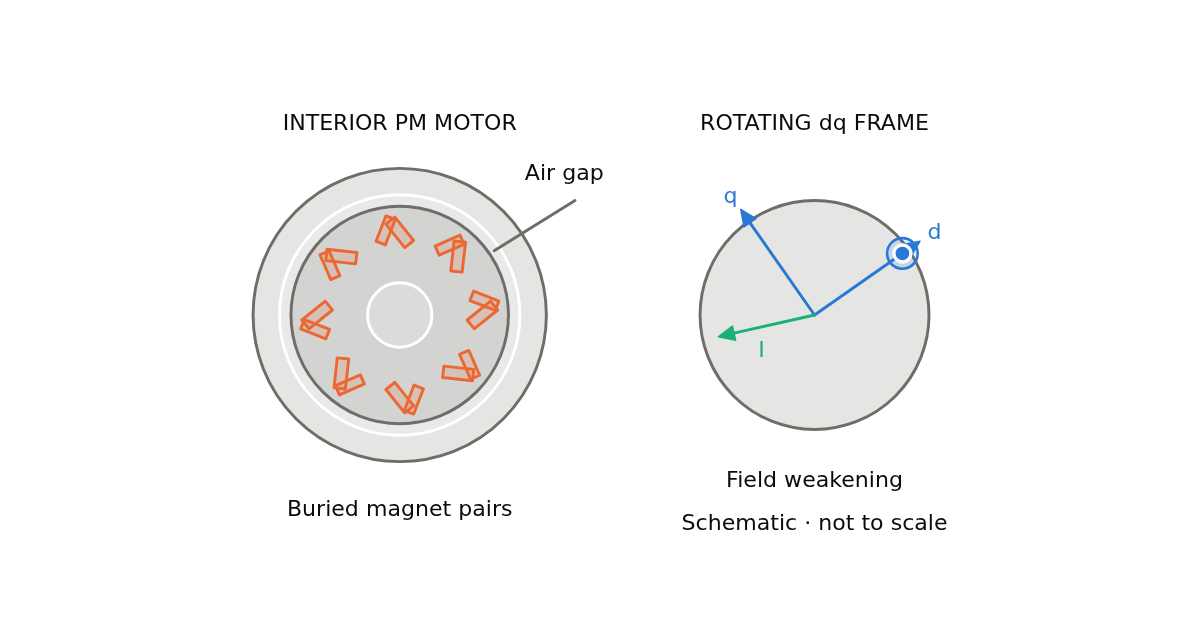
Wired White v2 Find id and iq references from Ld, Lq, magnet flux and inverter limits. Explore MTPA, field weakening, MTPV and the torque–speed and power–speed envelopes.
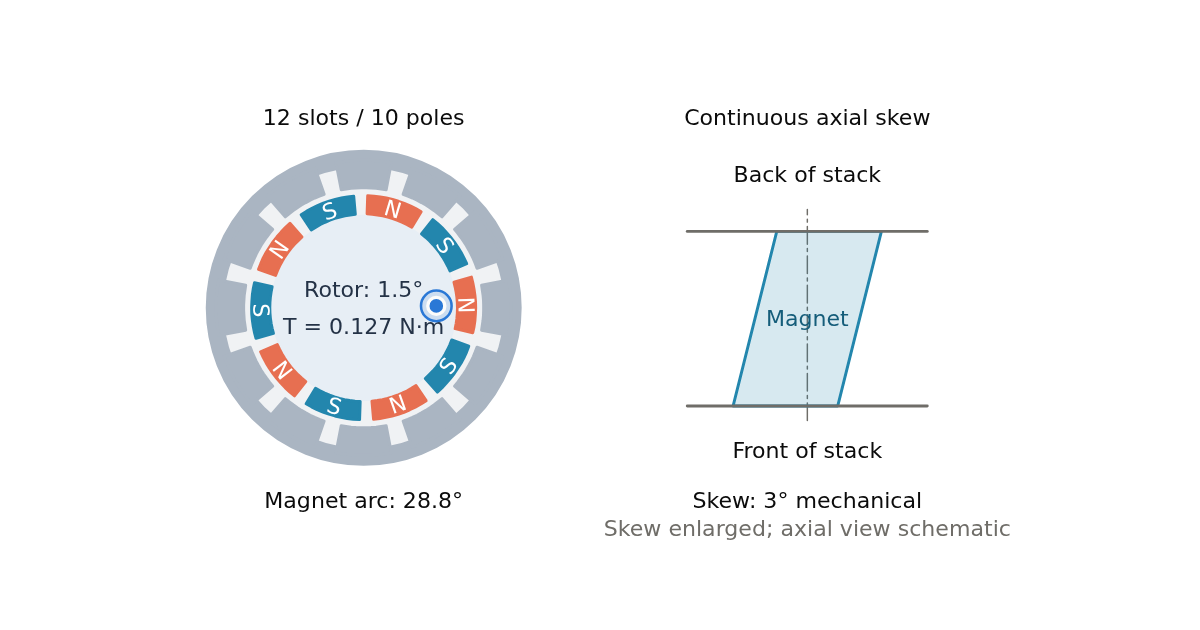
Wired White v3 Compare slot–pole combinations, ideal magnet-width cancellation points and continuous skew. Calculate harmonic attenuation and scale a measured or FEM torque amplitude.
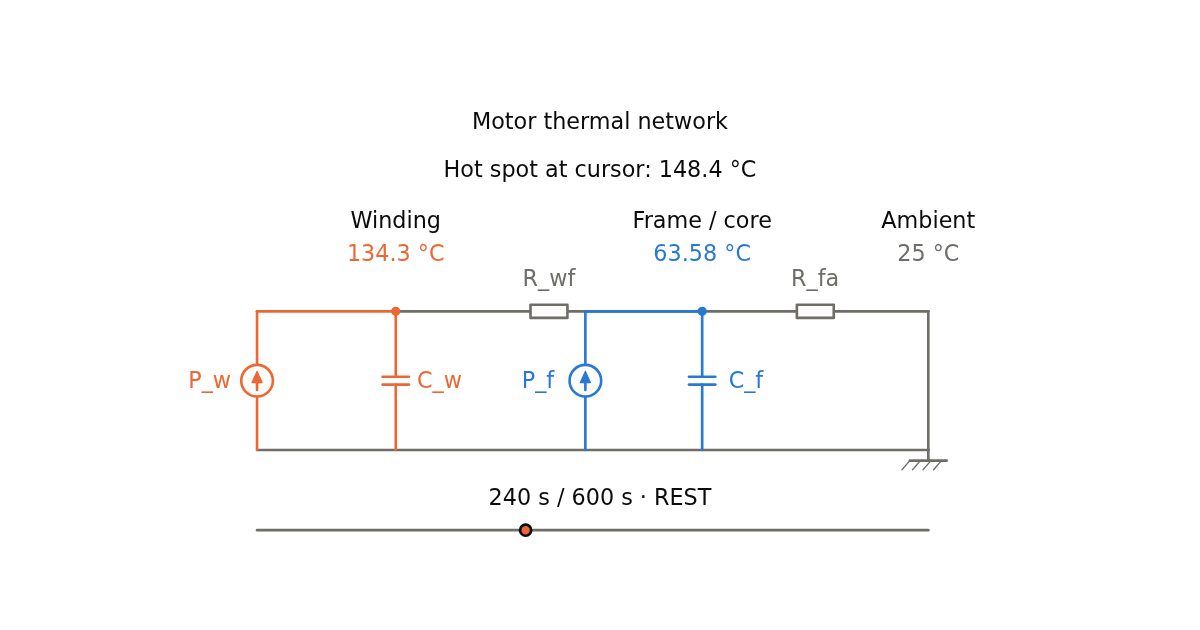
Wired White v2 Calculate motor winding, frame and hot-spot temperatures from losses and duty cycle. Compare warm-up with the settled repeating cycle using a two-node thermal network.
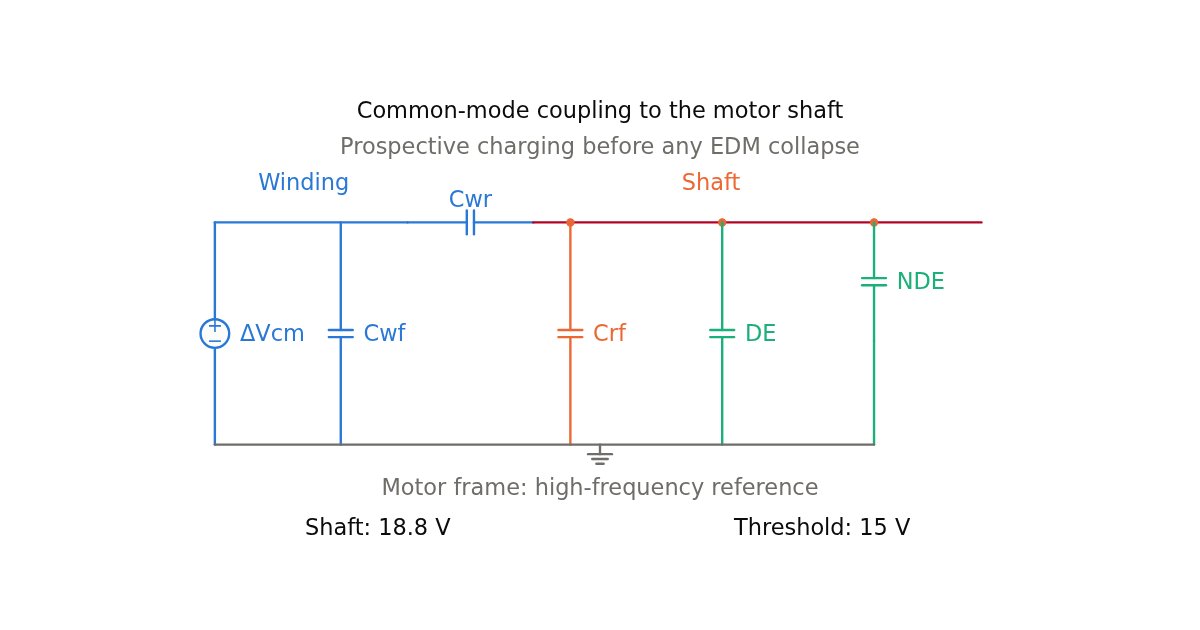
Wired White v3 Estimate shaft voltage, bearing voltage ratio and bearing currents in inverter-fed motors. Compare insulation, grounding brushes and common-mode filtering.
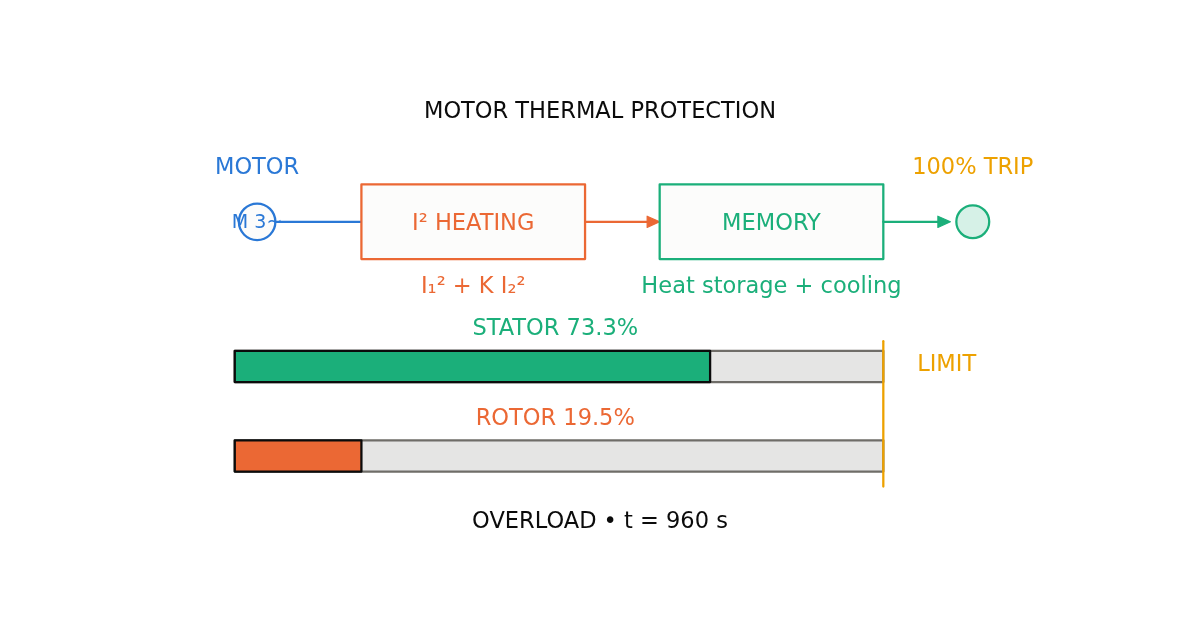
Wired White v3 Model motor thermal capacity over starts, overloads and cooling. Compare hot/cold stall limits and estimate negative-sequence heating and voltage-unbalance derating.
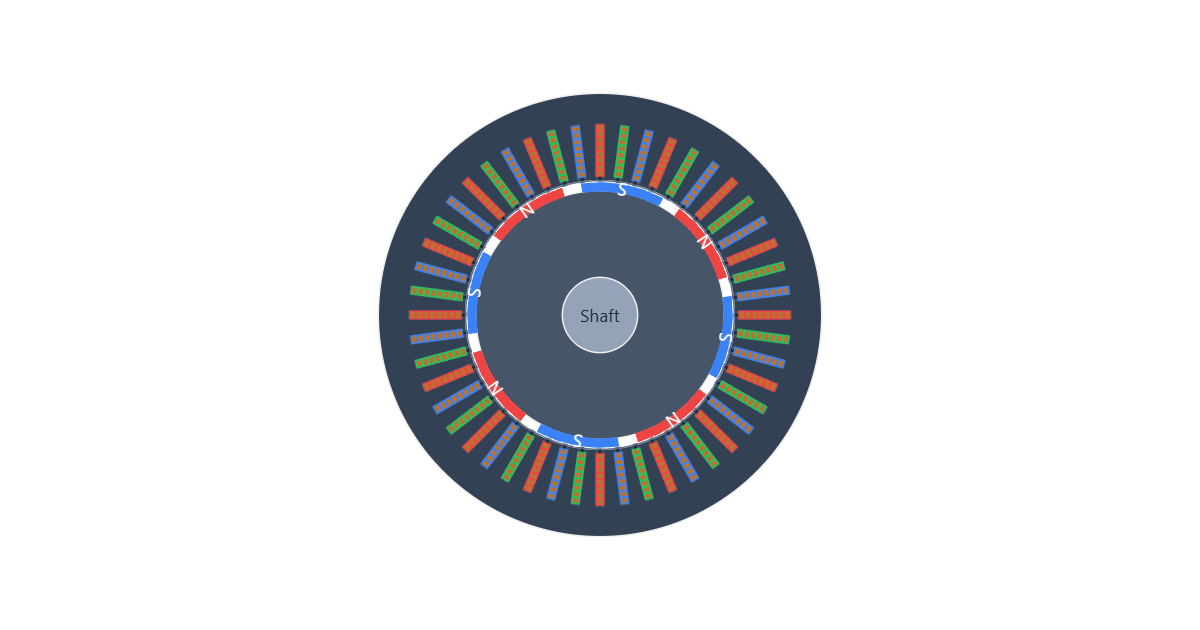
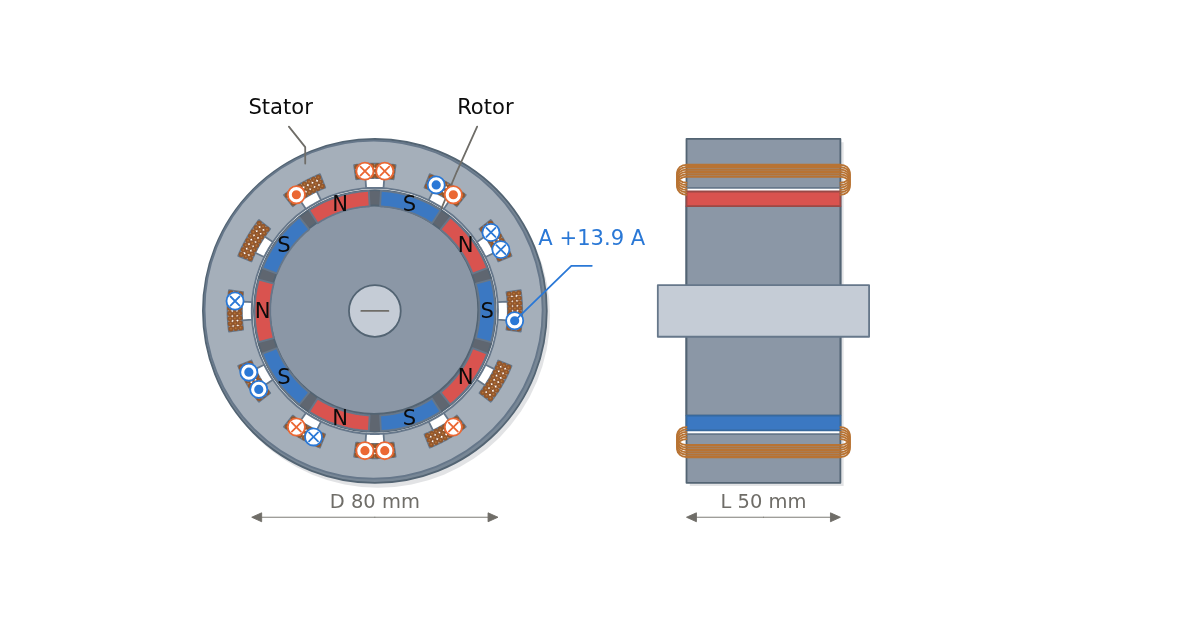
PMSM motor design tool with winding layout synthesis, back-EMF, torque, losses, and animated rotating field stator diagram.
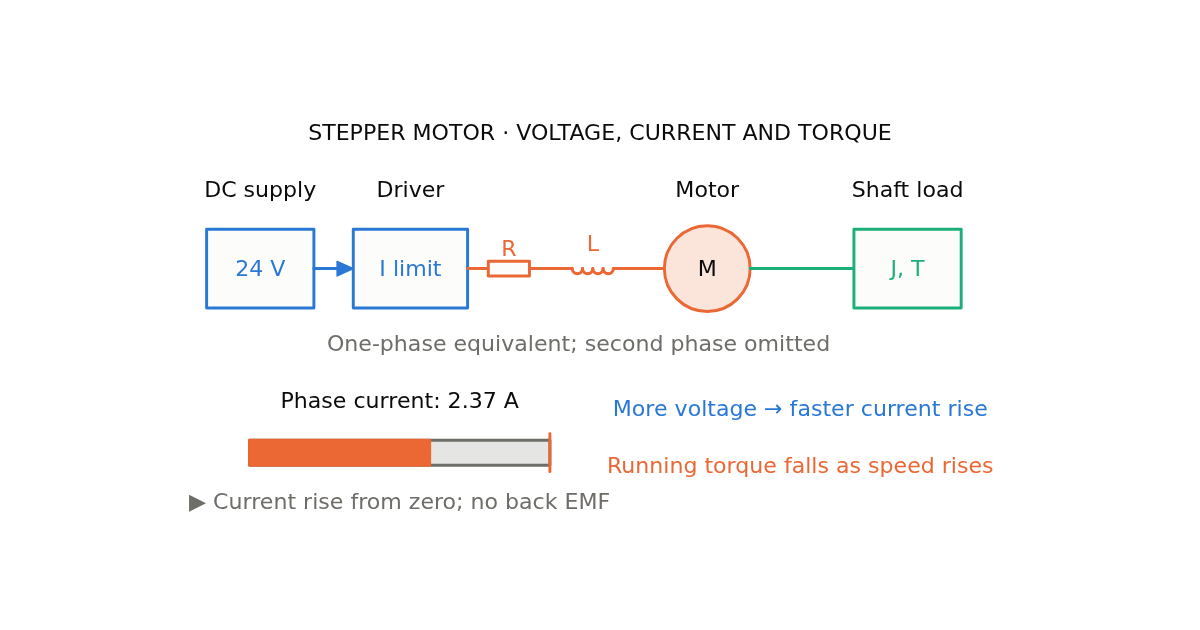
Wired White v2 Compare stepper torque-speed estimates at maximum-torque alignment and driver voltages. Includes load inertia, L/R current rise, microstep torque and resonance.
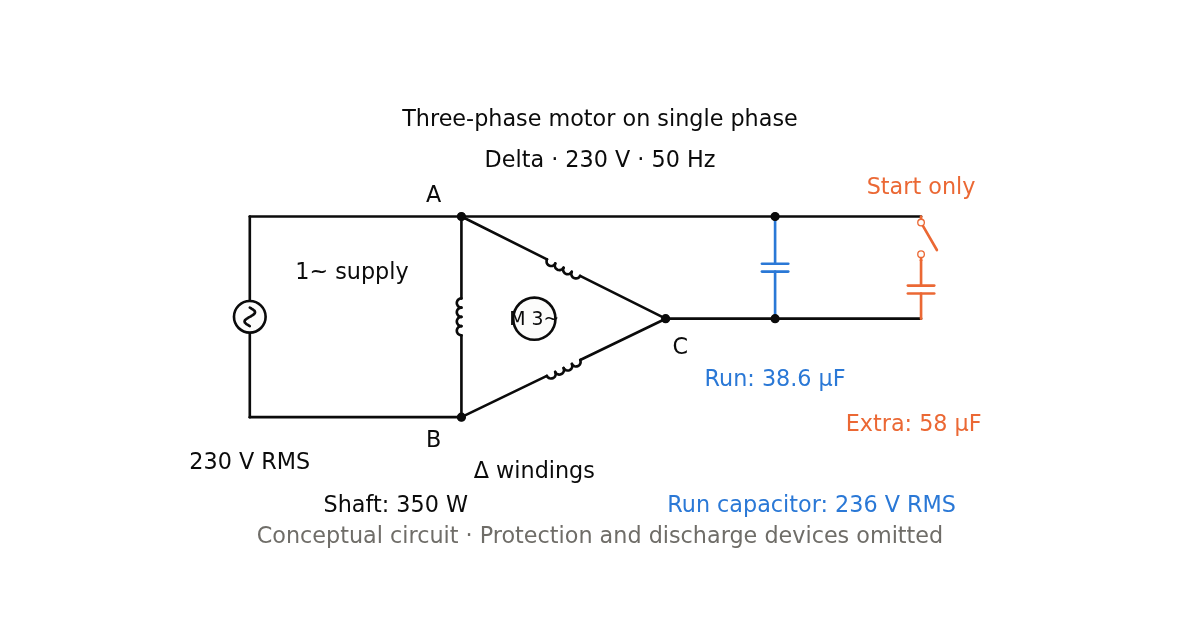
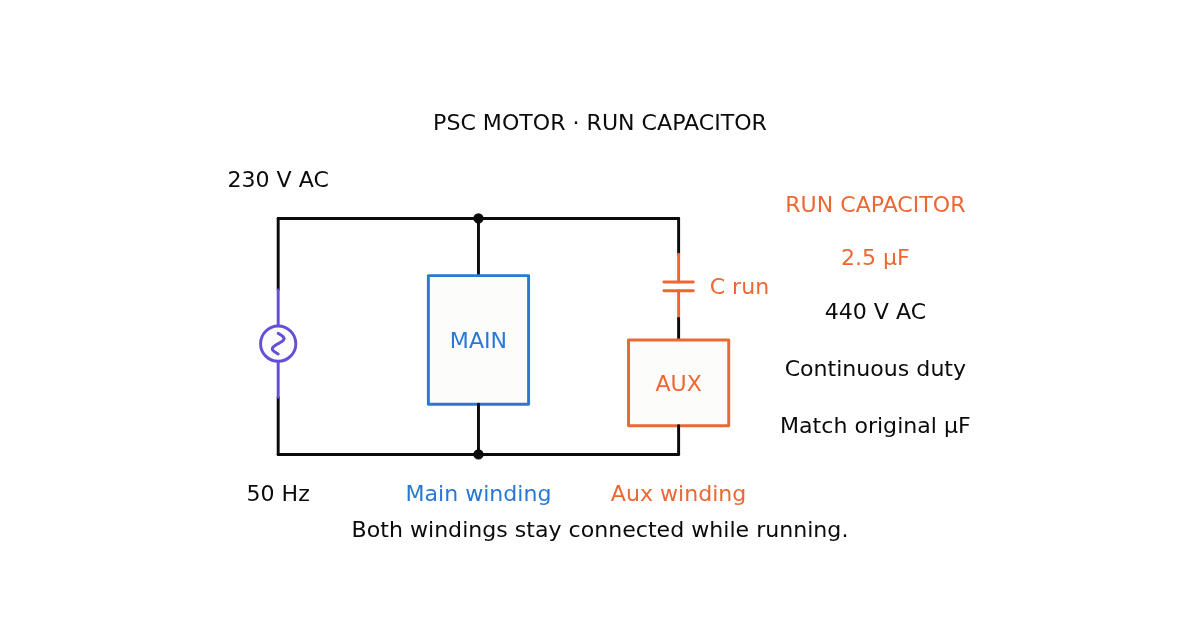
Wired White v3 Size a Steinmetz run capacitor at a chosen load using a motor circuit model. Check starting capacitance, capacitor voltage, winding currents and available power.
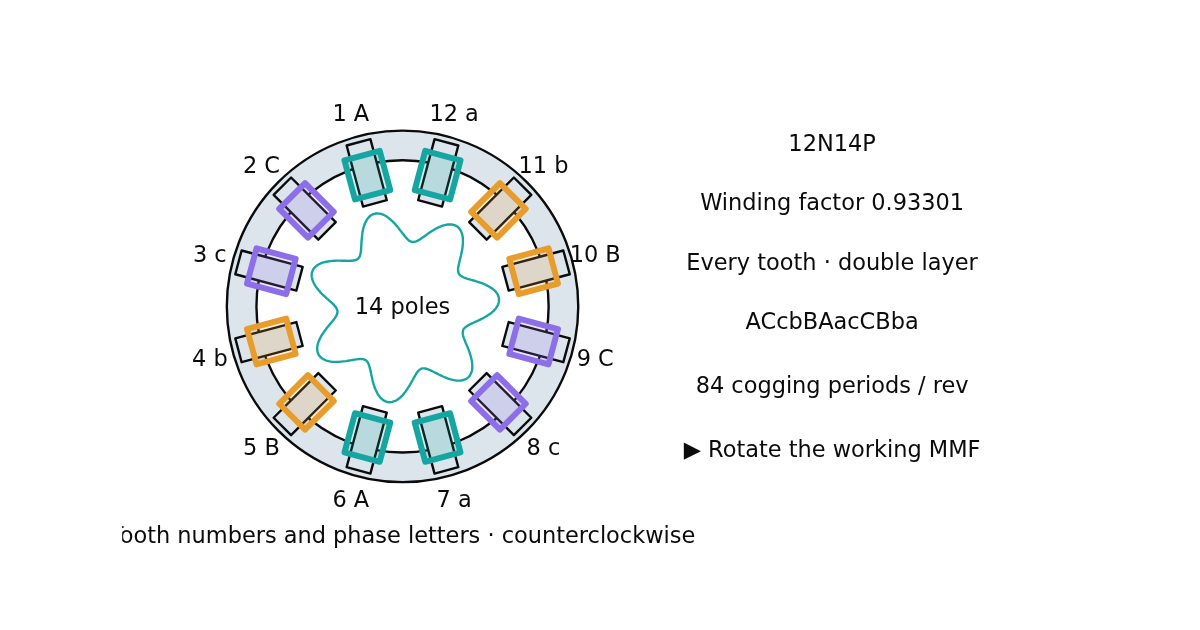
Wired White v2 Design tooth-coil windings for 12N14P, 24N22P and other slot/pole combinations. Get phase letters, winding factors, MMF harmonics, cogging indicators and star/delta lead schedules.
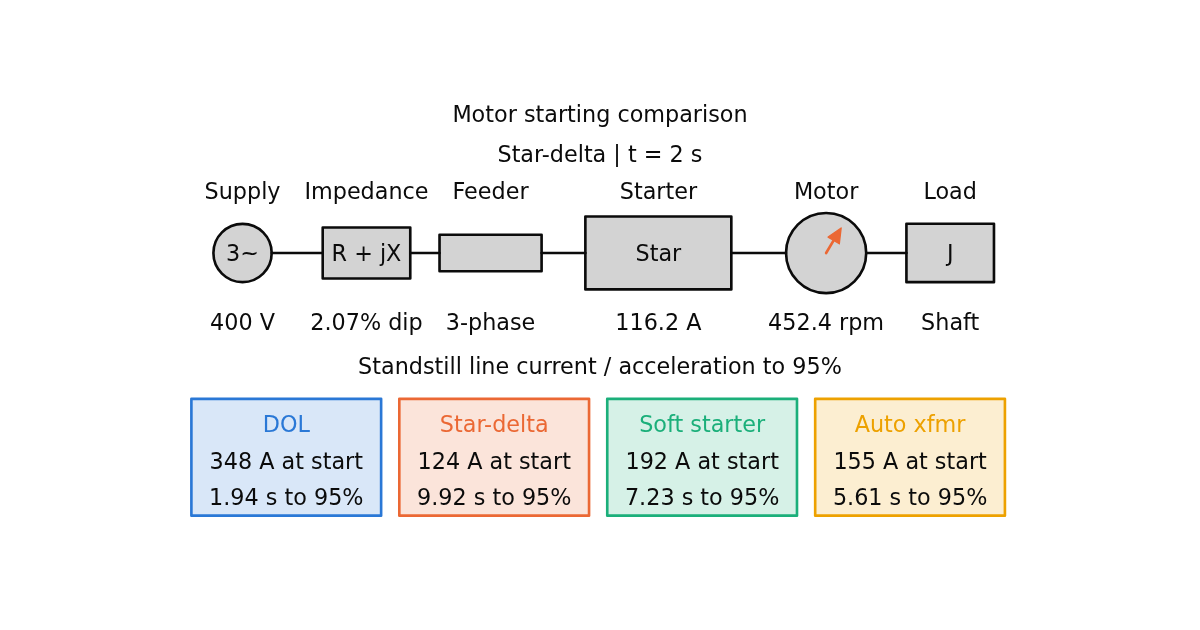
Wired White v2 Compare DOL, star-delta, soft-starter and autotransformer starts. Estimate motor current, torque, acceleration time and supply dip, then check feeder drop and overload settings.
Wired White v3 Match a PSC motor run capacitor or estimate its 90° current-split target from winding impedances. Compare µF, AC voltage ratings and animated winding-current phasors.
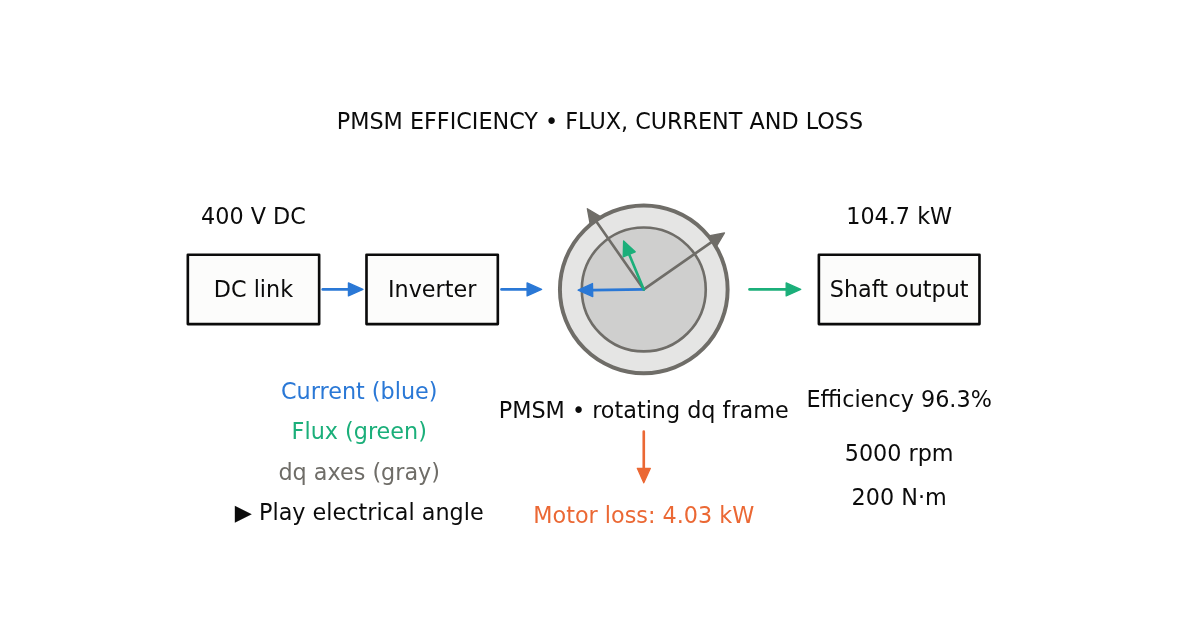
Wired White v2 Calculate a minimum-loss PMSM efficiency map from public nonlinear flux and loss data. Explore current and voltage limits, MTPA/MTPV guides, scaling and optional PWM losses.
Wired White v5 Size a star-connected BLDC winding, convert Kv and Kt, and check torque, voltage headroom, copper losses and slot fill. Includes a speed envelope and six-step commutation animation. Adds target-Kv wire candidates and tooth-coil star connections.
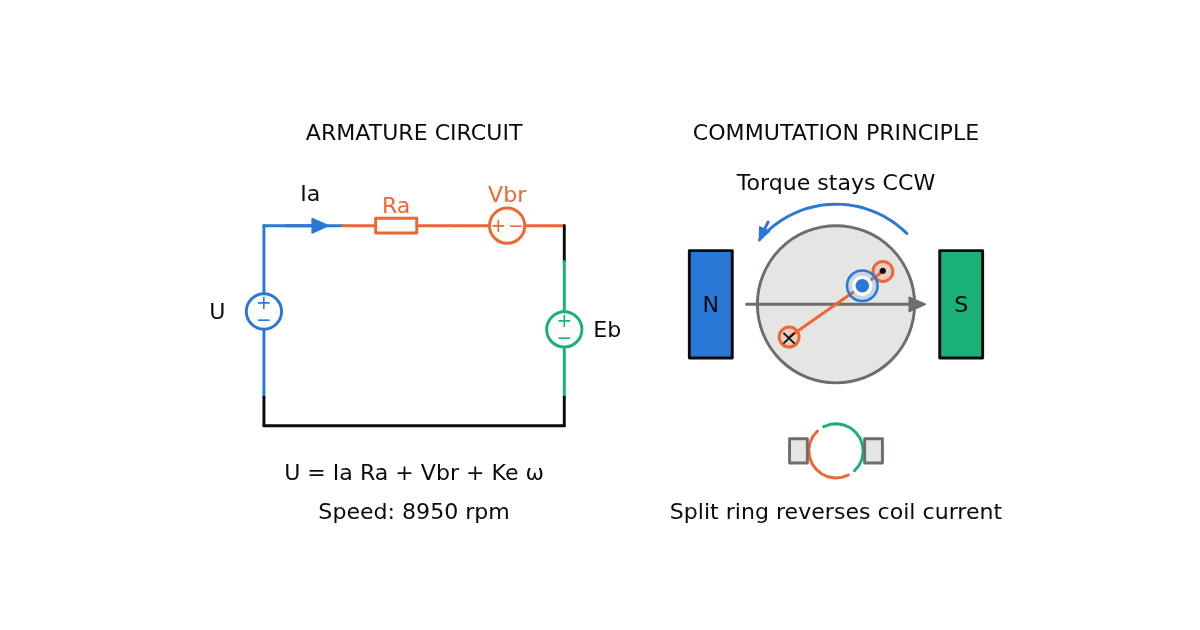
Wired White v3 Calculate brushed DC motor speed, torque, current and efficiency from datasheet or winding data. Explore operating curves, voltage sizing, field estimates and commutation.
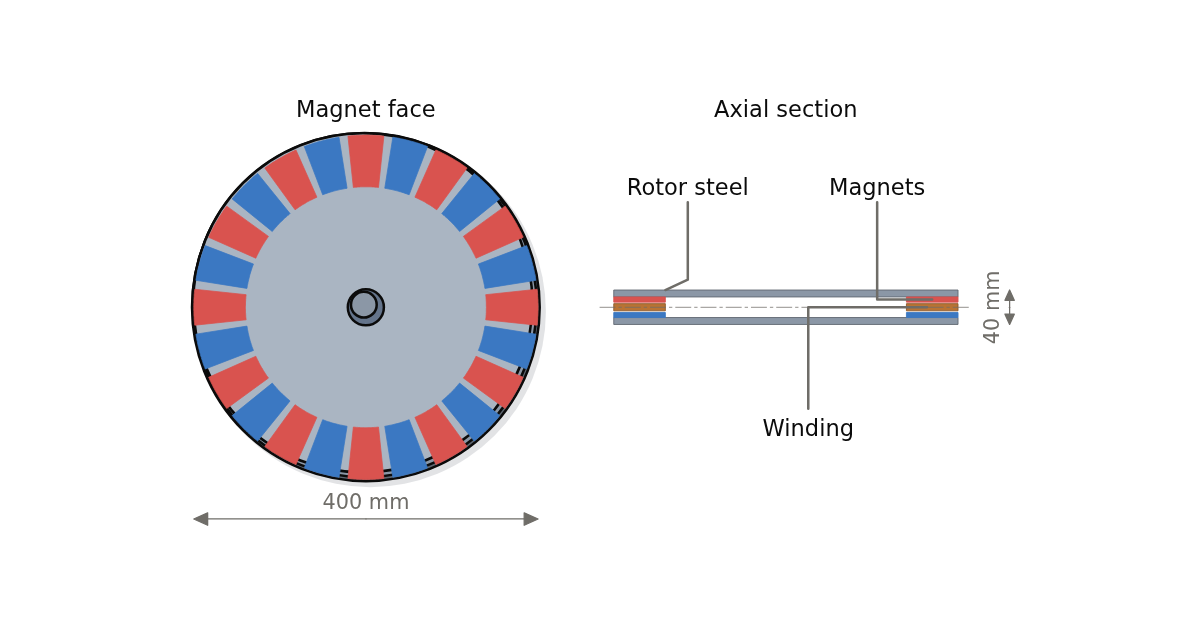
Wired White v5 Design coreless or iron-cored axial-flux motors with radial magnetic and loss models. Add stock-magnet fit, coil packing, wire estimates and numbered wye connections.
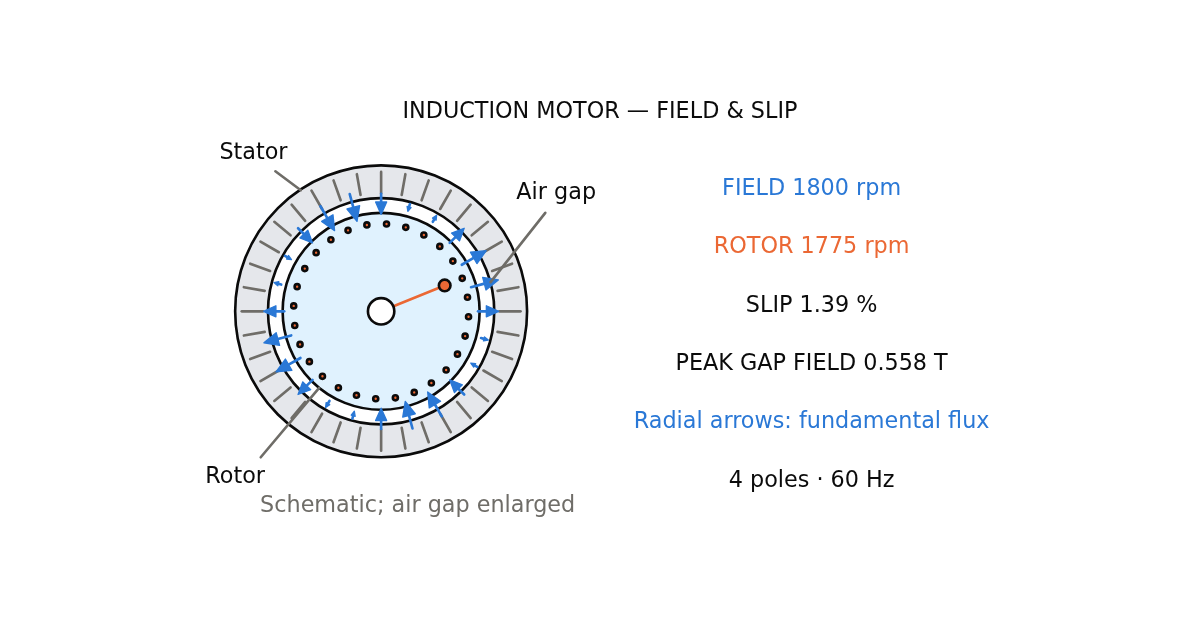
Wired White v2 Size air-gap, tooth and yoke magnetic loading; calculate motor torque, current, efficiency and losses. Enter circuit parameters or estimate them from catalogue data.
Wired White v3 Estimate IPMSM flux linkage and saturating dq inductances, then explore MTPA, field weakening and voltage-limited torque with Prius reference checks.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.