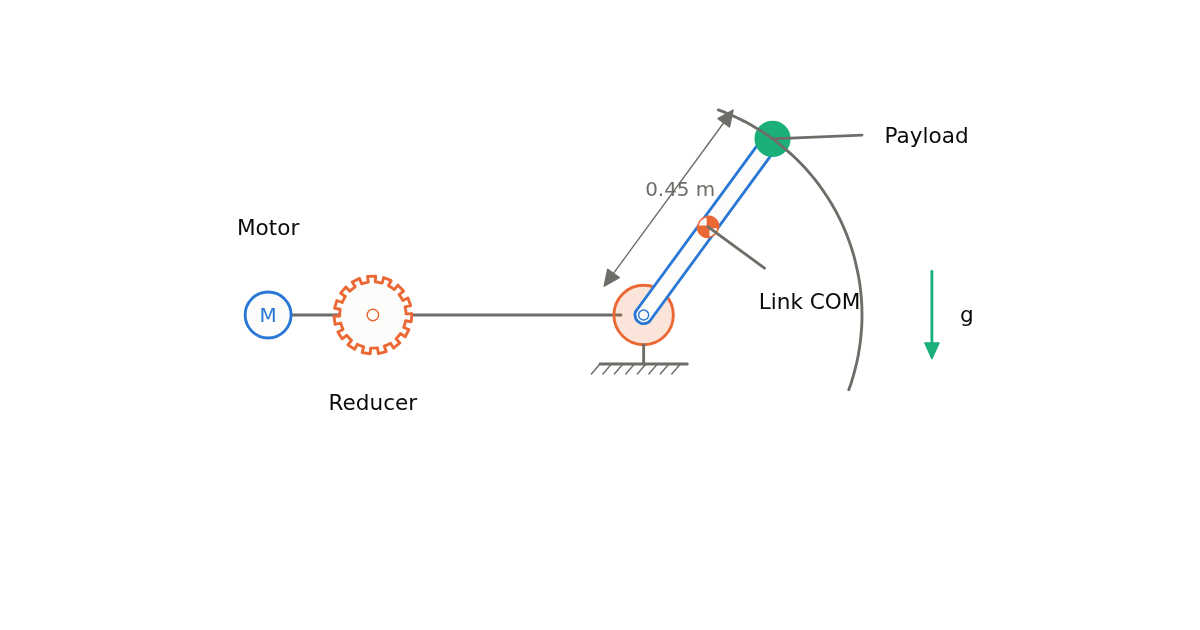
Robot Joint RMS Torque & S1 Motor Thermal Check
 Wired White v2
Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
Wired White v2 Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
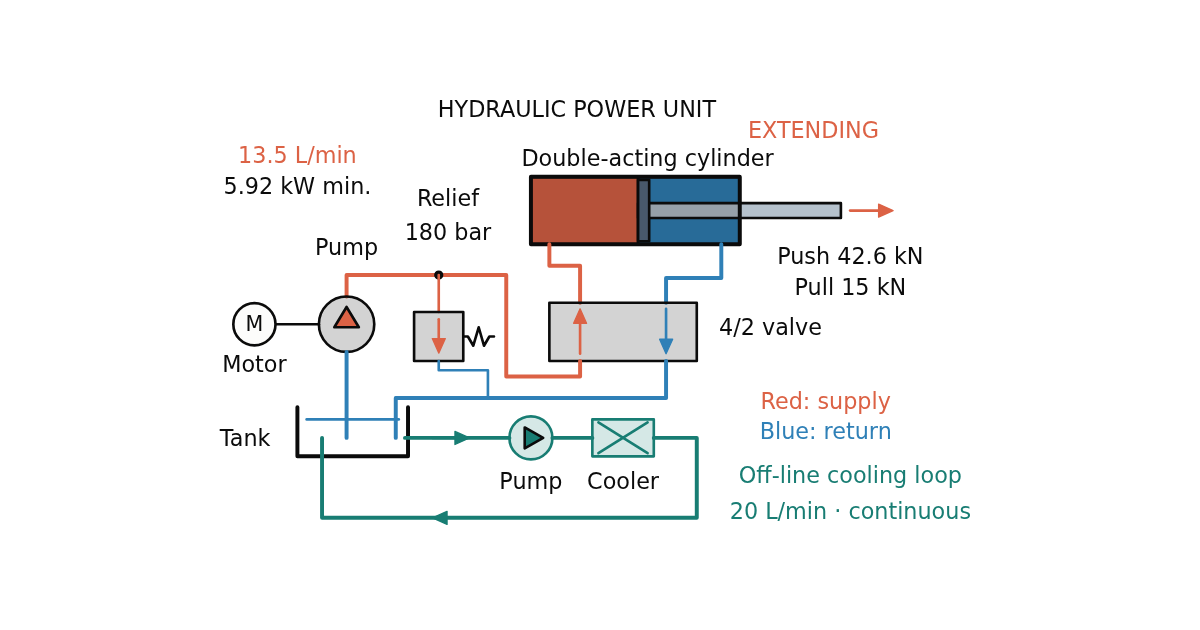
Wired White v2 Size a hydraulic power pack from pump displacement, pressure and cylinder geometry. Calculate push/pull force, speed, motor demand, reservoir volume, cooling duty and rod buckling.
Wired White v5 Size a star-connected BLDC winding, convert Kv and Kt, and check torque, voltage headroom, copper losses and slot fill. Includes a speed envelope and six-step commutation animation. Adds target-Kv wire candidates and tooth-coil star connections.
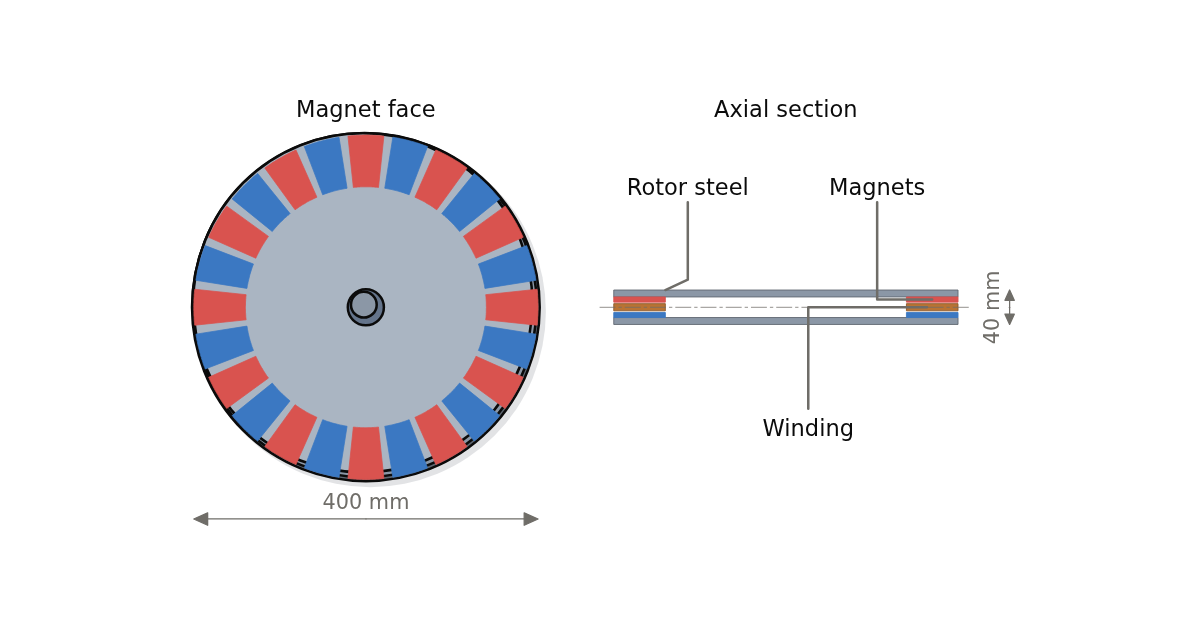
Wired White v5 Design coreless or iron-cored axial-flux motors with radial magnetic and loss models. Add stock-magnet fit, coil packing, wire estimates and numbered wye connections.
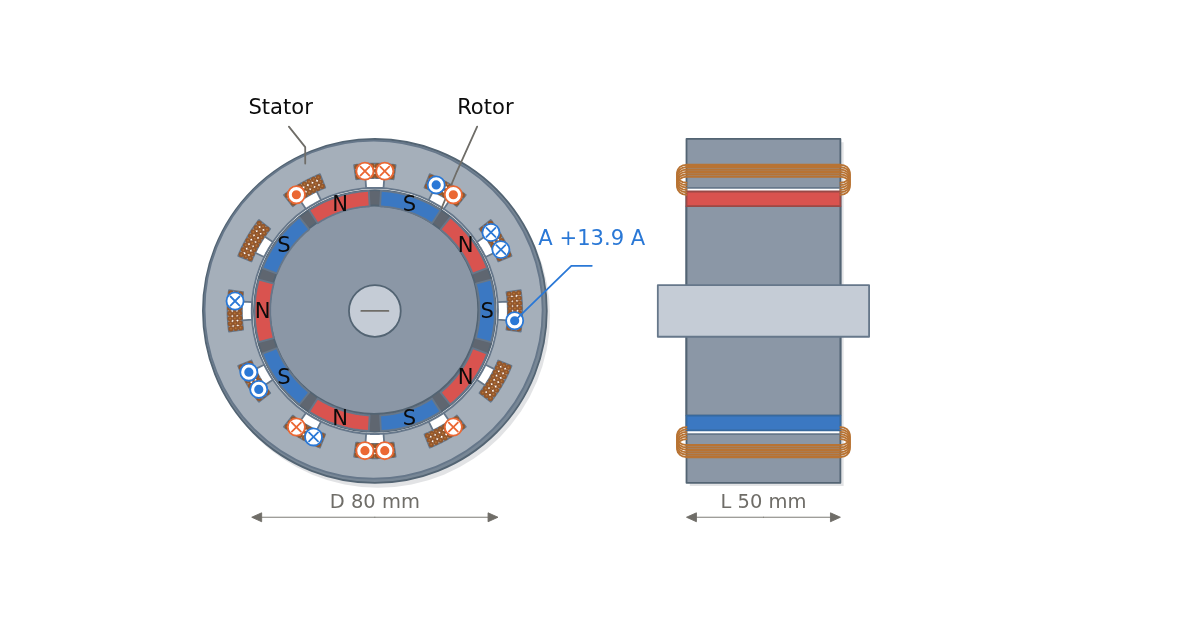
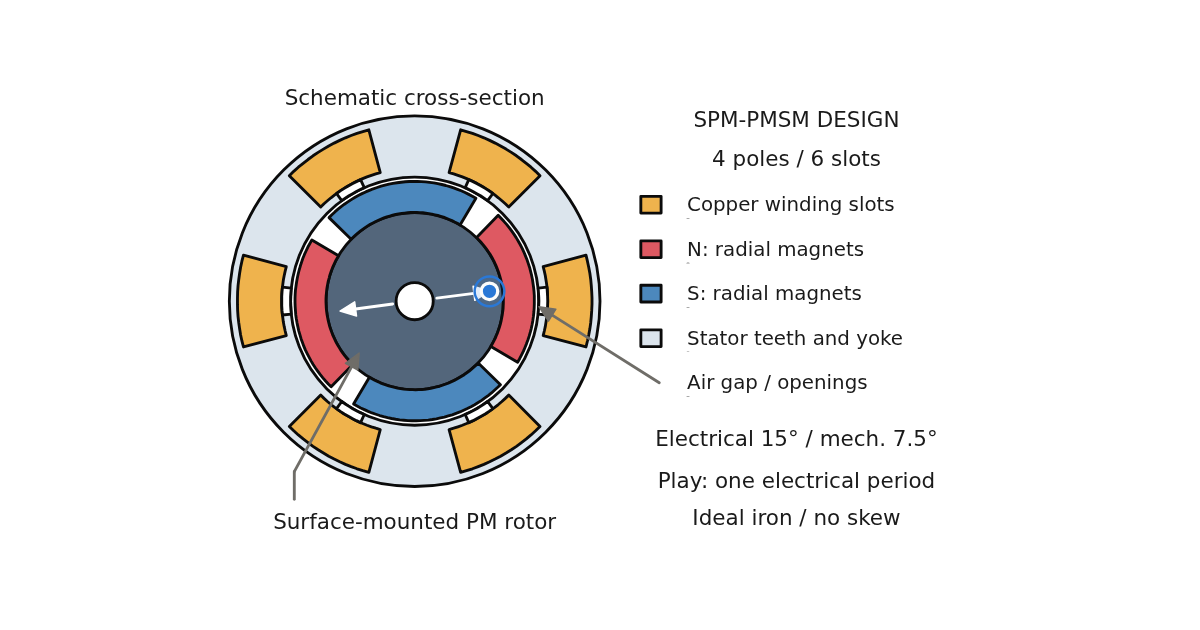
Wired White v4 Design a surface PMSM with semi-closed slots. Calculate air-gap field, back EMF, cogging torque, inductance and active length using a verified 2D subdomain model.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.