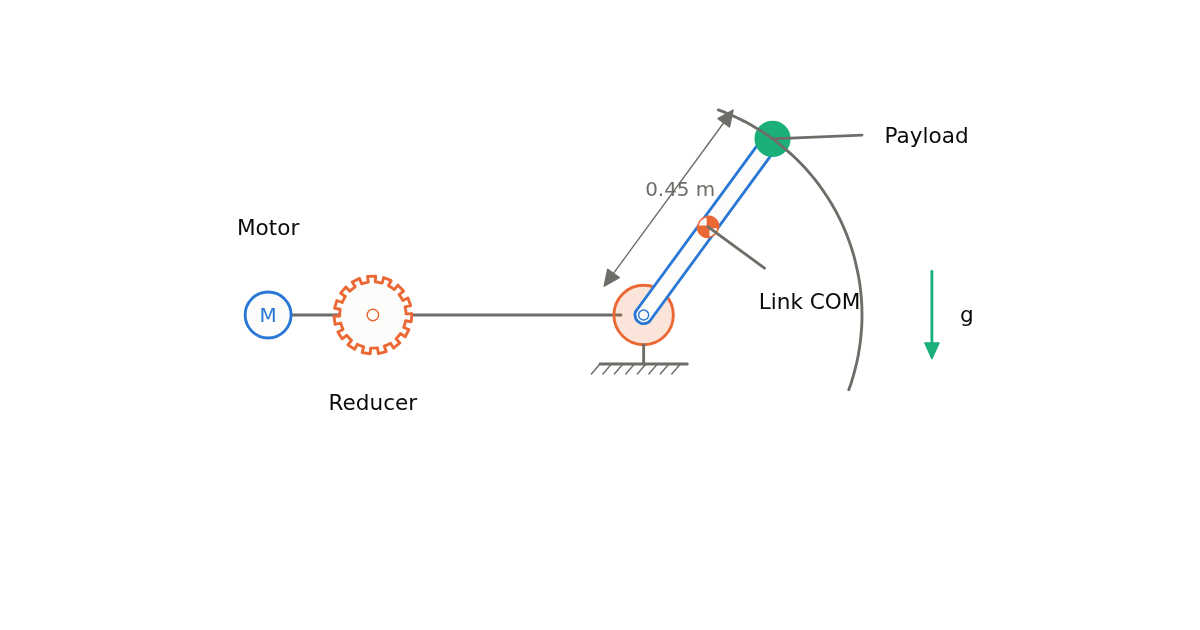
Robot Joint RMS Torque & S1 Motor Thermal Check
 Wired White v2
Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
Wired White v2 Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
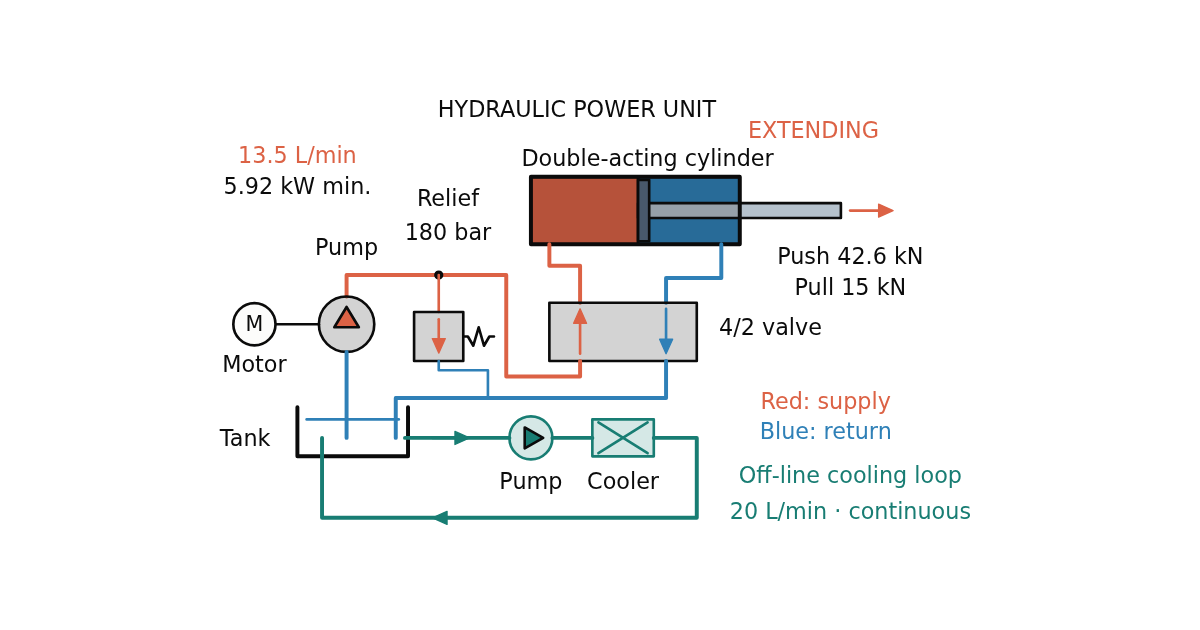
Wired White v2 Size a hydraulic power pack from pump displacement, pressure and cylinder geometry. Calculate push/pull force, speed, motor demand, reservoir volume, cooling duty and rod buckling.
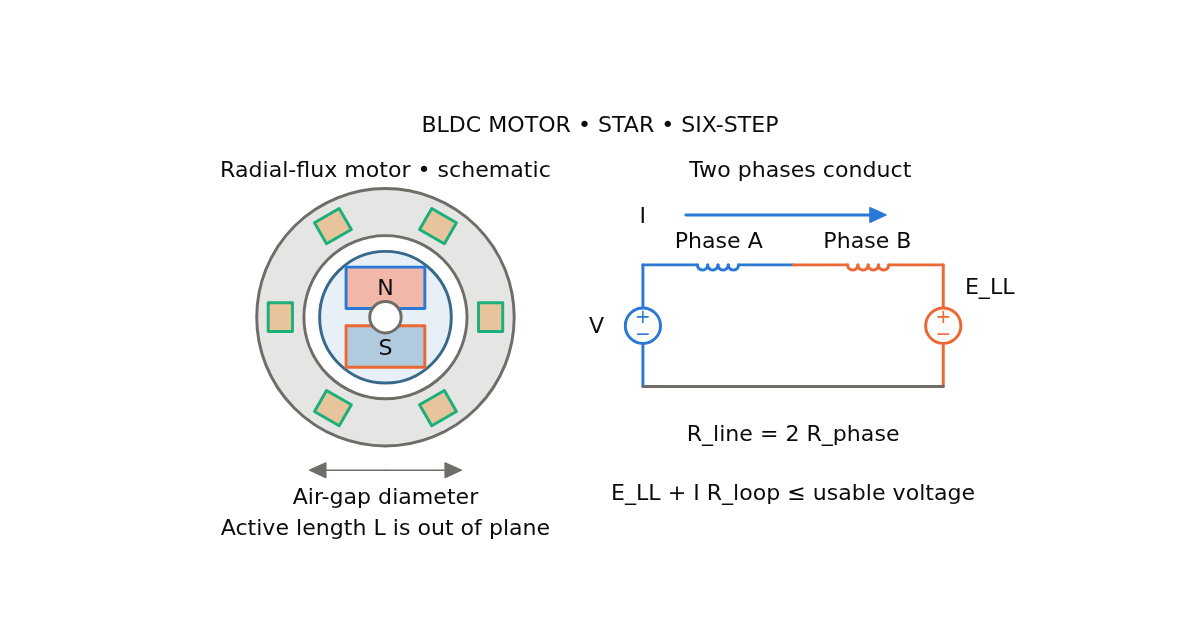
Wired White v2 Size a star-connected BLDC winding, convert Kv and Kt, and check torque, voltage headroom, copper losses and slot fill. Includes a speed envelope and six-step commutation animation.
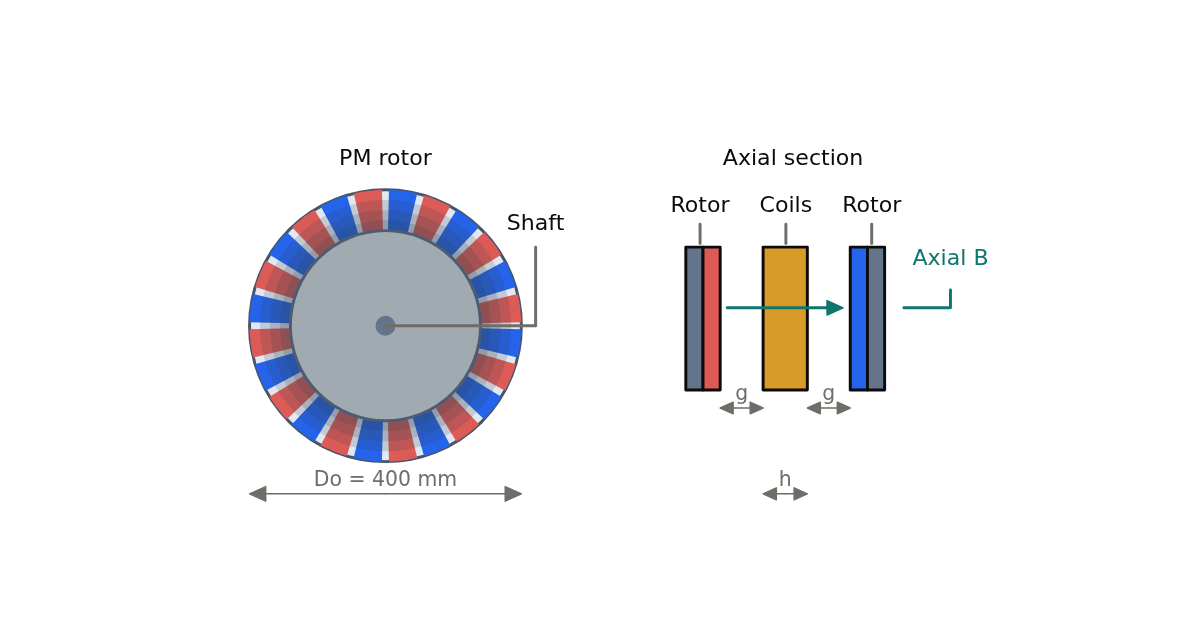
Wired White v3 Design coreless or iron-cored AFPM motors with radial magnetic solutions and loss models. Compare diameter ratio, torque density, air-gap shear and direct-drive presets.
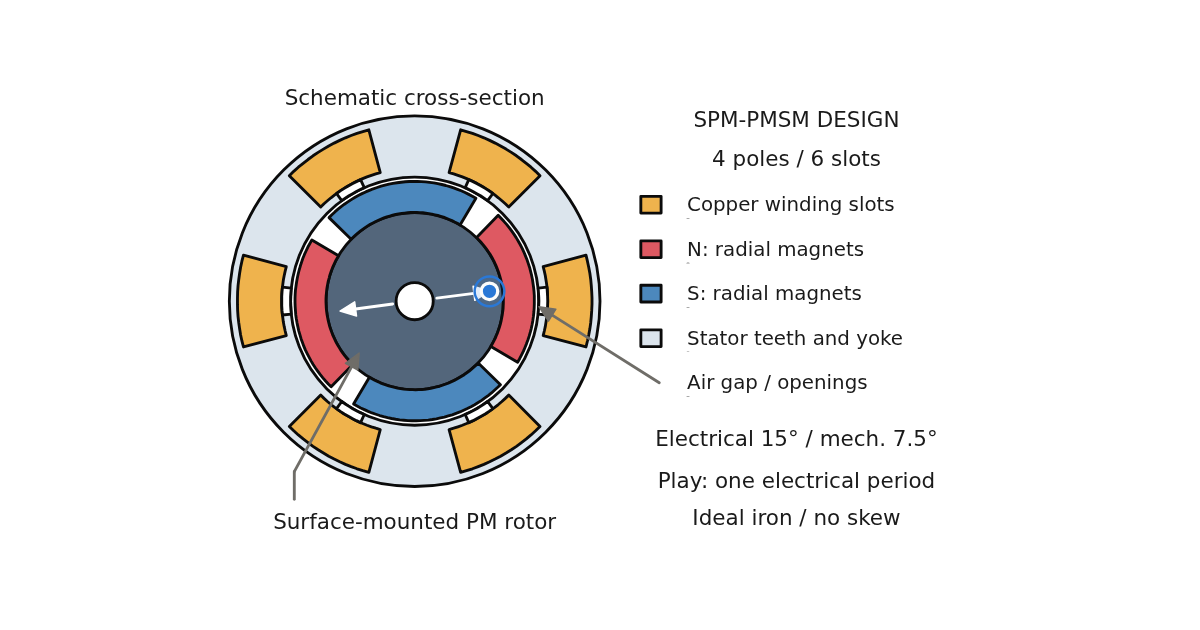
Wired White v3 Legen Sie eine PMSM mit Oberflächenmagneten und halbgeschlossenen Nuten aus. Berechnen Sie Luftspaltfeld, Gegen-EMK, Rastmoment, Induktivität und aktive Länge mit einem verifizierten 2D-Teilgebietsmodell.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.