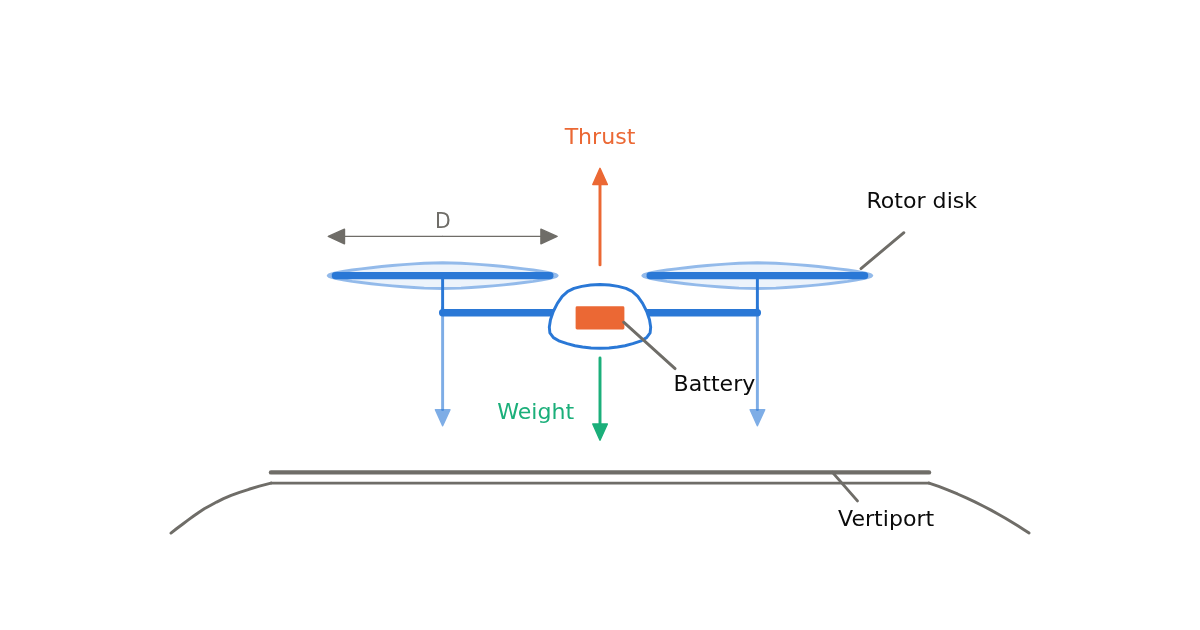
Drone & eVTOL Hover: Altitude, Cold Battery and Thrust Margin
 Wired White v3
Check altitude and cold-weather hover using ISA density, rotor RPM, blade-loading and tip-Mach limits, battery voltage sag, thrust reserve and hover time.
Wired White v3 Check altitude and cold-weather hover using ISA density, rotor RPM, blade-loading and tip-Mach limits, battery voltage sag, thrust reserve and hover time.
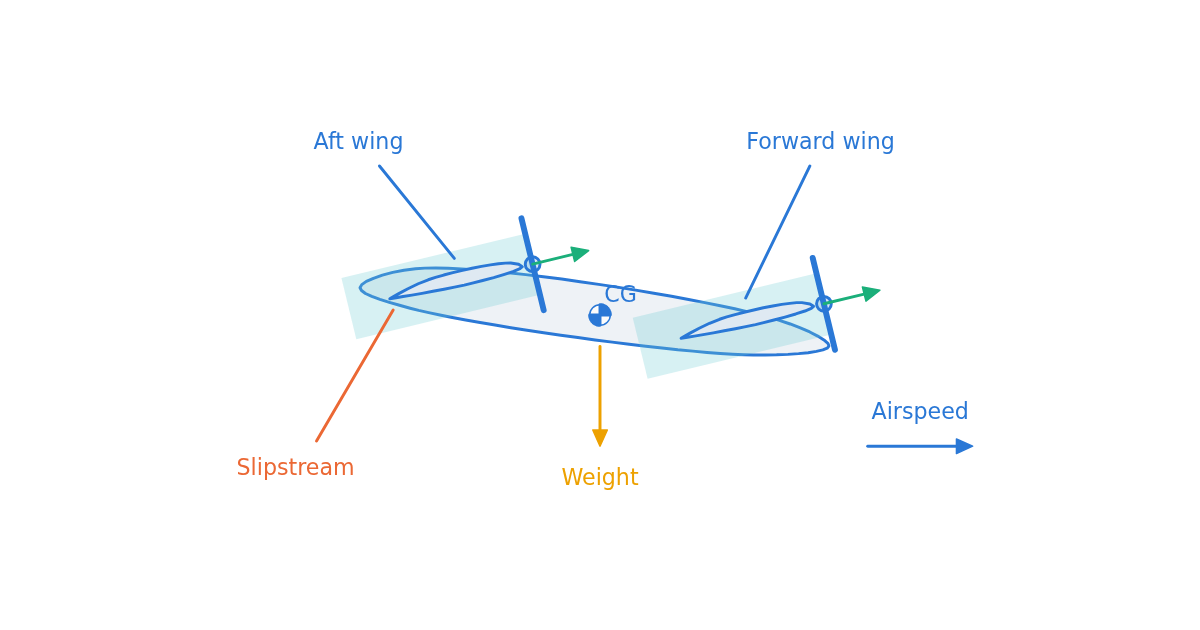
Wired White v4 Map airspeed against wing tilt using coupled force and pitch equilibrium, propeller slipstream, wing stall, thrust and power limits. Inspect a chosen transition path.
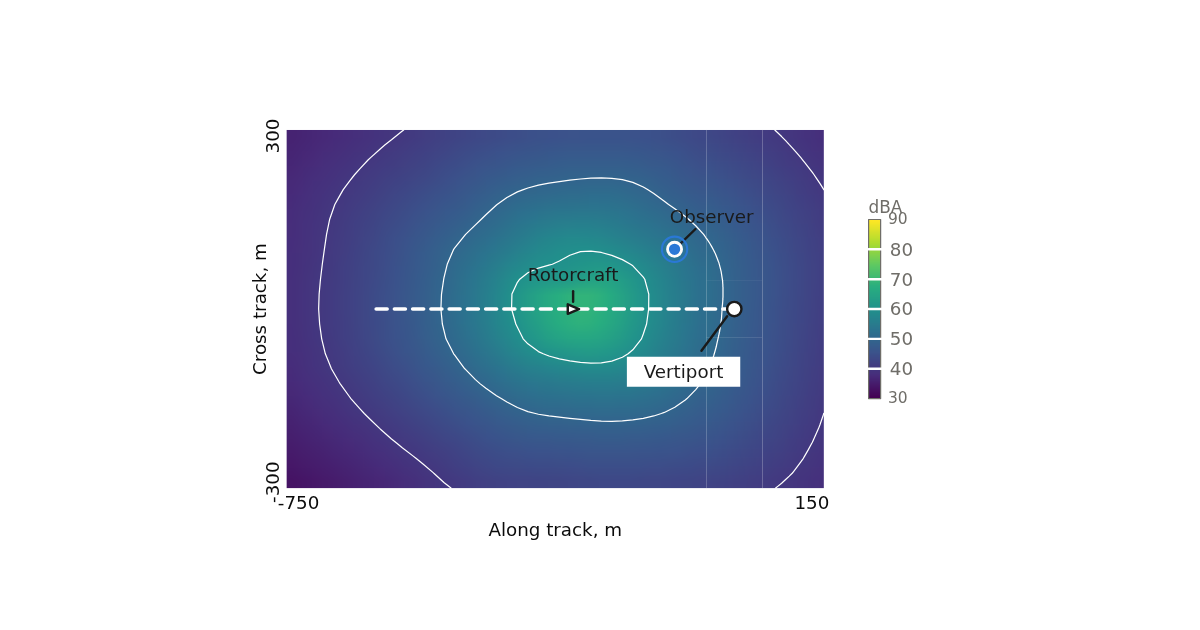
Wired White v4 Estimate directional eVTOL approach noise from rotor loading, thickness, blade-vortex interaction and broadband self-noise. Explore ground dBA contours and the BVI contribution.
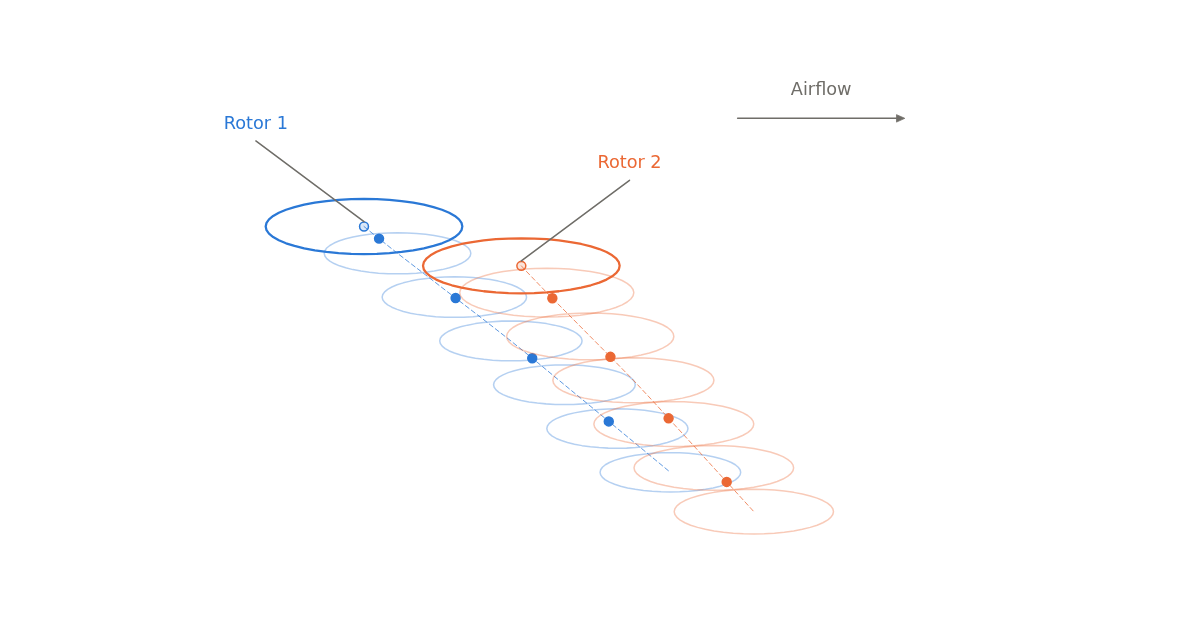
Wired White v2 Estimate thrust loss at fixed power or added power at held thrust for interacting eVTOL rotors. Includes conservative contracting vortex-ring wakes, forward-flight skew and marked sensitivity sweeps.
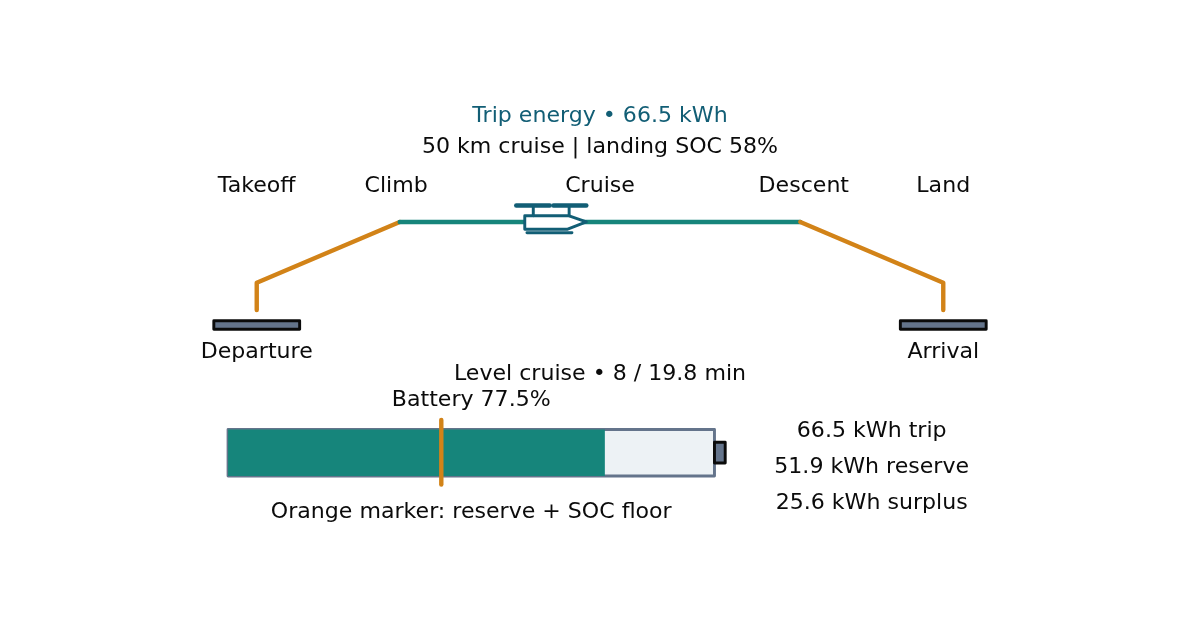
Wired White v2 Estimate eVTOL hover and cruise power, battery energy per trip, reserve requirements and landing SOC. Animate the mission and compare cruise distance with the available energy budget.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.