Inverted Pendulum Simulation: PID vs LQR
 Wired White v2
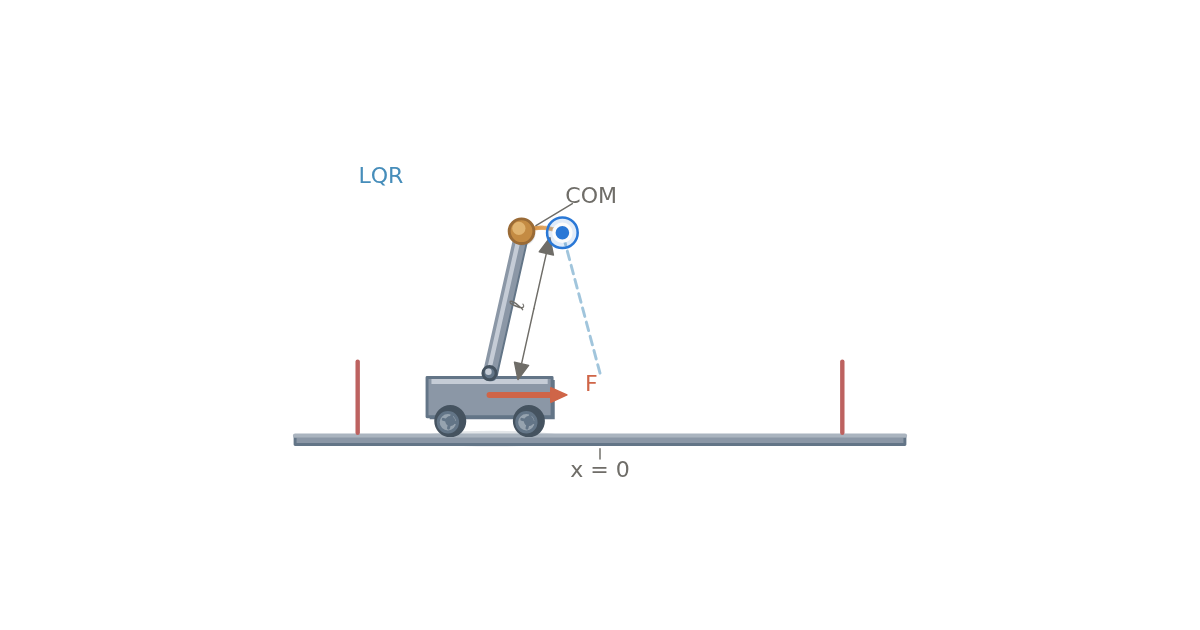
Compare PID and LQR on a nonlinear cart–pole with actuator saturation. Play the motion, apply timed pushes, and inspect settling, cart travel and closed-loop poles.
Wired White v2 Compare PID and LQR on a nonlinear cart–pole with actuator saturation. Play the motion, apply timed pushes, and inspect settling, cart travel and closed-loop poles.
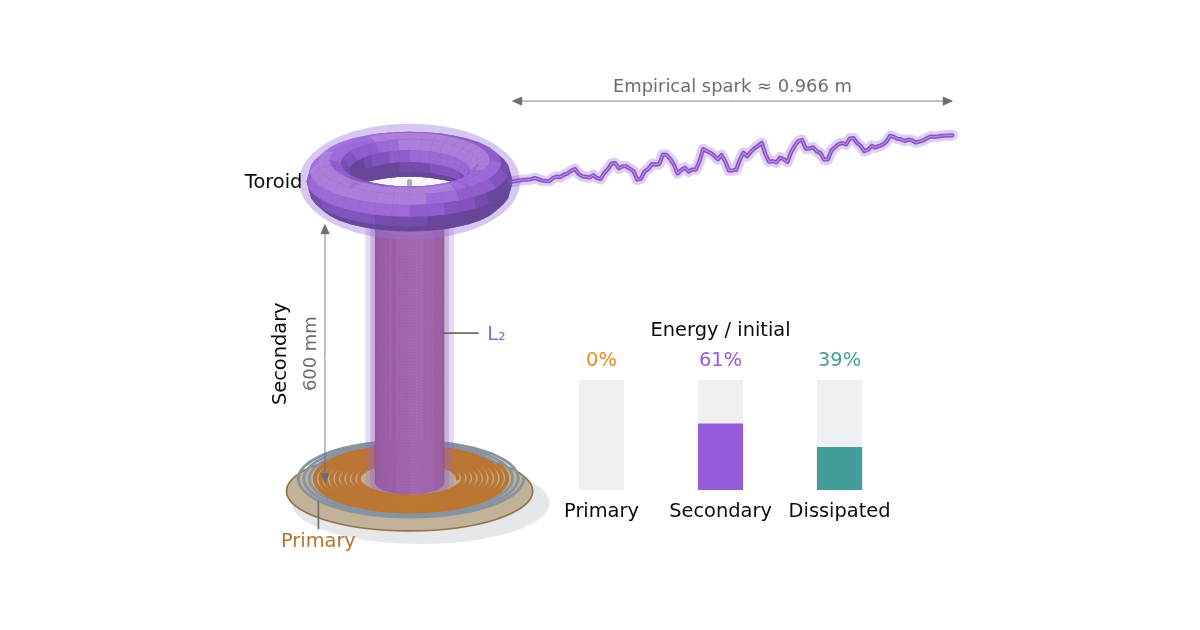
Wired White v3 Design primary and secondary resonance, find the tuning tap, integrate geometric coupling, and watch energy beat between two coupled circuits. Includes a toroid capacitance and empirical spark-length estimate.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.