

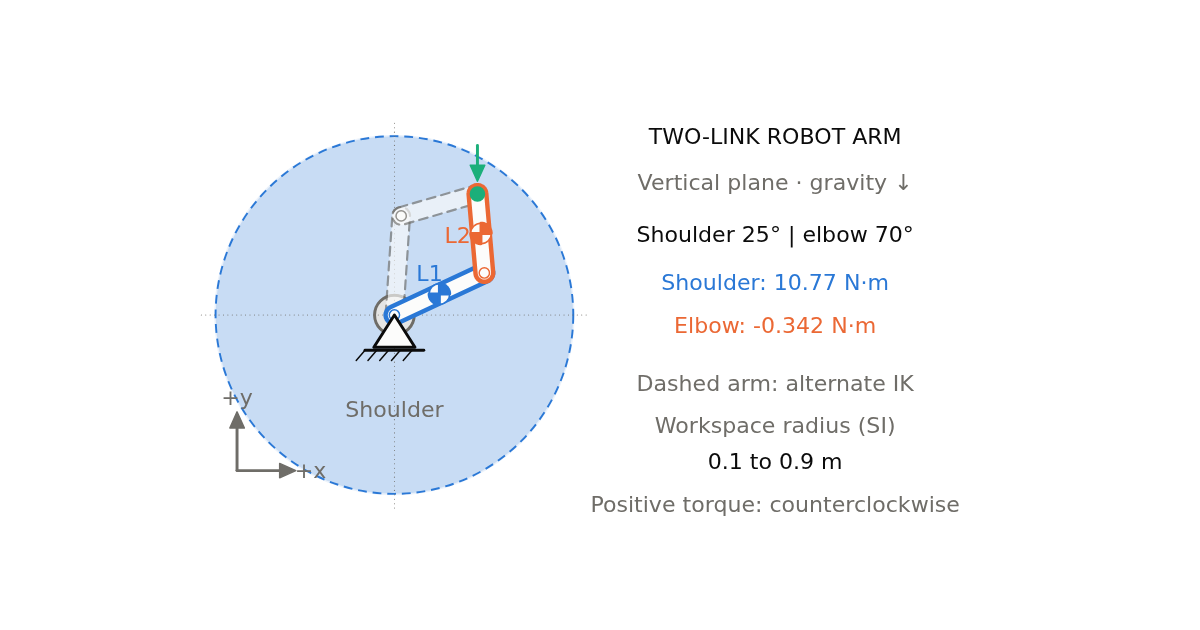
Two-Link Robot Arm Calculator: Inverse Kinematics & Torque
 Wired White v1
Solve forward and inverse kinematics for a planar two-link arm, compare elbow up/down, and calculate static joint torques from link masses and payload.
Wired White v1 Solve forward and inverse kinematics for a planar two-link arm, compare elbow up/down, and calculate static joint torques from link masses and payload.






Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.