

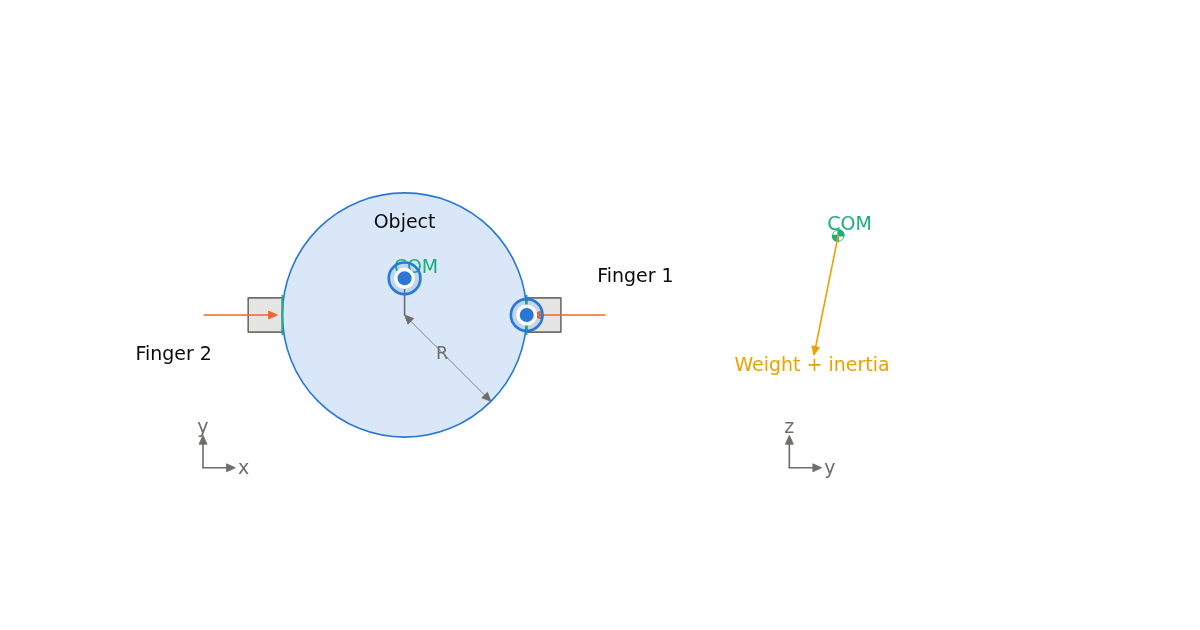
Robot Gripper Force: Friction Cone, Twist and Acceleration
 Wired White v3
Size a two- or multi-finger robot grasp against sliding and twisting. Include arm acceleration, an offset centre of mass and coupled soft-finger friction.
Wired White v3 Size a two- or multi-finger robot grasp against sliding and twisting. Include arm acceleration, an offset centre of mass and coupled soft-finger friction.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.