PID Controller Tuning Simulator
 Wired White v2
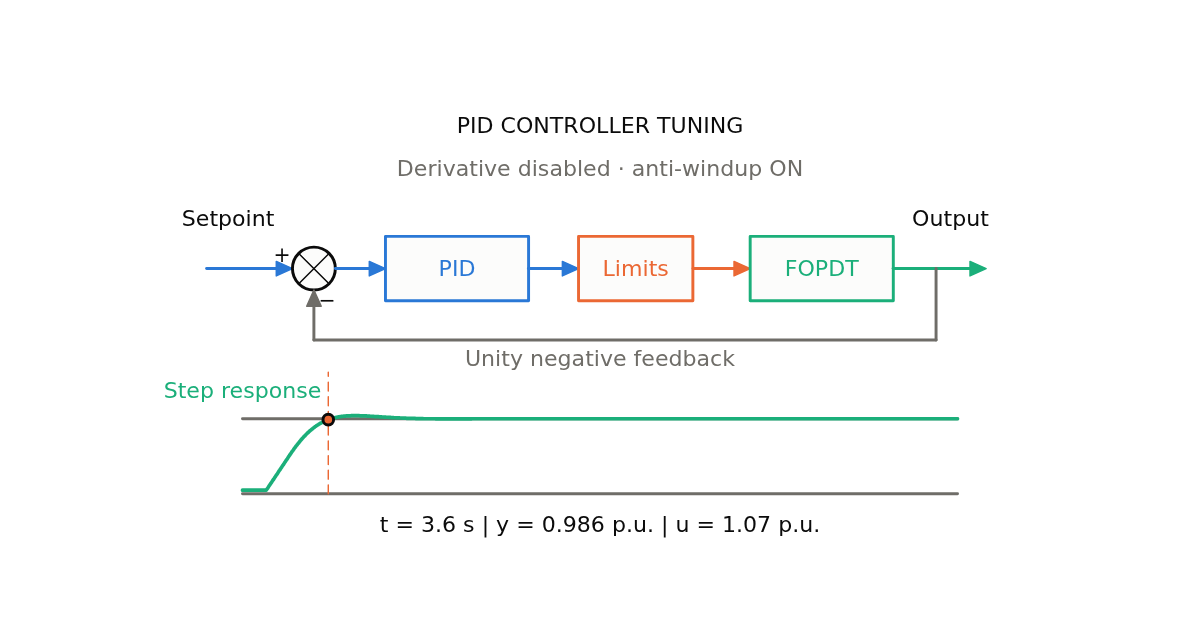
Tune a filtered PID controller on process and DC motor models. Compare step response, actuator saturation, Bode margins and a root locus with SIMC or Ziegler–Nichols settings.
Regelung und Antriebe: PID-Einstellung mit simulierter Sprungantwort, feldorientierte Regelung von PMSM- und Asynchronmotoren und die Clarke-Park-Transformation von abc nach dq0. Sehen Sie, wie sich Regelkreise und Bezugssysteme bewegen, wenn Sie die Eingaben ändern; jeder Rechner zeigt seine Methode.
Wired White v2 Tune a filtered PID controller on process and DC motor models. Compare step response, actuator saturation, Bode margins and a root locus with SIMC or Ziegler–Nichols settings.
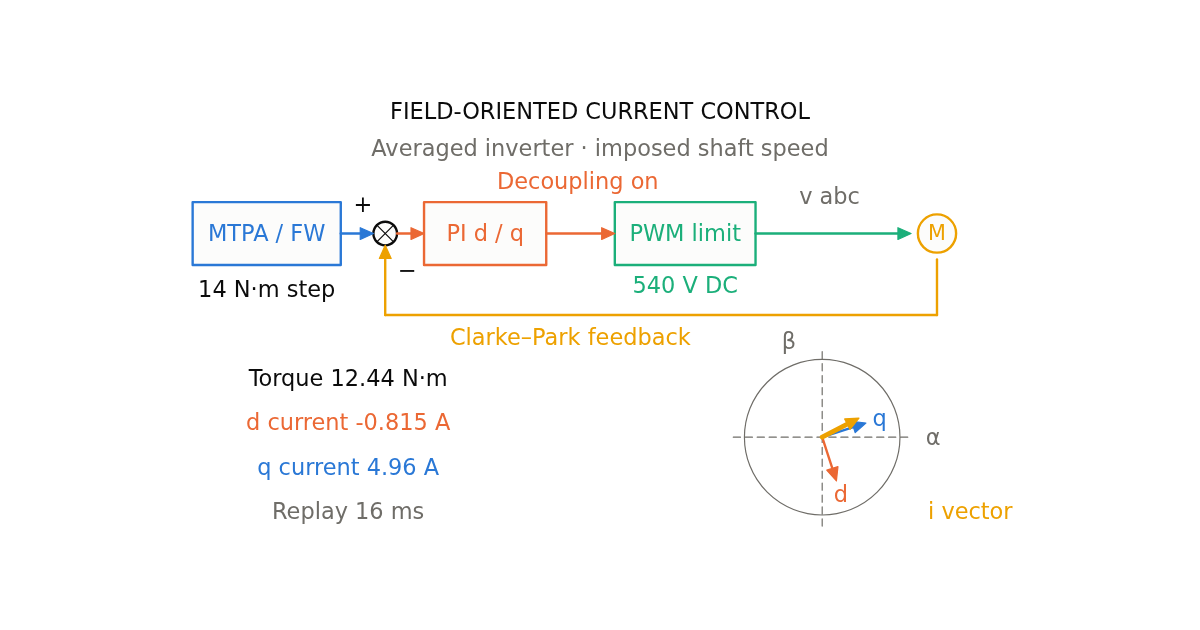
Wired White v2 Simulate field-oriented motor control with tuned PI current loops, decoupling, MTPA and field weakening. Explore dq transients, torque, inverter limits and rotating current vectors.
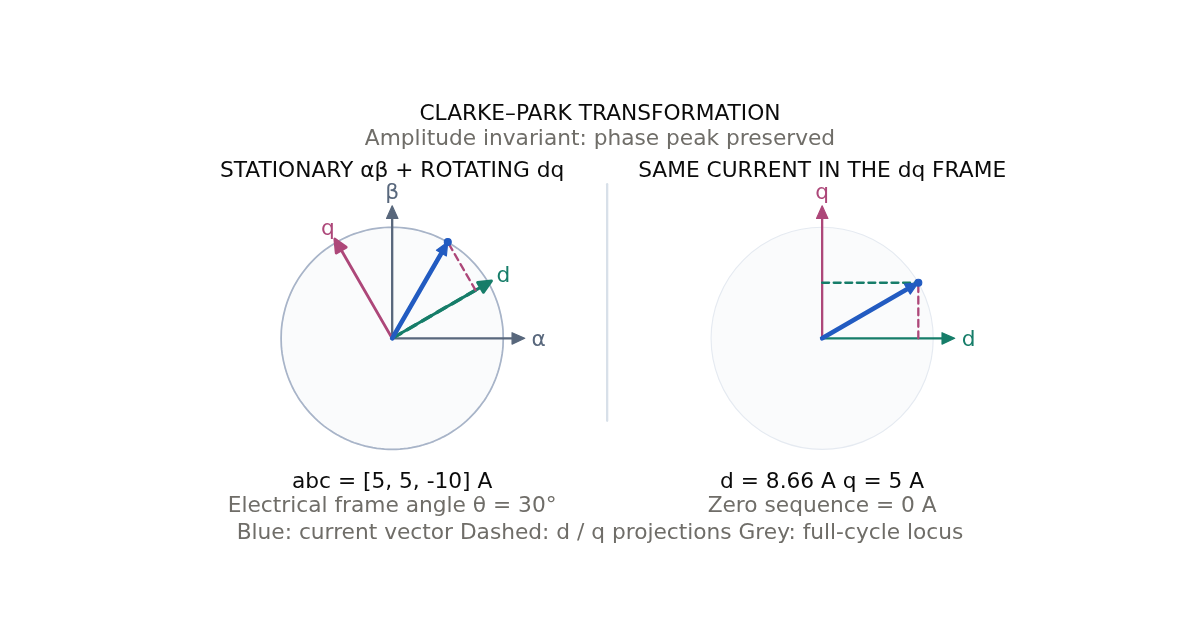
Wired White v2 Convert abc currents to αβ0 and dq0 with animated phasors, rotating frames, amplitude- or power-invariant scaling, and inverse reconstruction.
Press ▶, then Space (or tap the drawing) to flap. MeowL dodges spreadsheet errors; every frame is calculated by the same engine as a beam.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.