

Humanoid Robot: Balance, Joint Torque and Runtime
 Wired White v1
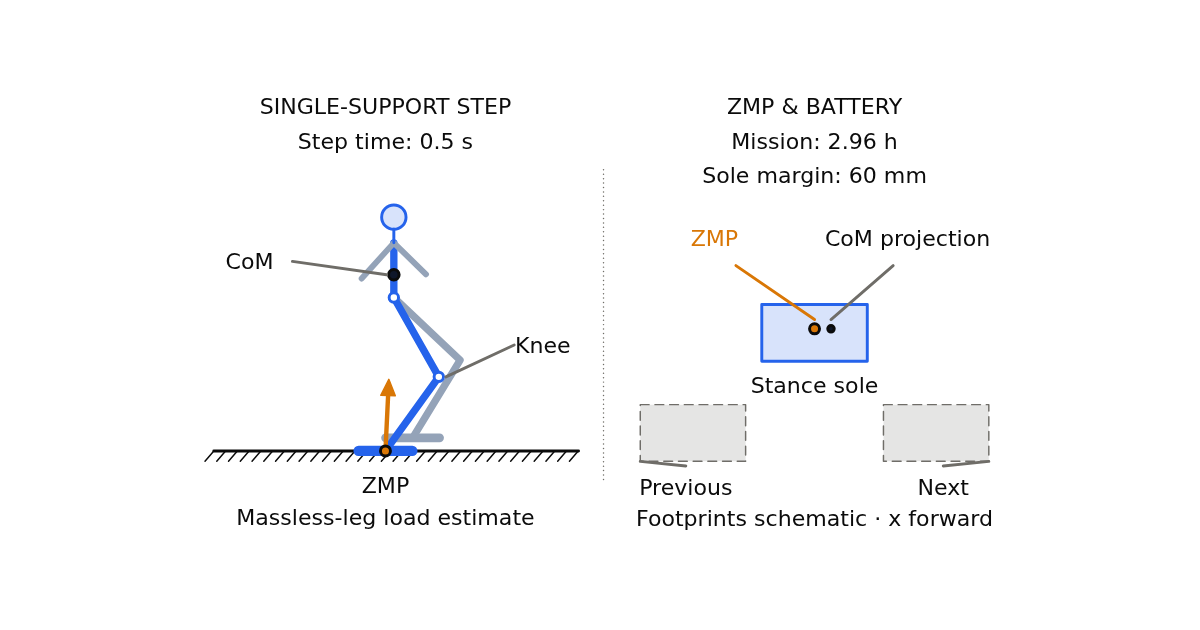
Estimate humanoid robot battery life, ZMP balance margins and hip/knee stance torque. Animate a walking step and compare battery, gait and duty-cycle assumptions.
Robot drive sizing, robot-arm kinematics and drone flight time: calcs for mobile robots, manipulators and multicopters, with drawings you can move.
Wired White v1 Estimate humanoid robot battery life, ZMP balance margins and hip/knee stance torque. Animate a walking step and compare battery, gait and duty-cycle assumptions.






Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.