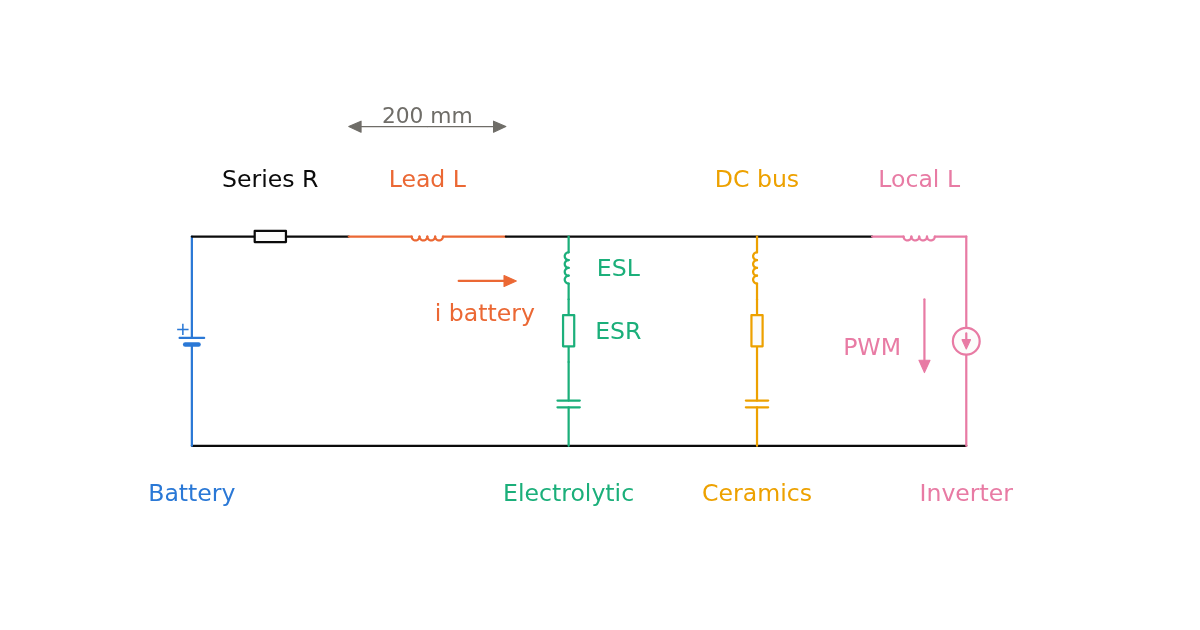
Simulieren Sie das Nachschwingen an ESC-Akkuleitungen und Schaltspitzen. Bemessen Sie eine Elkobank mit Keramikkondensatoren auf der Leiterplatte anhand von Rippelstrom-Effektivwert, Spannungsreserve und geschätzter Erwärmung.
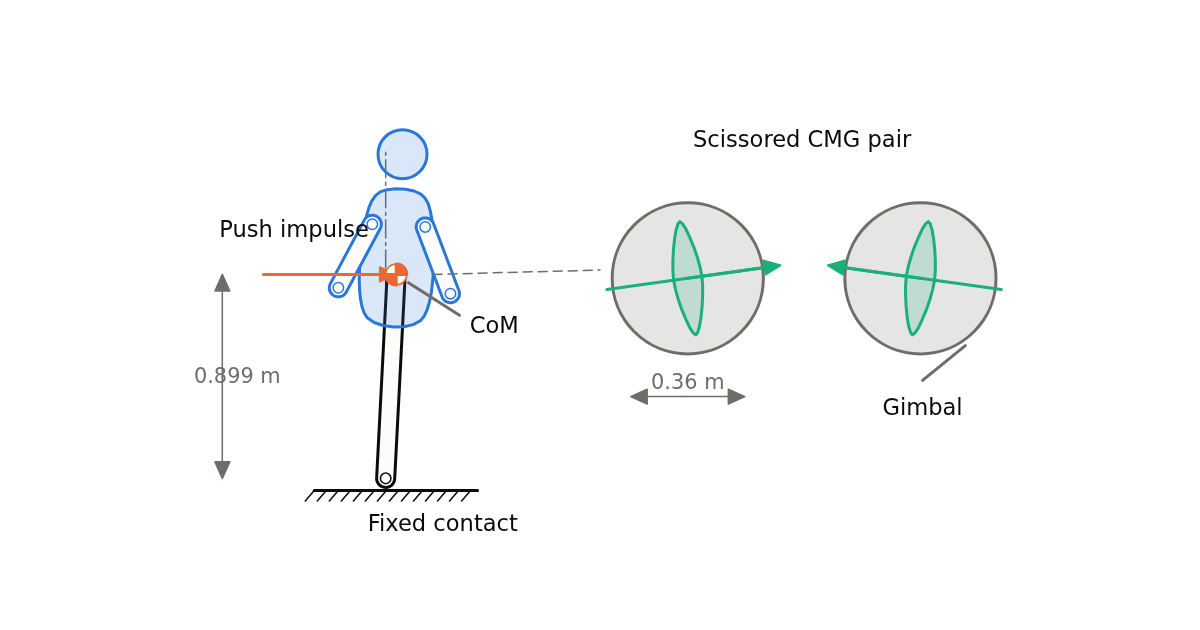
Size a humanoid reaction wheel or scissored CMG pair for push and post-slip recovery. Compare angular momentum, rotor size, speed, torque and gimbal saturation with nonlinear recovery dynamics.
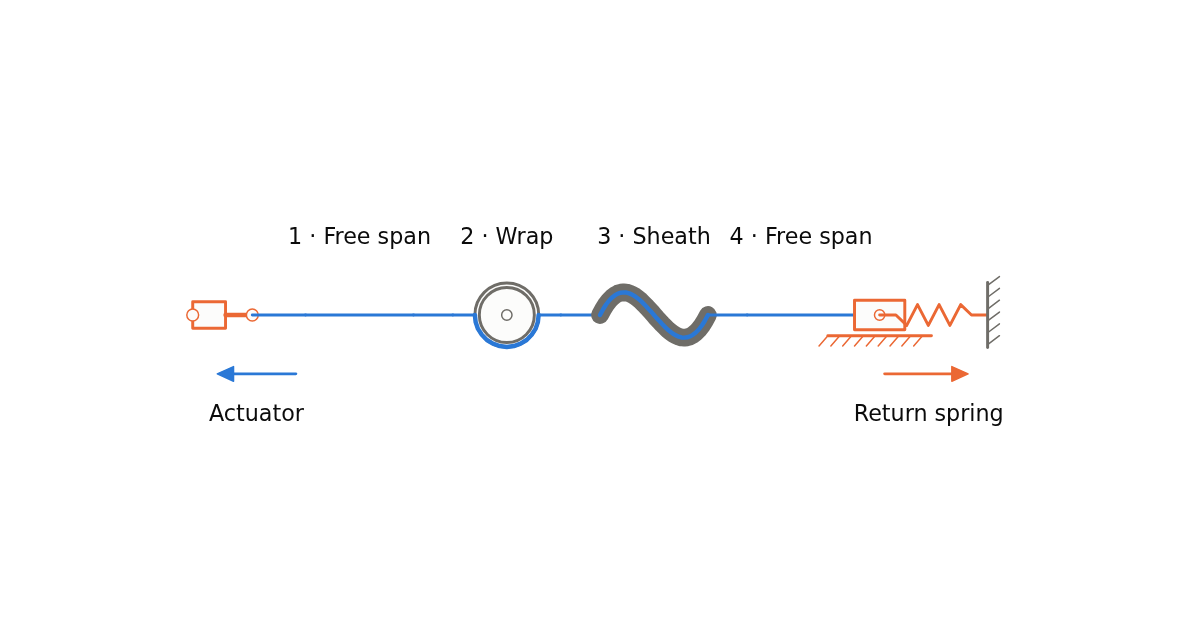
Calculate tension loss and cable stretch through ordered guides and Bowden sheaths. Resolve frictional hysteresis, reversal lost motion, and directional output stiffness.
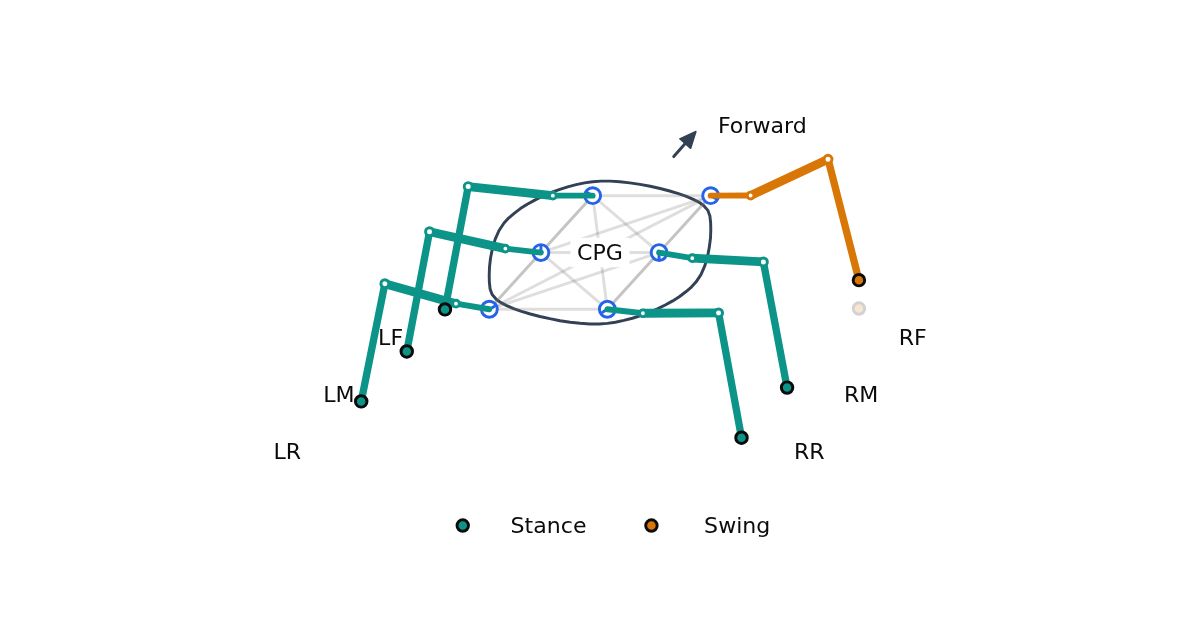
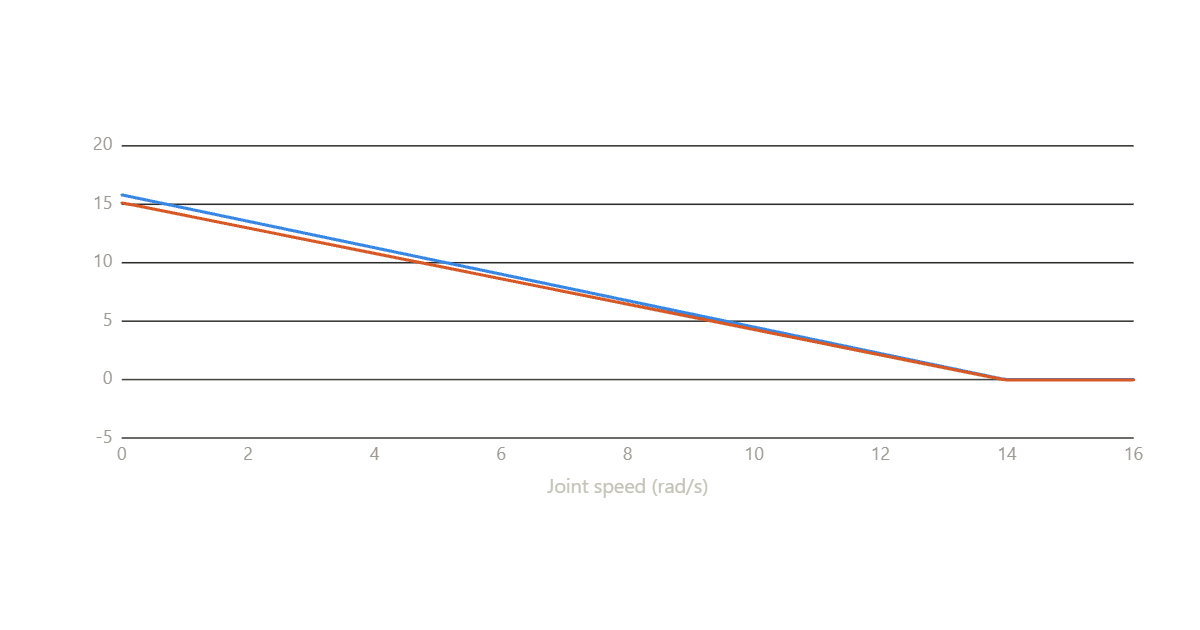
Simulate six coupled Hopf oscillators, blend tripod–ripple–wave gaits, and animate reachable three-joint leg commands. Inspect phase tracking, footfall timing and joint speed.
Size a two- or multi-finger robot grasp against sliding and twisting. Include arm acceleration, an offset centre of mass and coupled soft-finger friction.
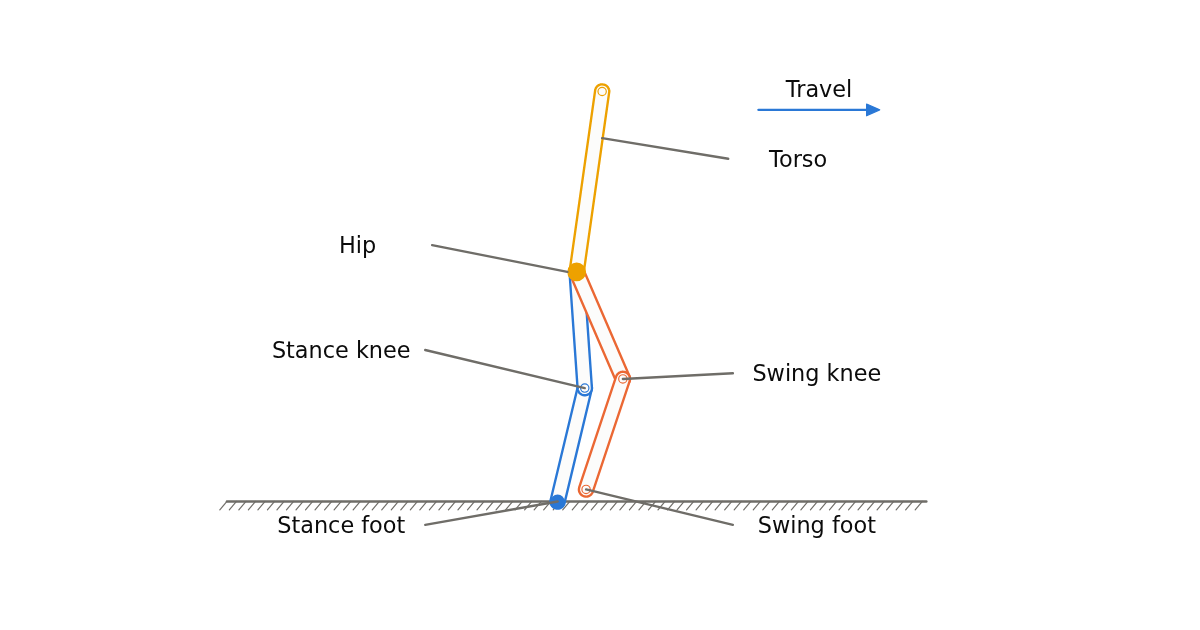
Find periodic walking gaits, Poincaré multipliers and disturbance margins for a passive compass gait or a full five-link HZD walker. Animate each hybrid step.
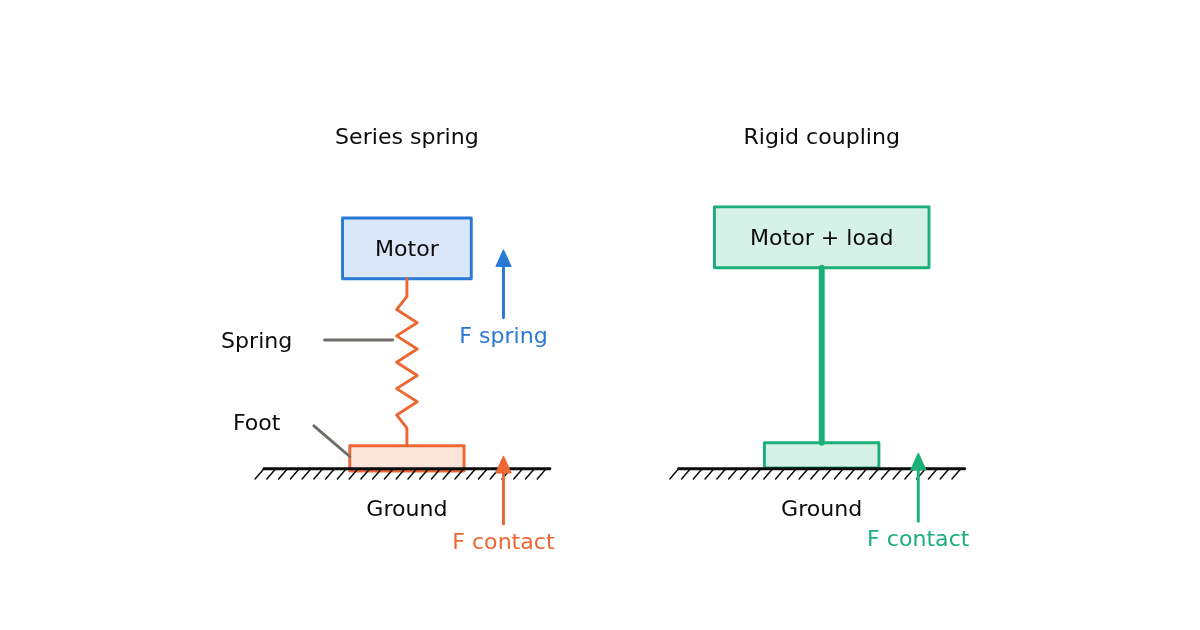
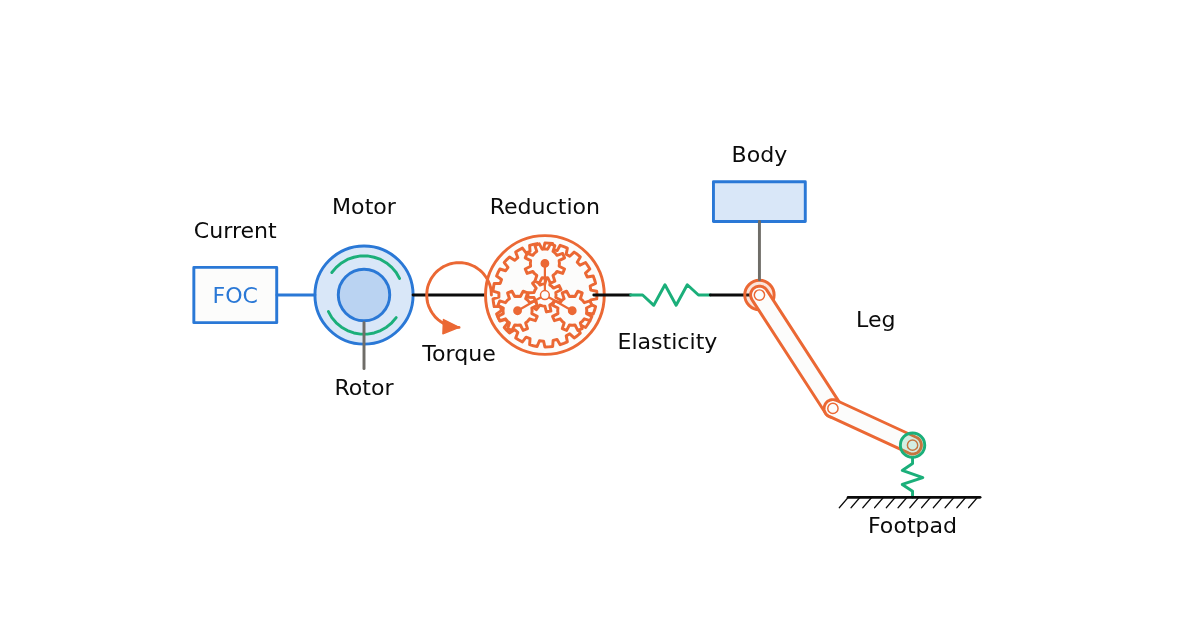
Size an SEA spring for robot-leg impacts and force control. Compare nonlinear impact forces, spring travel, motor-limited bandwidth and output impedance across stiffness.
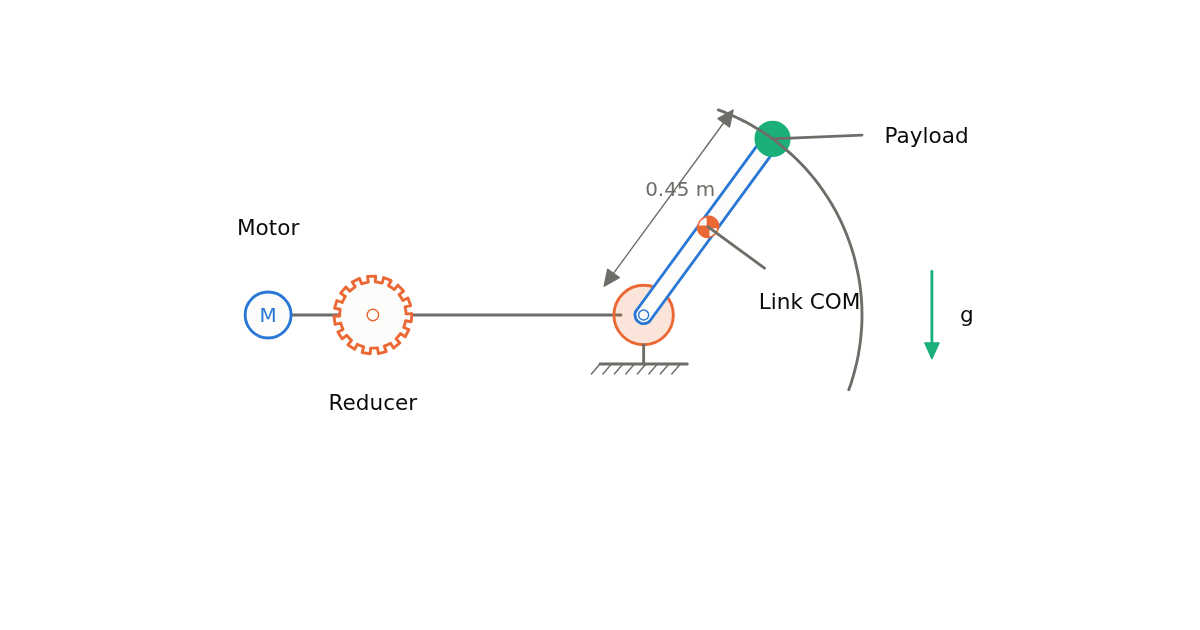
Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
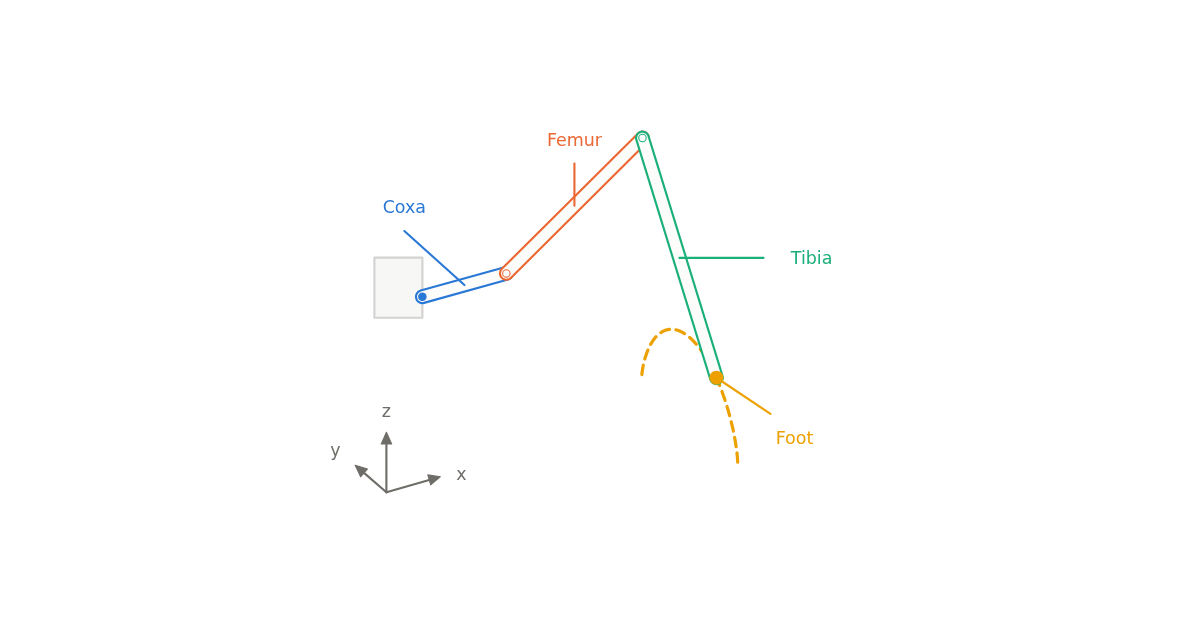
Calculate 3-DOF coxa–femur–tibia joint angles and speeds for a cycloidal swing. Animate the leg and explore joint-limited workspace and velocity manipulability.
Can a humanoid stop after a push? Calculate capture point and DCM motion, finite-foot N-step capture regions, touchdown deadlines and recovery foot placements.
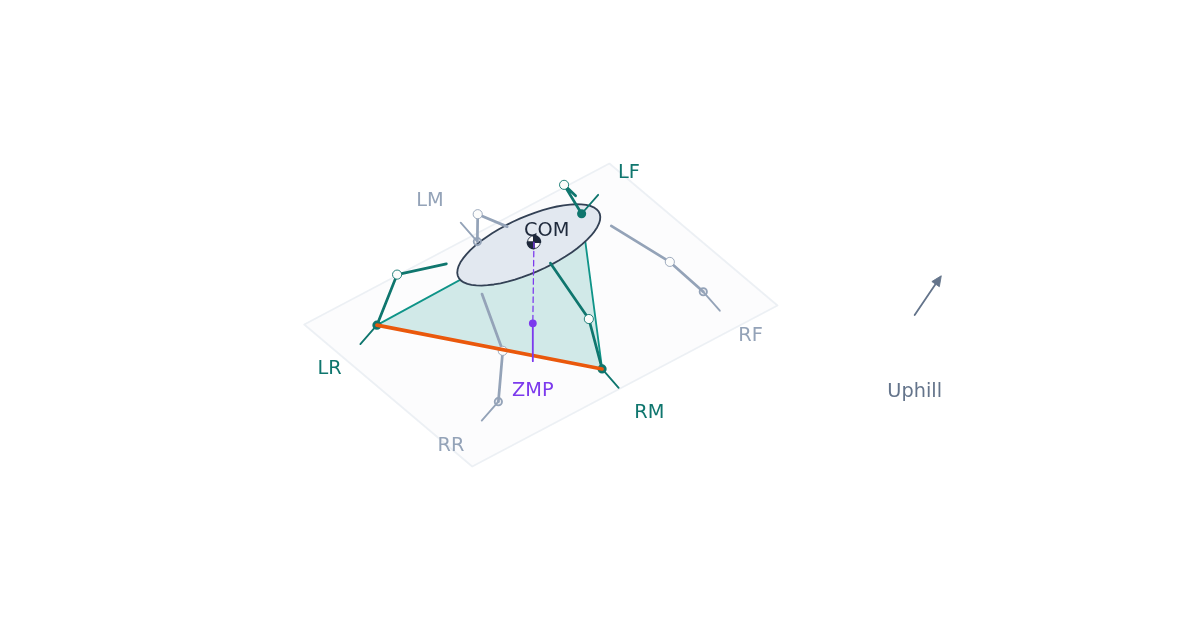
Compare tripod, ripple and wave gaits on slopes and uneven footholds. Evaluate static margin, tipping energy, force-angle reserve and body-acceleration ZMP through a complete cycle.
Size a quasi direct drive robot joint: compare gear ratios, reflected inertia, torque bandwidth and voltage limits, then simulate winding and housing heating during running and jumping.
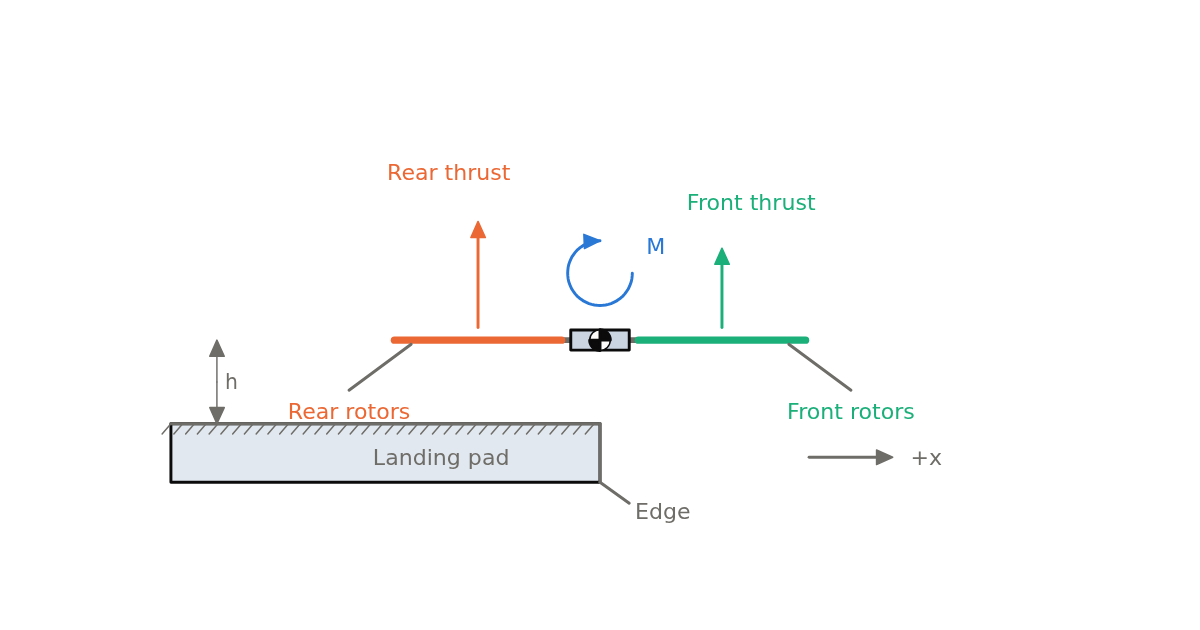
Estimate quadcopter hover thrust gain, power saving and pitch moment near a landing-pad edge using Cheeseman–Bennett, Hayden and multirotor image-source models.
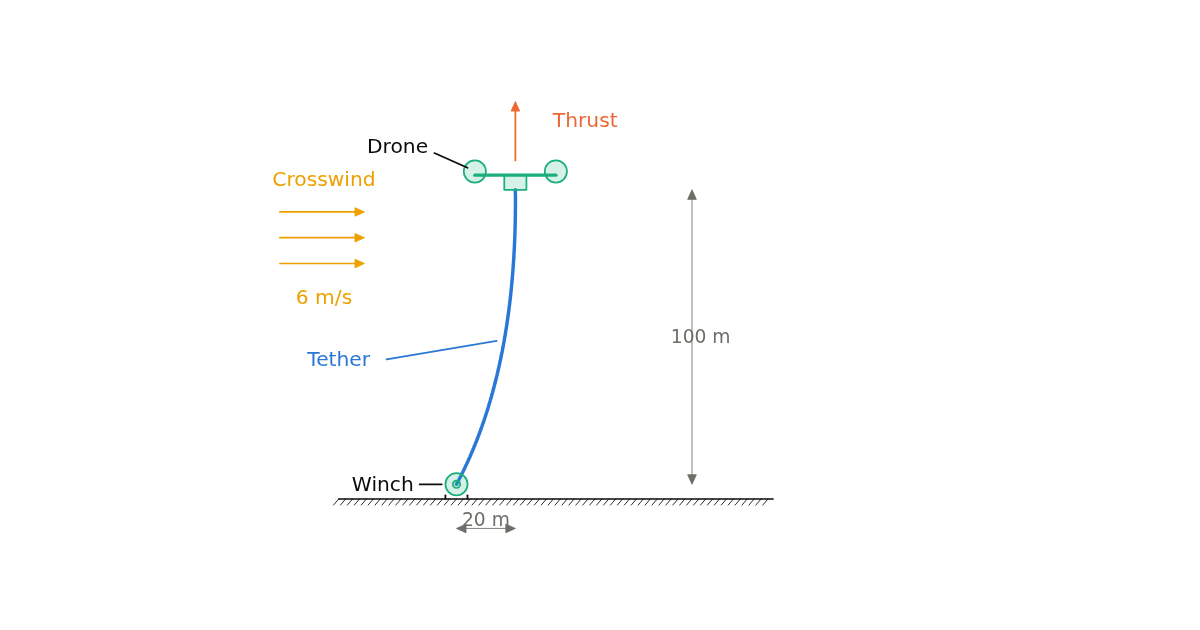
Size a tethered drone’s DC conductors and voltage. Solve elastic cable shape in crosswind, endpoint tension, extra thrust and the altitude limit along a specified payout route.
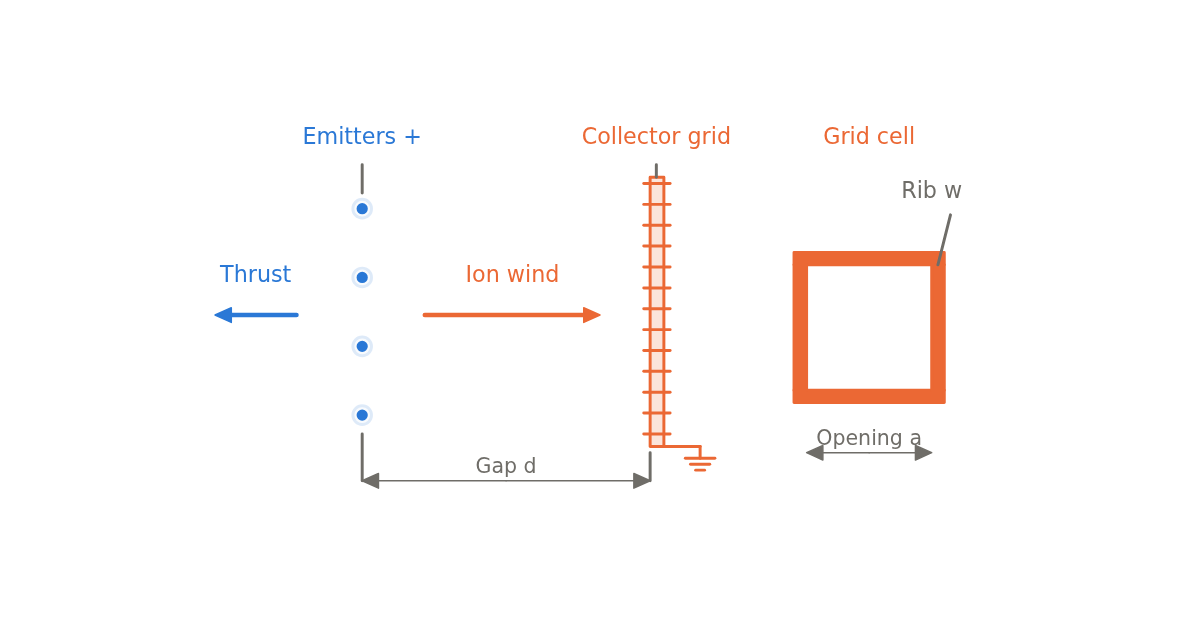
Estimate ion-wind thrust, thrust density and thrust per watt from corona onset and Townsend current. Size emitter arrays, collector grids and repeated stages.
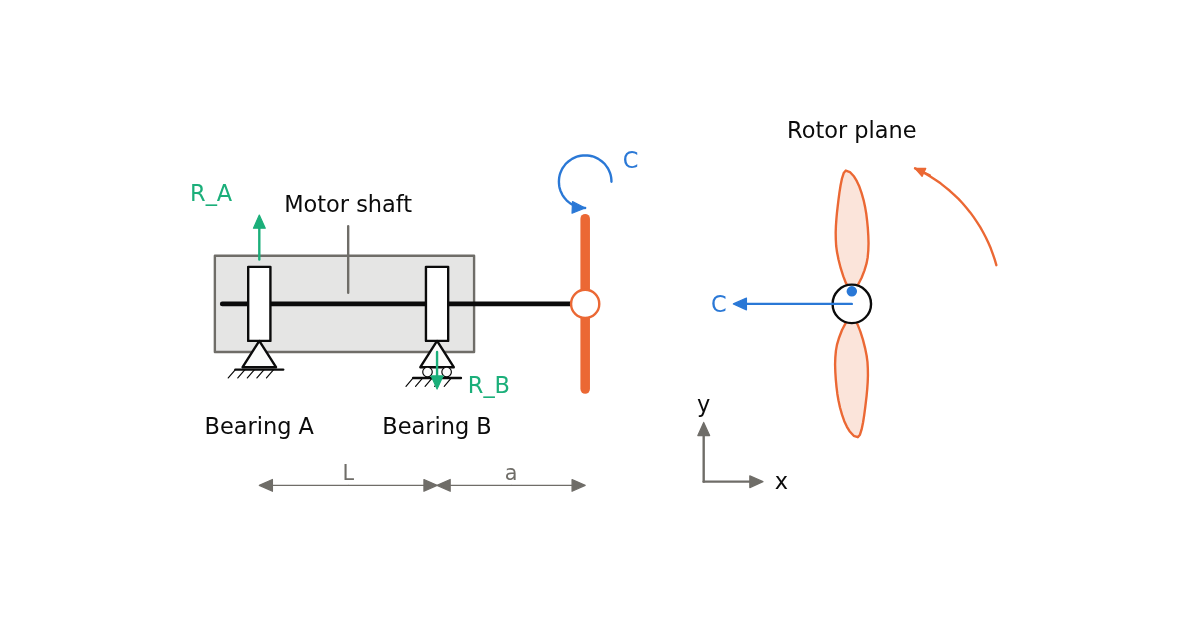
Calculate drone propeller gyroscopic moments, two-blade oscillation, motor shaft bending and bearing reactions, with a Goodman fatigue check.
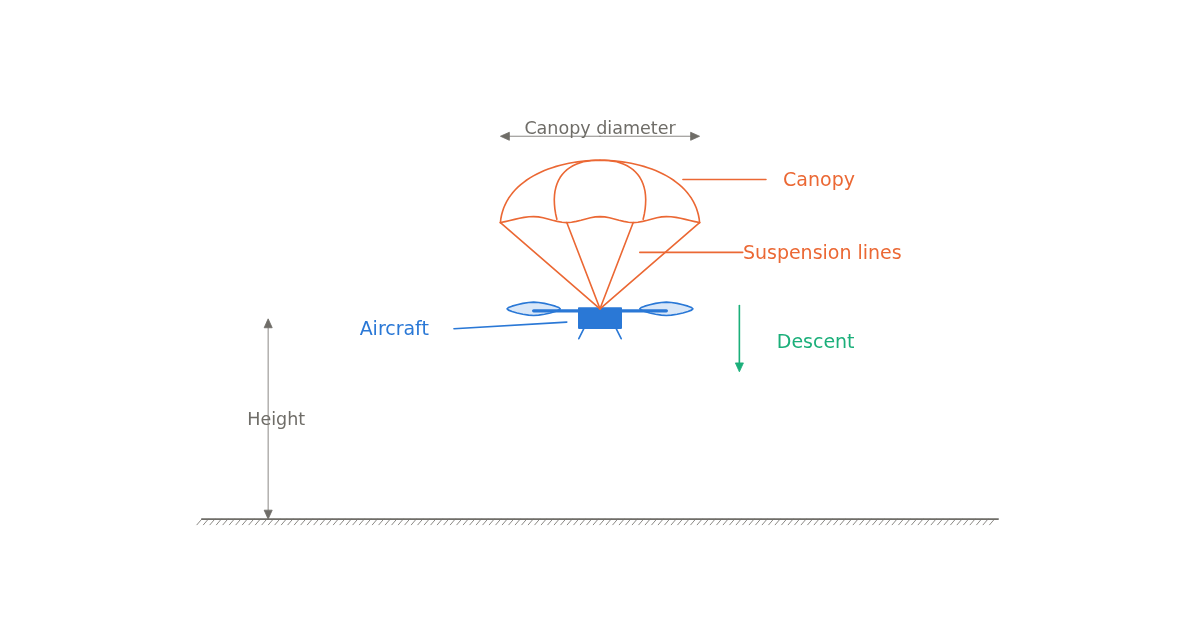
Modellieren Sie den Notabstieg einer Drohne am Rettungsschirm aus dem Schwebe- oder Reiseflug, einschließlich Entfaltungshöhe, Öffnungslast, Aufprallenergie, Rotorzuständen und Gleitflug eines Hybridfluggeräts.
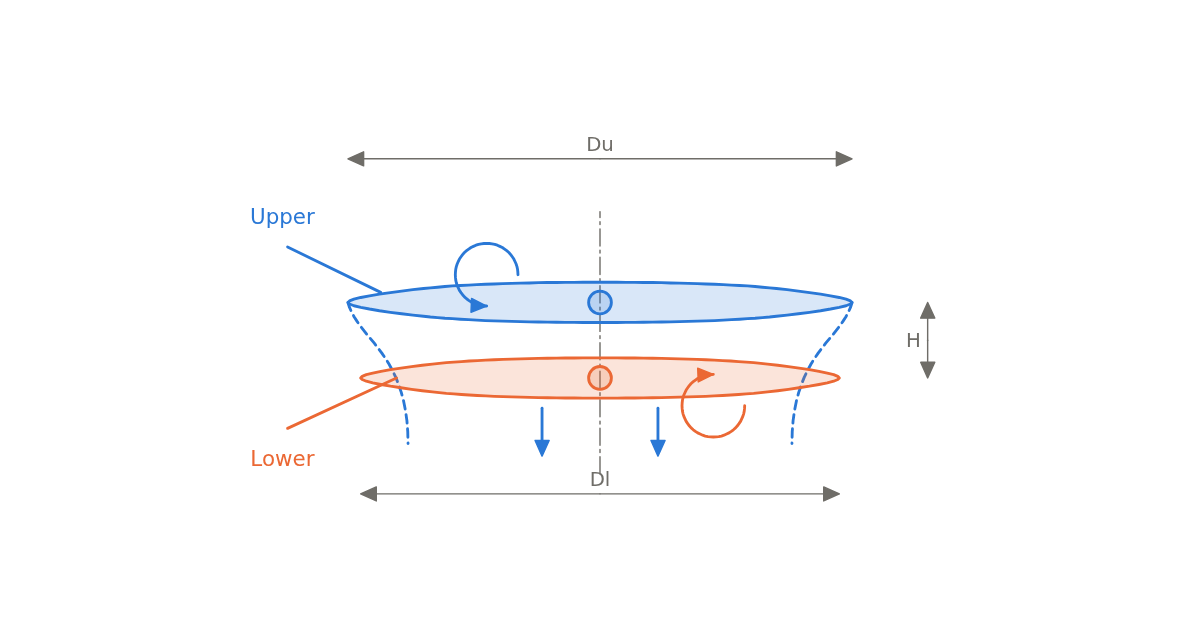
Compare rotor spacing, diameter ratio and pitch offset using coupled blade-element momentum theory. Find a torque-balanced hover design and its figure of merit.
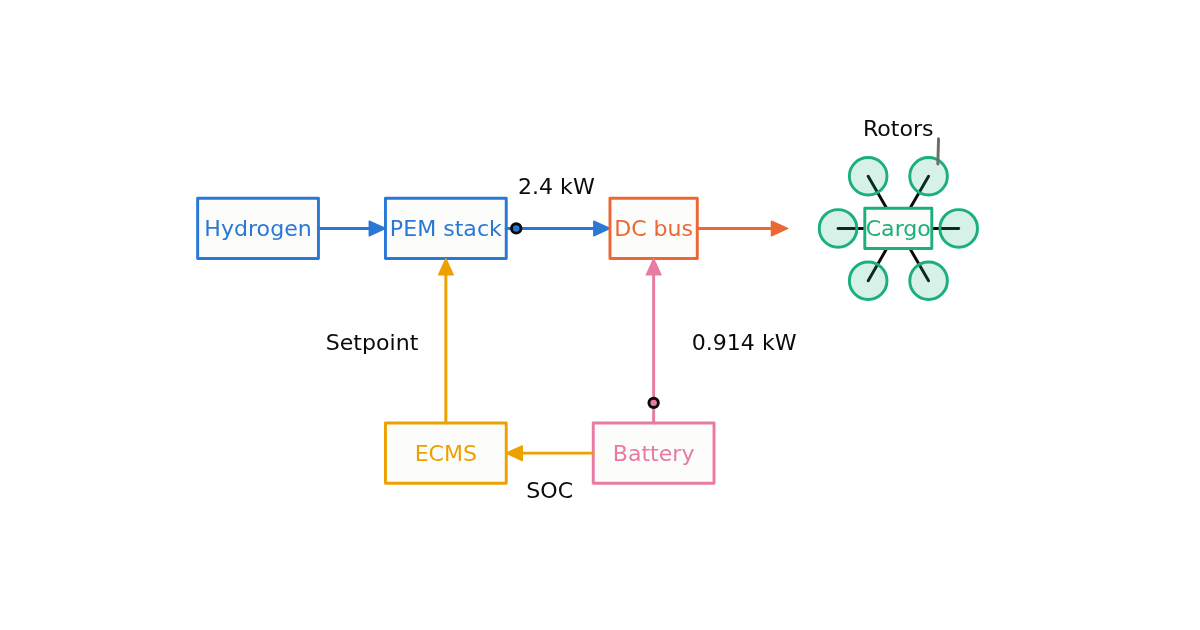
Simulieren Sie eine Lastendrohnenmission mit SOC-abhängiger ECMS, PEM-Polarisation und dynamischem Batteriemodell. Vergleichen Sie Wasserstoffverbrauch und Unterstützung im Steigflug mit einer regelbasierten Leistungsaufteilung.
Screen joint torque margin and battery voltage sag for hexapod and octopod gait loads.
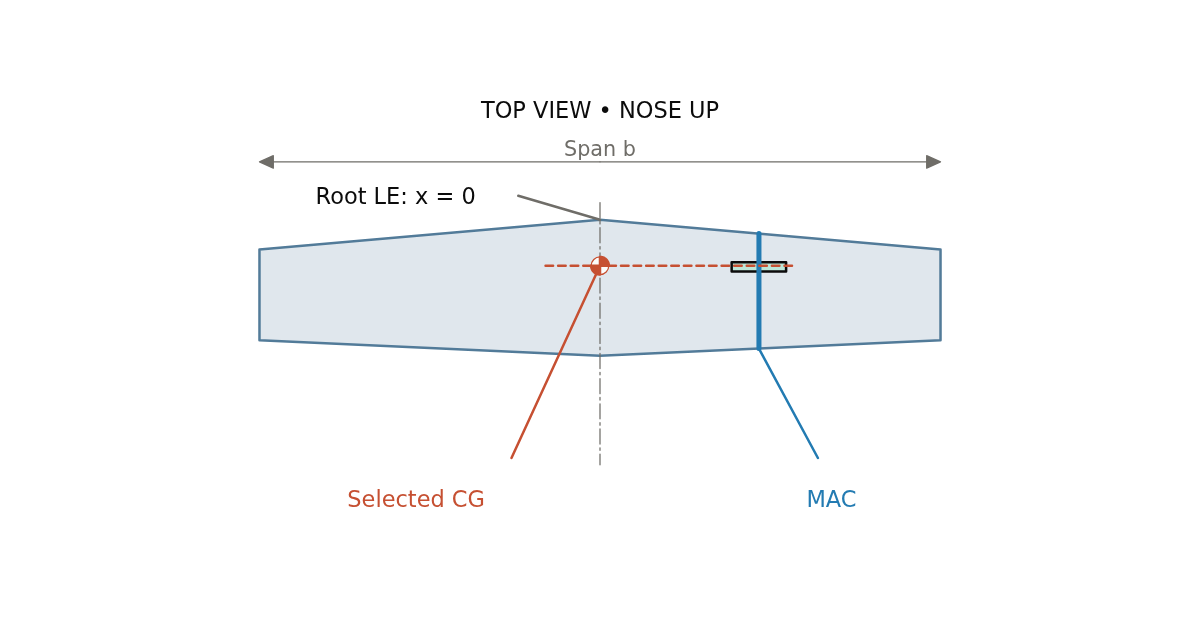
Calculate RC wing area, loading, stall speed, MAC and CG. Compare tail volume and electric power targets, with a planform drawing and a separate flying-wing CG rule.
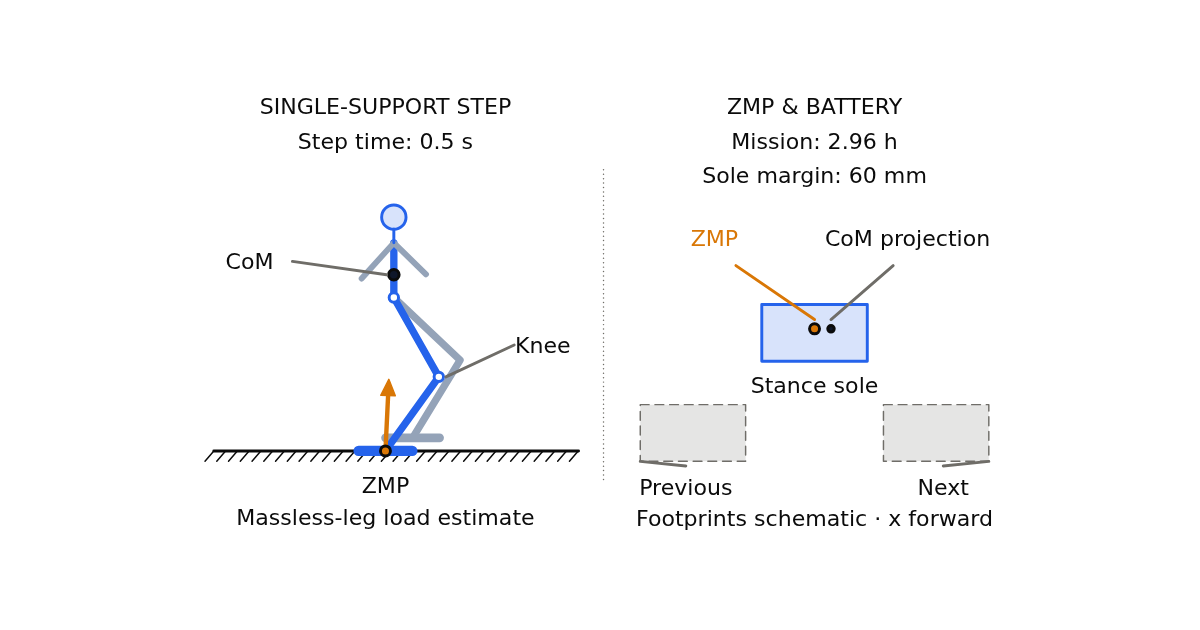
Estimate humanoid robot battery life, ZMP balance margins and hip/knee stance torque. Animate a walking step and compare battery, gait and duty-cycle assumptions.
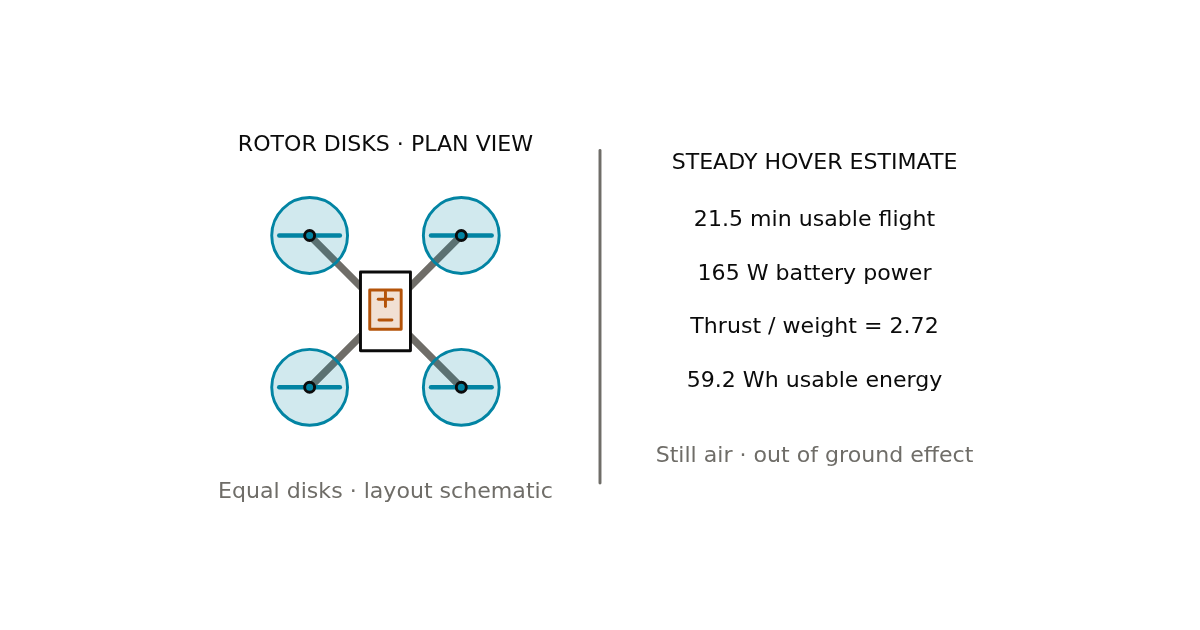
Estimate multicopter hover time from battery energy and rotor physics. Check thrust-to-weight ratio and payload limits for a chosen endurance target.
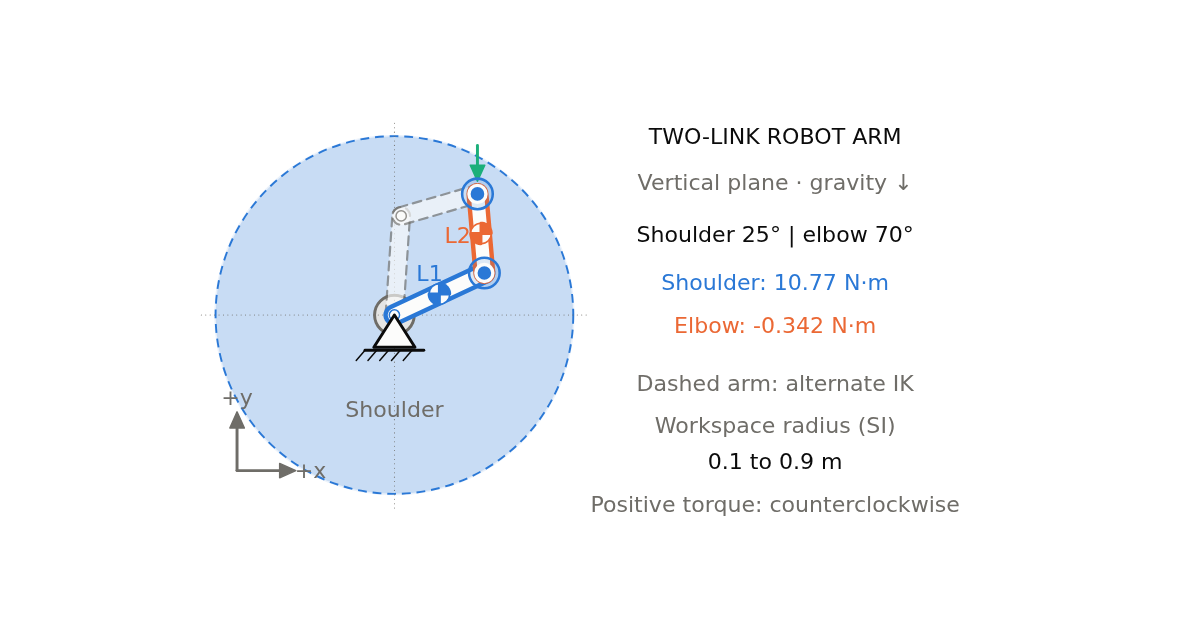
Berechnen Sie die Vorwärts- und inverse Kinematik eines ebenen zweigliedrigen Roboterarms, vergleichen Sie die Stellungen „Ellenbogen unten/oben“ und bestimmen Sie die statischen Gelenkmomente aus den Massen der Glieder und der Nutzlast.