Hexapod Leg Inverse Kinematics: 3-DOF Cycloidal Step and Workspace
 Wired White v2
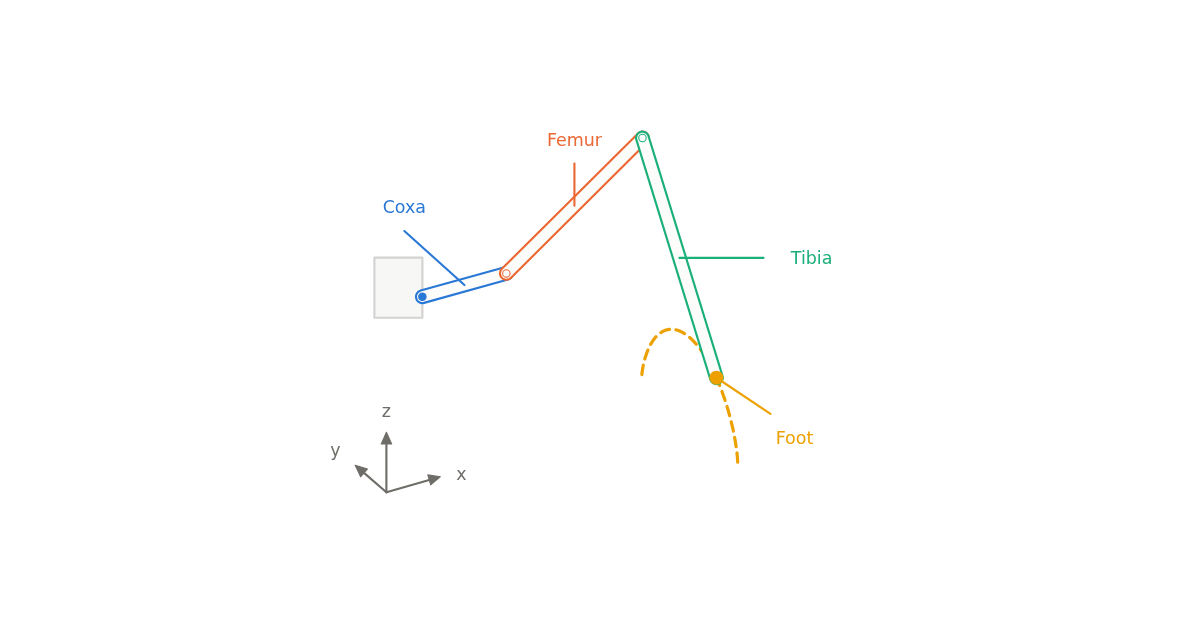
Calculate 3-DOF coxa–femur–tibia joint angles and speeds for a cycloidal swing. Animate the leg and explore joint-limited workspace and velocity manipulability.
Wired White v2 Calculate 3-DOF coxa–femur–tibia joint angles and speeds for a cycloidal swing. Animate the leg and explore joint-limited workspace and velocity manipulability.
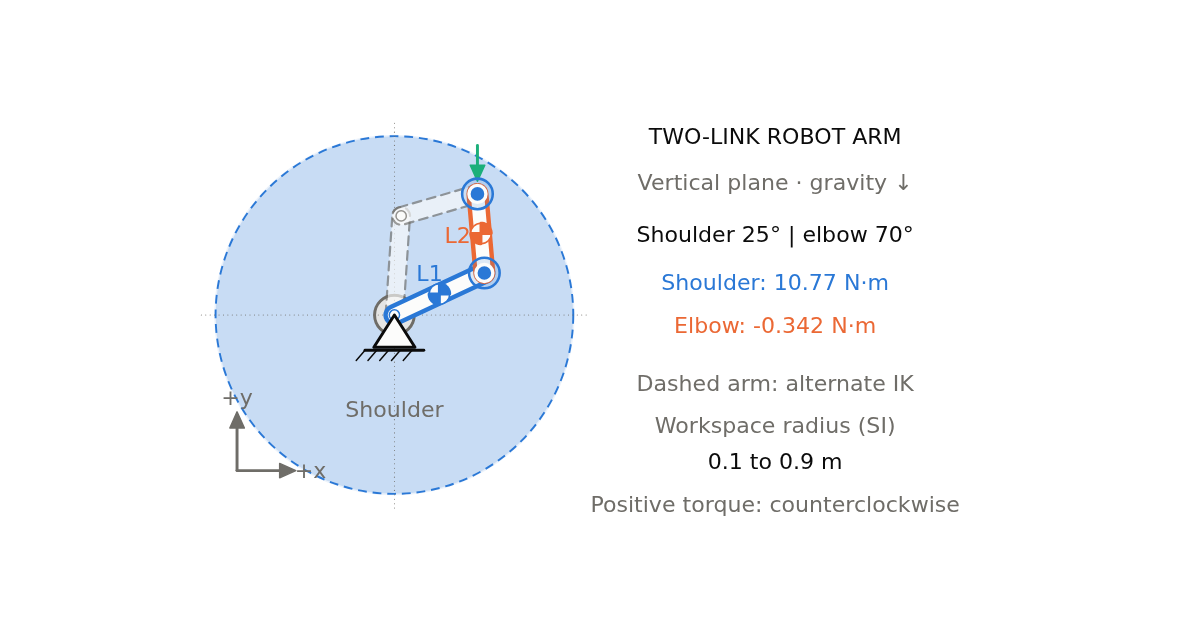
Wired White v3 Berechnen Sie die Vorwärts- und inverse Kinematik eines ebenen zweigliedrigen Roboterarms, vergleichen Sie die Stellungen „Ellenbogen unten/oben“ und bestimmen Sie die statischen Gelenkmomente aus den Massen der Glieder und der Nutzlast.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.