

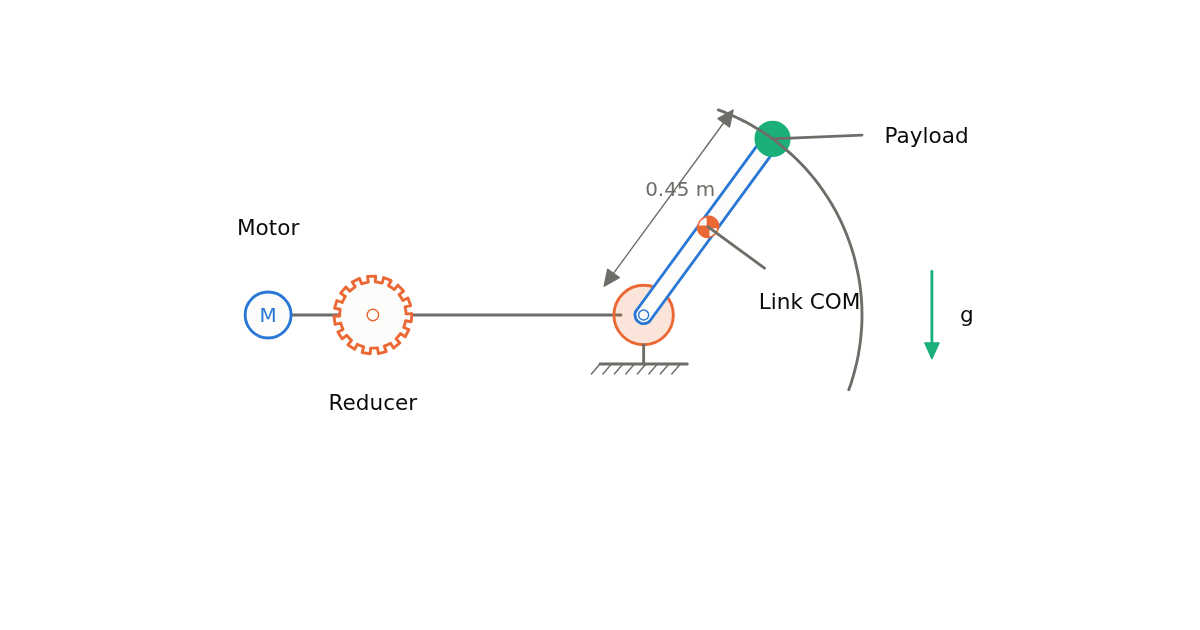
Robot Joint RMS Torque & S1 Motor Thermal Check
 Wired White v2
Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
Wired White v2 Size a robot joint motor from a time–angle table or smooth trajectory. Check RMS and peak torque, the speed–torque curve, and winding temperature over repeated cycles.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.