Hexapod CPG Gait Generator: Tripod, Ripple and Wave
 Wired White v1
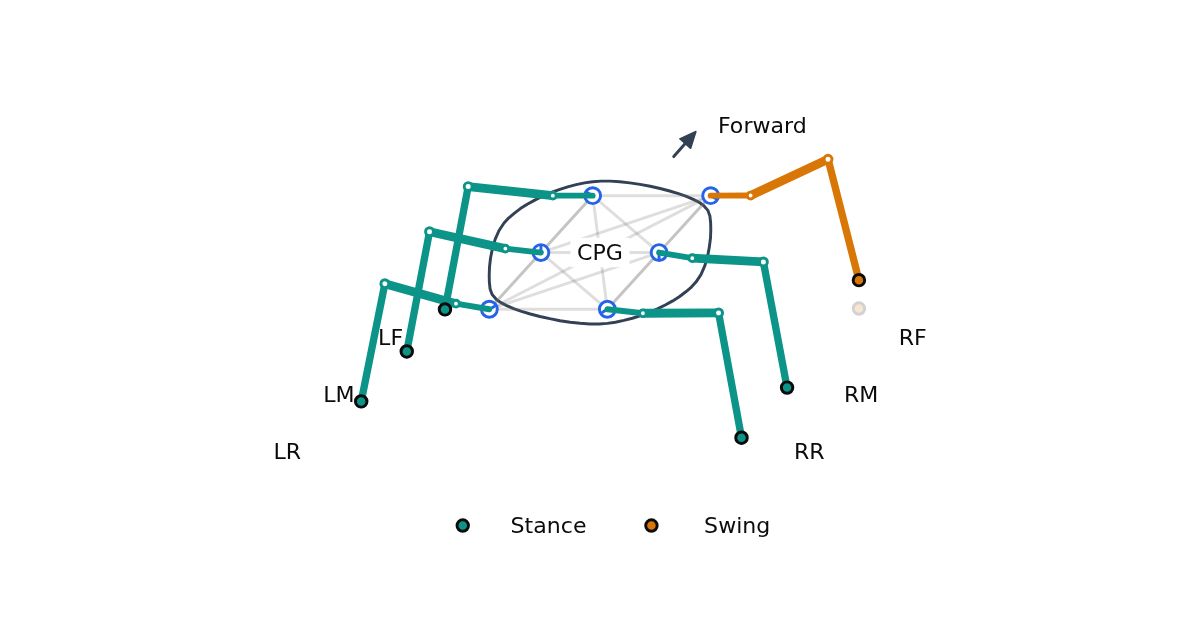
Simulate six coupled Hopf oscillators, blend tripod–ripple–wave gaits, and animate reachable three-joint leg commands. Inspect phase tracking, footfall timing and joint speed.
Wired White v1 Simulate six coupled Hopf oscillators, blend tripod–ripple–wave gaits, and animate reachable three-joint leg commands. Inspect phase tracking, footfall timing and joint speed.
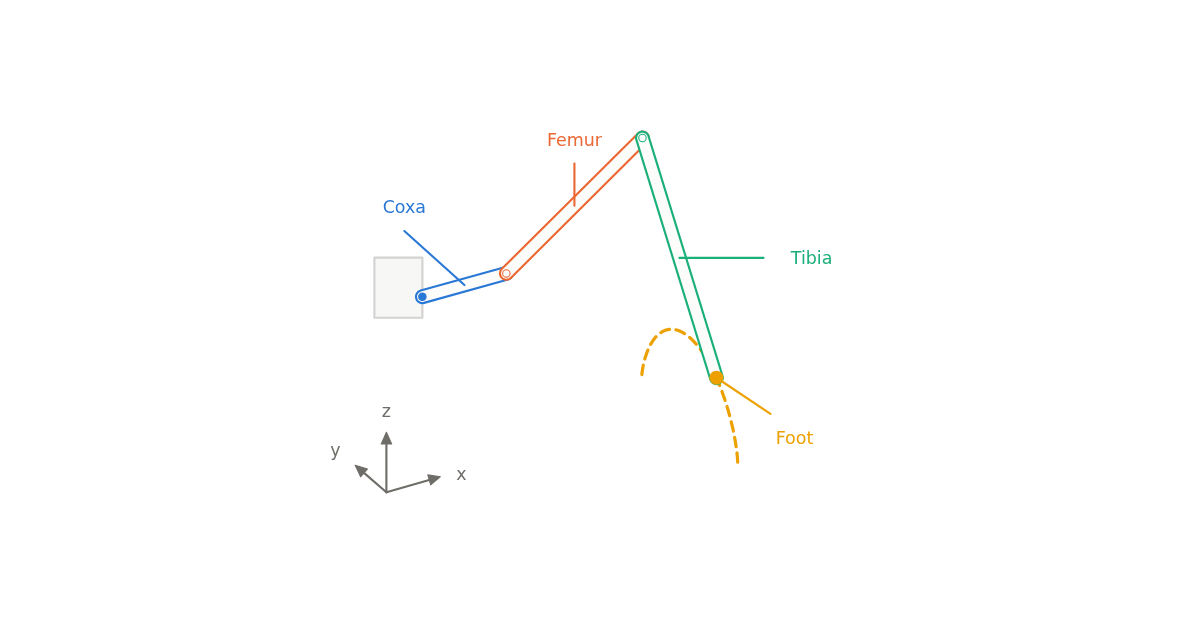
Wired White v2 Calculate 3-DOF coxa–femur–tibia joint angles and speeds for a cycloidal swing. Animate the leg and explore joint-limited workspace and velocity manipulability.
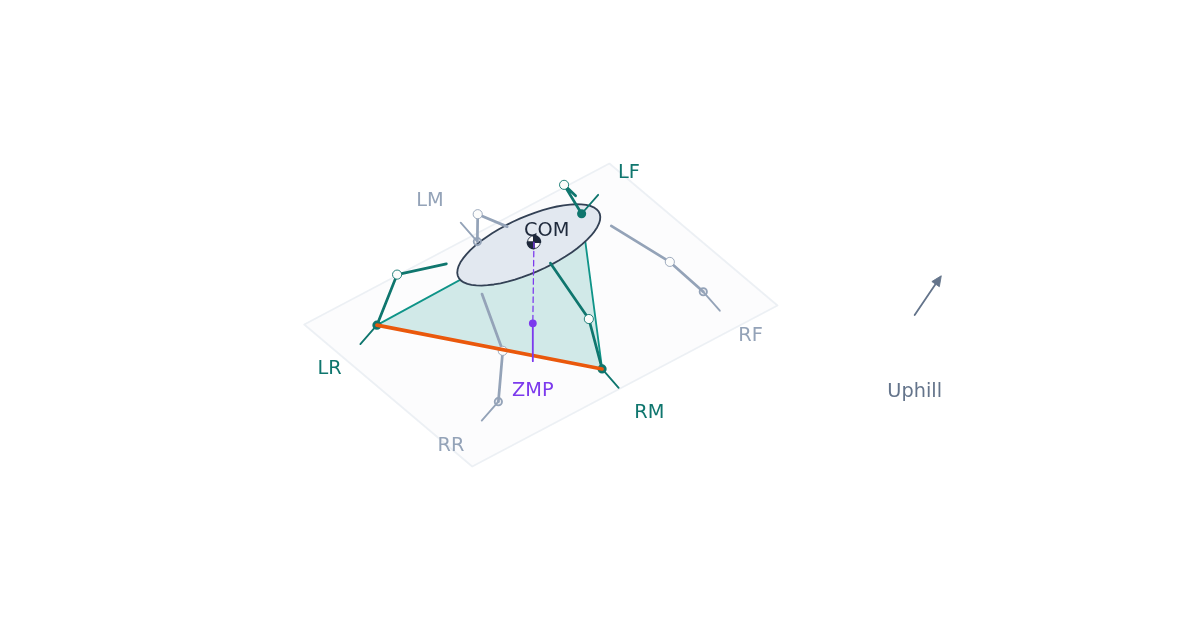
Wired White v2 Compare tripod, ripple and wave gaits on slopes and uneven footholds. Evaluate static margin, tipping energy, force-angle reserve and body-acceleration ZMP through a complete cycle.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.