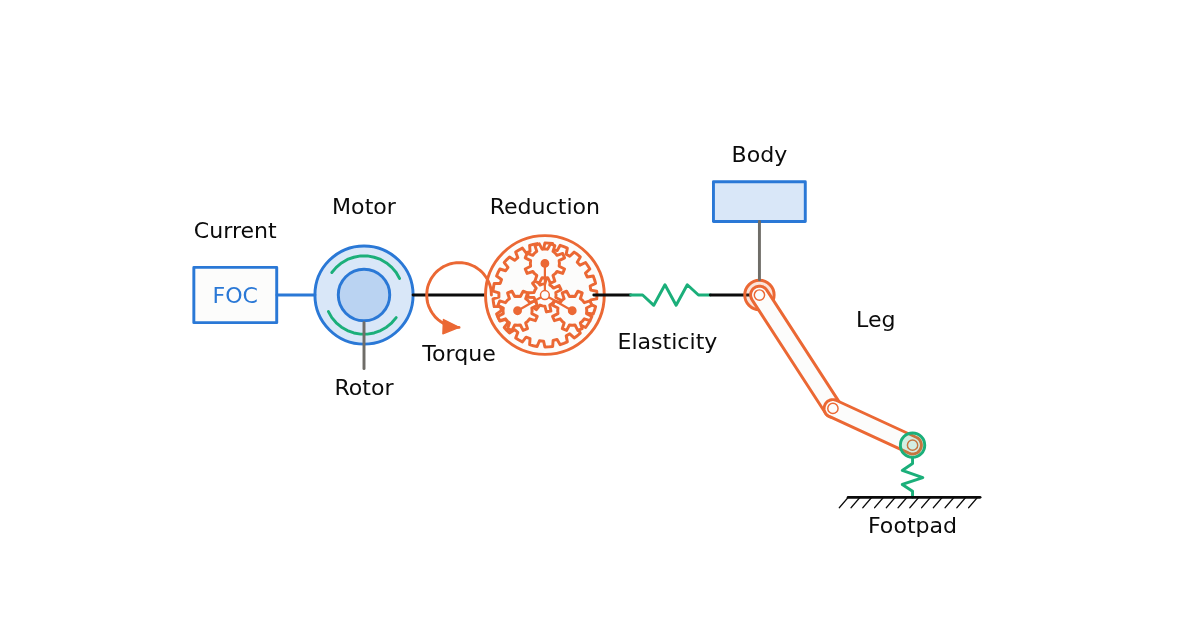
QDD Actuator: Gear Ratio, Inertia, Bandwidth and Heating

Size a quasi direct drive robot joint: compare gear ratios, reflected inertia, torque bandwidth and voltage limits, then simulate winding and housing heating during running and jumping.
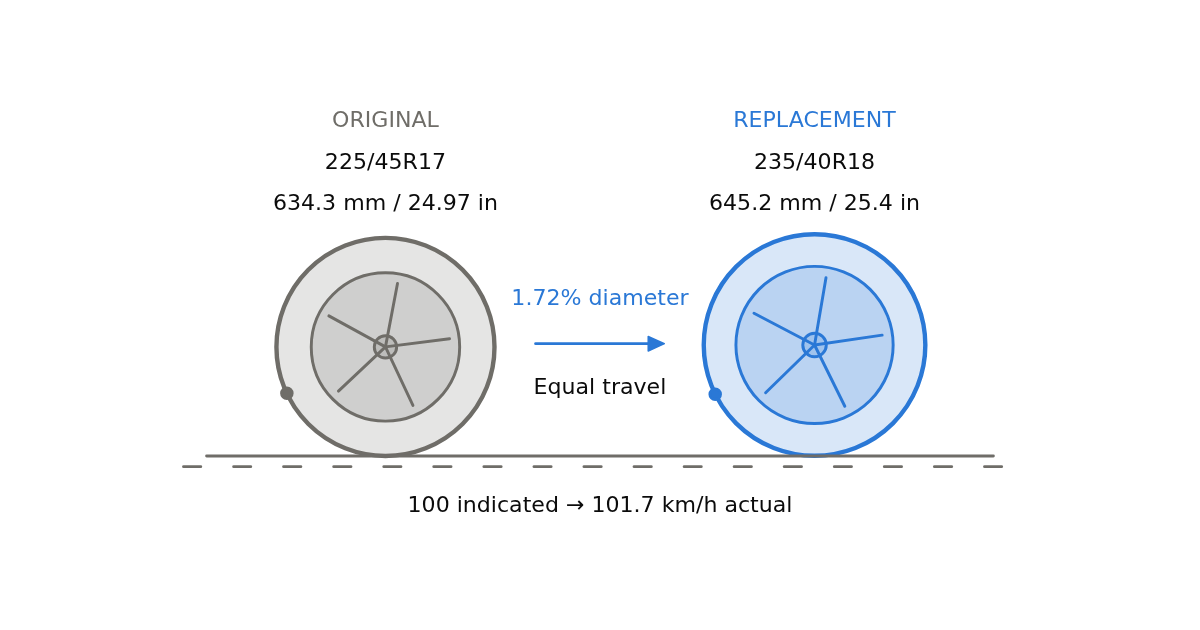
Compare tire sizes, speedometer error and engine RPM in every gear. Find regear targets and see how wheel offset changes a measured clearance envelope.
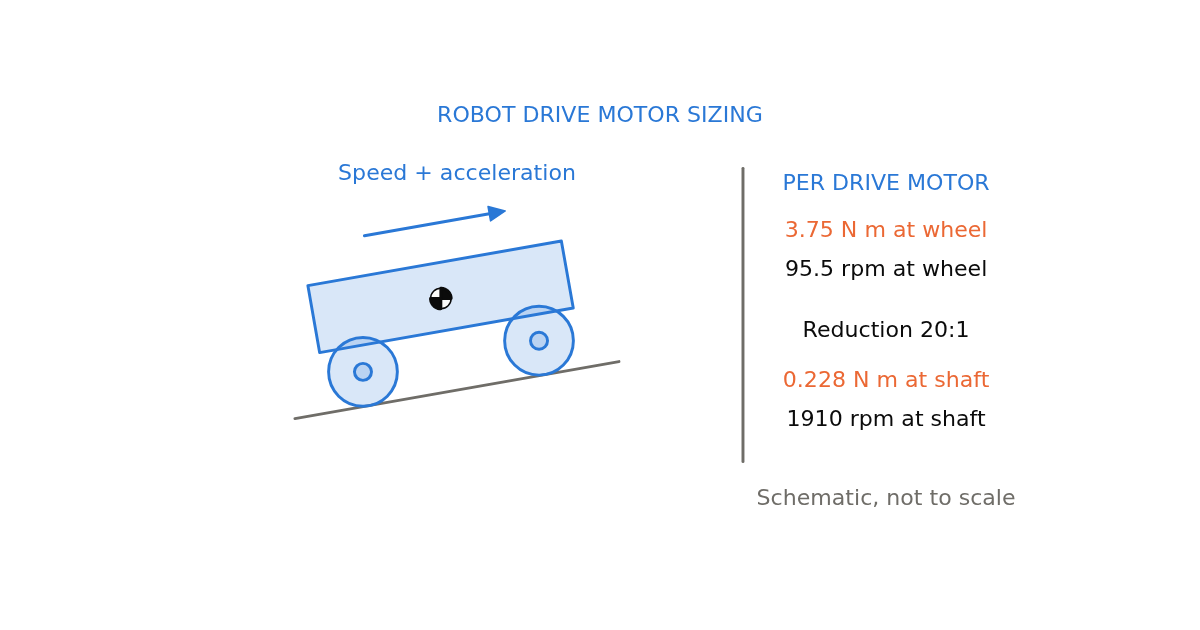
Size wheel and motor torque, speed, reduction ratio and battery energy for an uphill wheeled robot. Check traction and compare a candidate motor at its loaded operating point.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.