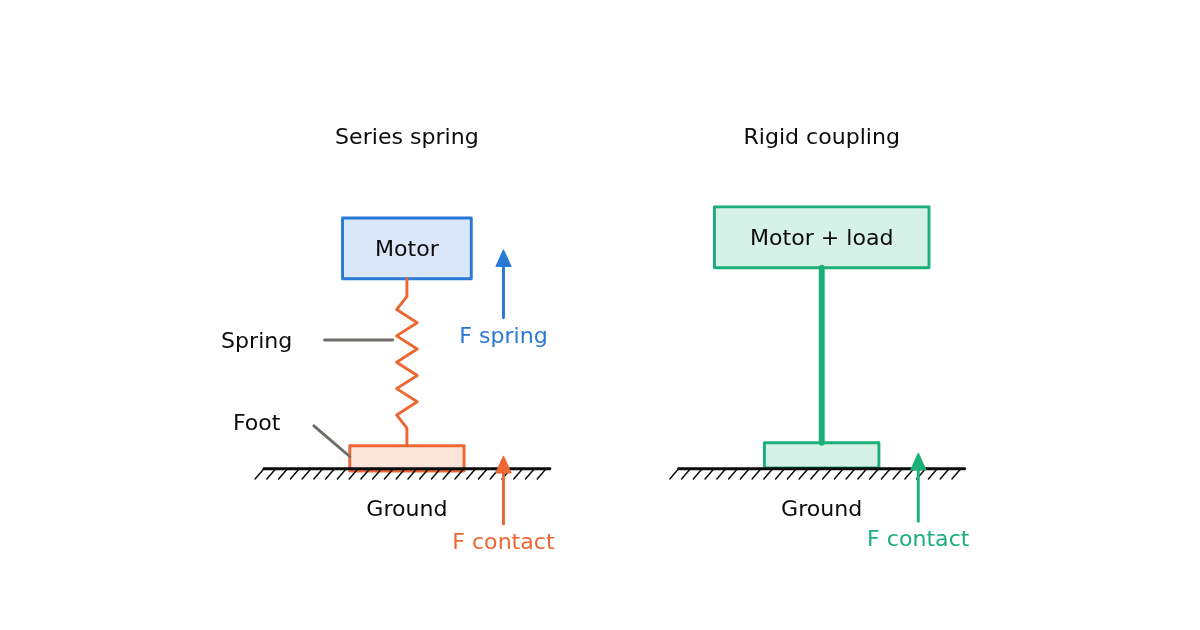
Series Elastic Actuator: Spring Stiffness, Impact and Bandwidth

Size an SEA spring for robot-leg impacts and force control. Compare nonlinear impact forces, spring travel, motor-limited bandwidth and output impedance across stiffness.
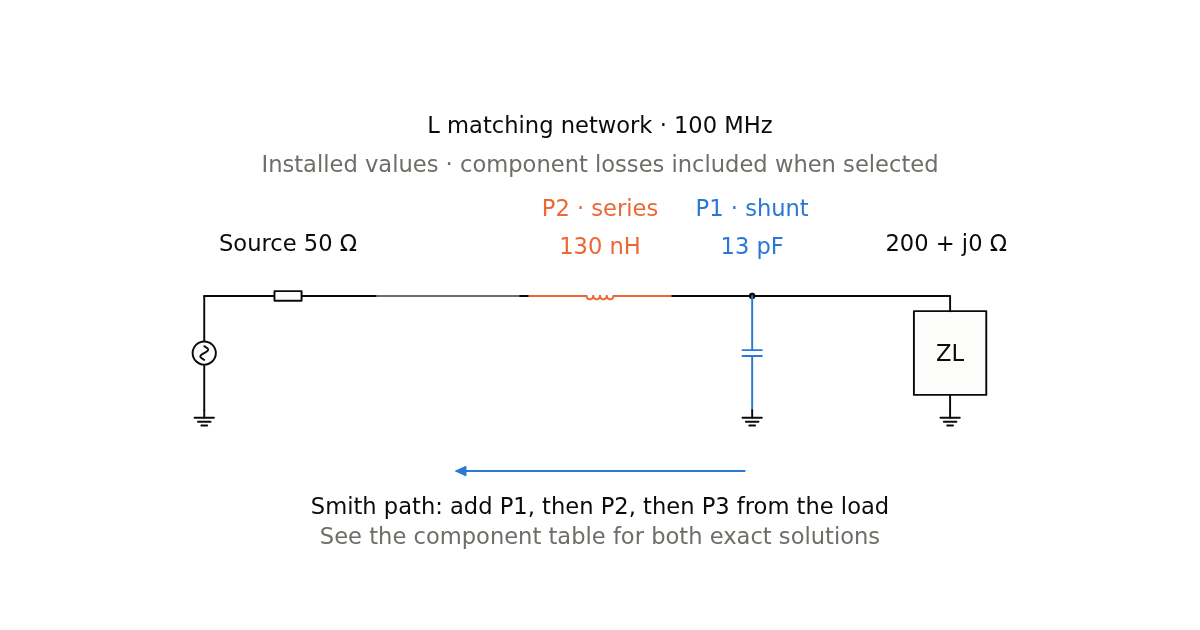
Design L, Pi and T networks for complex loads. Animate each element on a Smith chart, compare both L solutions, and check bandwidth, finite-Q losses and E-series rounding.
Please confirm you want to block this member.
You will no longer be able to:
Please allow a few minutes for this process to complete.